Parametric dense stereovision implementation on a system-on chip (SoC)
Related Experiment Video
Updated: May 23, 2026
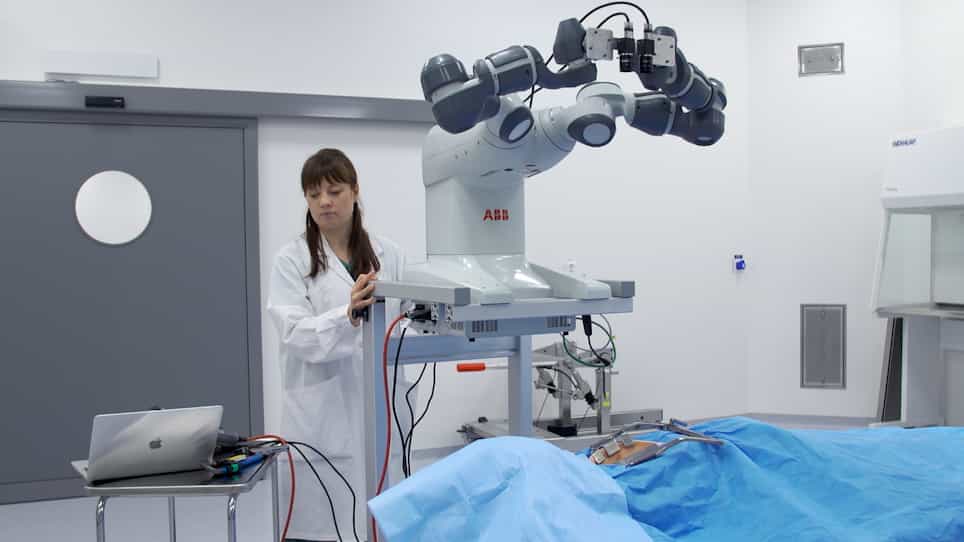
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Alfredo Gardel1, Pablo Montejo, Jorge García
1Electronics Department, University of Alcala, Alcalá de Henares, Madrid 28871, Spain. alfredo@depeca.uah.es

Abstract:
This paper proposes a novel hardware implementation of a dense recovery of stereovision 3D measurements. Traditionally 3D stereo systems have imposed the maximum number of stereo correspondences, introducing a large restriction on artificial vision algorithms. The proposed system-on-chip (SoC) provides great performance and efficiency, with a scalable architecture available for many different situations, addressing real time processing of stereo image flow. Using double buffering techniques properly combined with pipelined processing, the use of reconfigurable hardware achieves a parametrisable SoC which gives the designer the opportunity to decide its right dimension and features. The proposed architecture does not need any external memory because the processing is done as image flow arrives. Our SoC provides 3D data directly without the storage of whole stereo images. Our goal is to obtain high processing speed while maintaining the accuracy of 3D data using minimum resources. Configurable parameters may be controlled by later/parallel stages of the vision algorithm executed on an embedded processor. Considering hardware FPGA clock of 100 MHz, image flows up to 50 frames per second (fps) of dense stereo maps of more than 30,000 depth points could be obtained considering 2 Mpix images, with a minimum initial latency. The implementation of computer vision algorithms on reconfigurable hardware, explicitly low level processing, opens up the prospect of its use in autonomous systems, and they can act as a coprocessor to reconstruct 3D images with high density information in real time.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:10
Computed Tomography
The technique was invented in the 1970s and is based on the principle that as X-rays pass through the body, they are absorbed or reflected at different levels. In the technique, a patient lies on a motorized platform while a computerized axial tomography (CAT) scanner rotates...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Spherical Coordinates
 01:24
Vision
 01:28
Synthetic Disvision of Polynomials