Hip joint centre localisation with an unscented Kalman filter
Related Experiment Video
Updated: May 23, 2026
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Elena De Momi1, Elisa Beretta, Giancarlo Ferrigno
1a NearLab, Bioengineering Department , Politecnico di Milano , Milan , Italy.

Abstract:
The accurate estimation of the hip joint centre (HJC) in gait analysis and in computer assisted orthopaedic procedures is a basic requirement. Functional methods, based on rigid body localisation, assessing the kinematics of the femur during circumduction movements (pivoting) have been used for estimating the HJC. Localising the femoral segment only, as it is usually done in total knee replacement procedure, can give rise to estimation errors, since the pelvis, during the passive pivoting manoeuvre, might undergo spatial displacements. This paper presents the design and test of an unscented Kalman filter that allows the estimation of the HJC by observing the pose of the femur and the 3D coordinates of a single marker attached to the pelvis. This new approach was validated using a hip joint mechanical simulator, mimicking both hard and soft tissues. The algorithm performances were compared with the literature standards and proved to have better performances in case of pelvis translation greater than 8 mm, thus satisfying the clinical requirements of the application.
More Related Videos

Related Concept Videos
 01:09
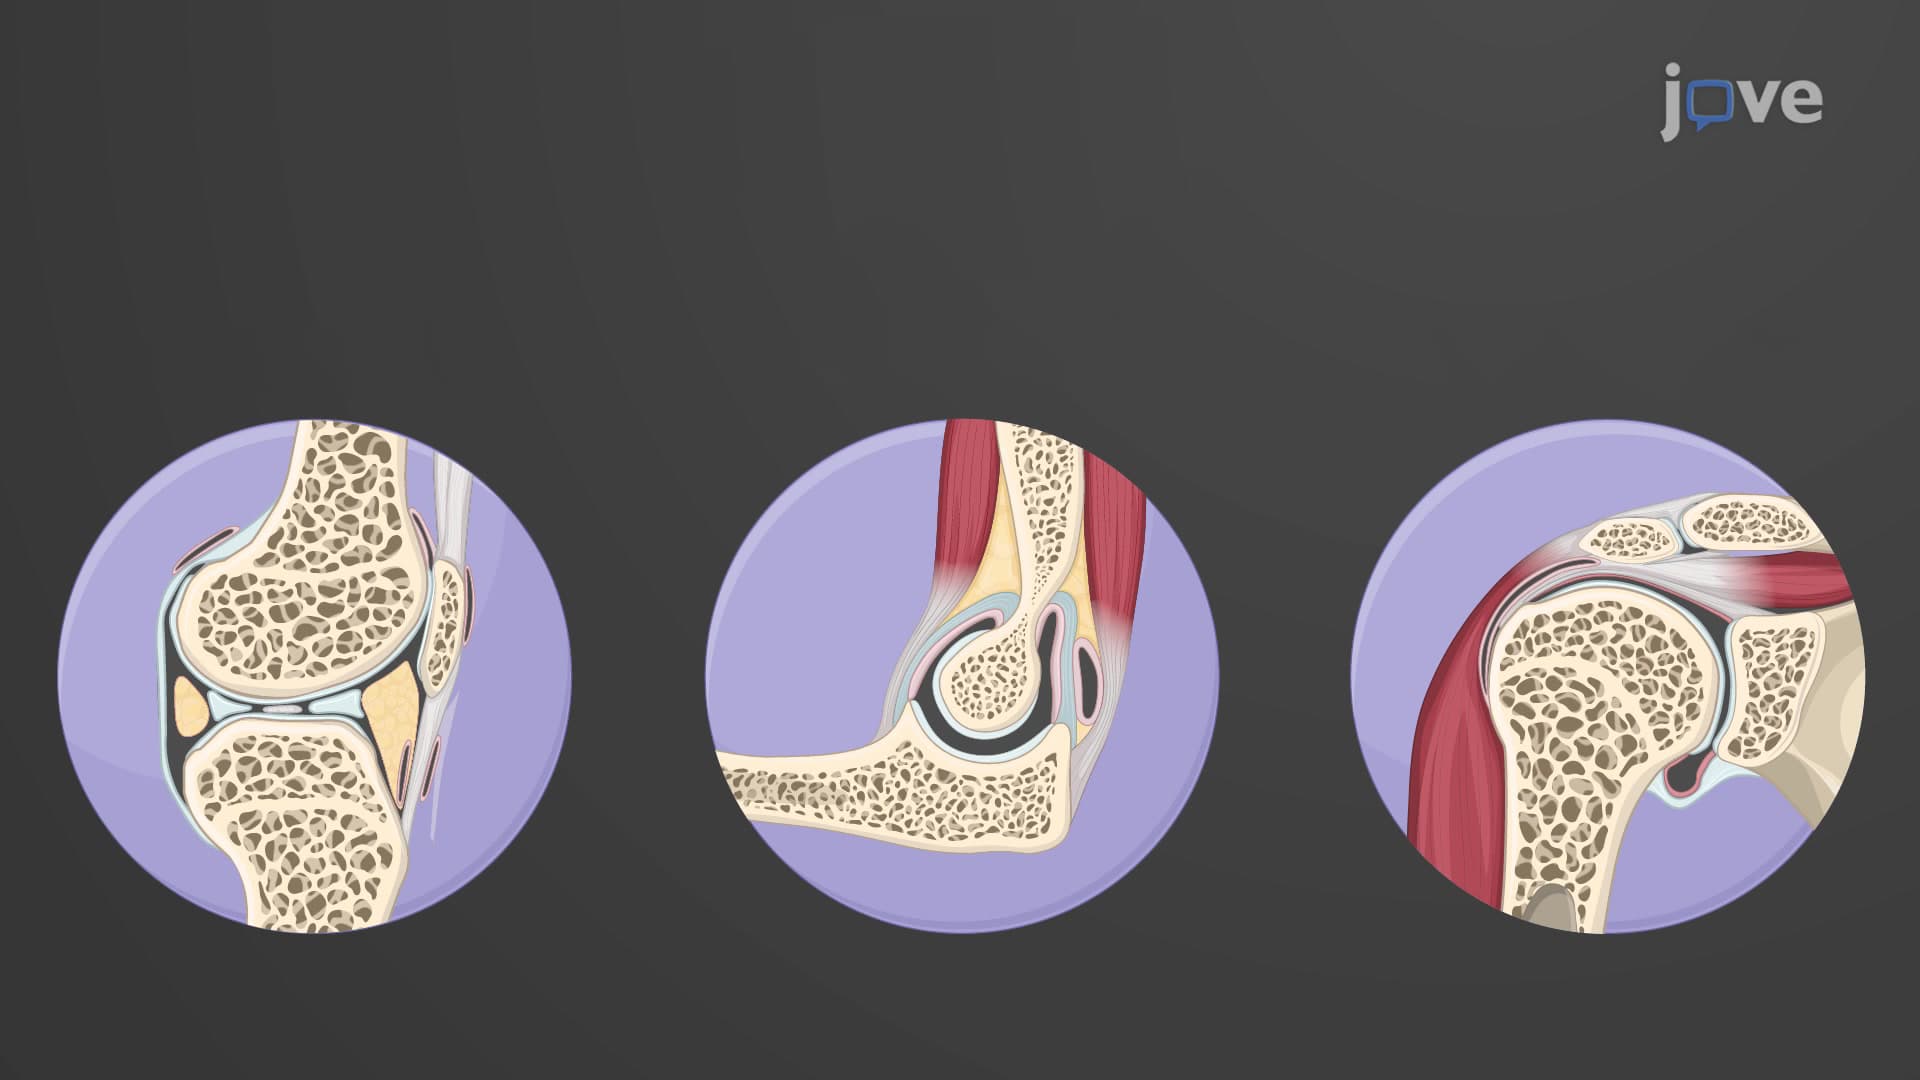
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An immobile...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris group...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...