Non-orthogonal tool/flange and robot/world calibration
Related Experiment Video
Updated: May 23, 2026
Automatic Laser-based Geometry Capture for Finite Element Analysis of Weld Beads
Published on: July 25, 2025
Floris Ernst1, Lars Richter, Lars Matthäus
1Institute for Robotics and Cognitive Systems, University of Lübeck, Ratzeburger Allee 160, 23538, Lübeck, Germany. ernst@rob.uni-luebeck.de

Background:
For many robot-assisted medical applications, it is necessary to accurately compute the relation between the robot's coordinate system and the coordinate system of a localisation or tracking device. Today, this is typically carried out using hand-eye calibration methods like those proposed by Tsai/Lenz or Daniilidis.
Methods:
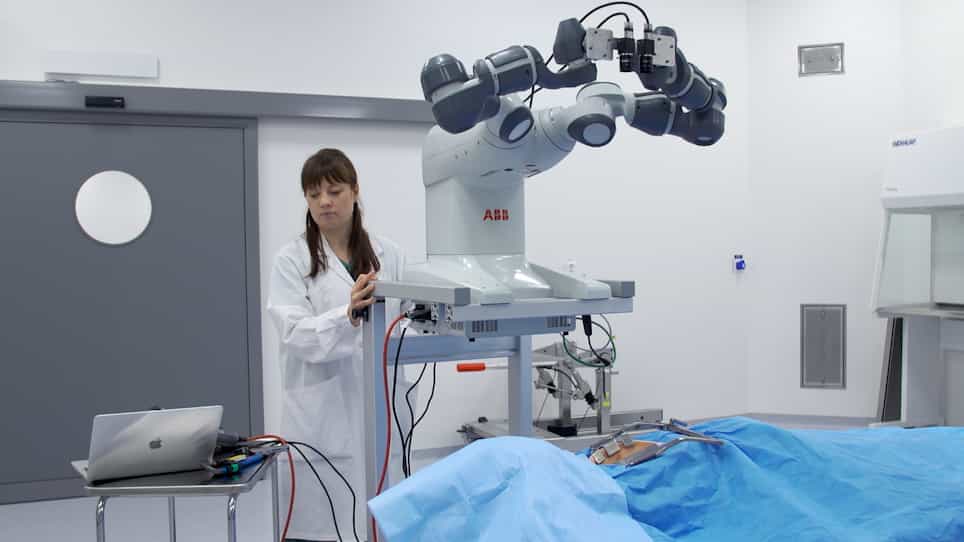
We present a new method for simultaneous tool/flange and robot/world calibration by estimating a solution to the matrix equation AX = YB. It is computed using a least-squares approach. Because real robots and localisation are all afflicted by errors, our approach allows for non-orthogonal matrices, partially compensating for imperfect calibration of the robot or localisation device. We also introduce a new method where full robot/world and partial tool/flange calibration is possible by using localisation devices providing less than six degrees of freedom (DOFs). The methods are evaluated on simulation data and on real-world measurements from optical and magnetical tracking devices, volumetric ultrasound providing 3-DOF data, and a surface laser scanning device. We compare our methods with two classical approaches: the method by Tsai/Lenz and the method by Daniilidis.
Results:
In all experiments, the new algorithms outperform the classical methods in terms of translational accuracy by up to 80% and perform similarly in terms of rotational accuracy. Additionally, the methods are shown to be stable: the number of calibration stations used has far less influence on calibration quality than for the classical methods.
Conclusion:
Our work shows that the new method can be used for estimating the relationship between the robot's and the localisation device's coordinate systems. The new method can also be used for deficient systems providing only 3-DOF data, and it can be employed in real-time scenarios because of its speed.

Related Concept Videos
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Torque Free Motion
 01:10
Calibration Curves: Correlation Coefficient
 01:15
Distance Corrections