Related Experiment Video
Updated: May 23, 2026
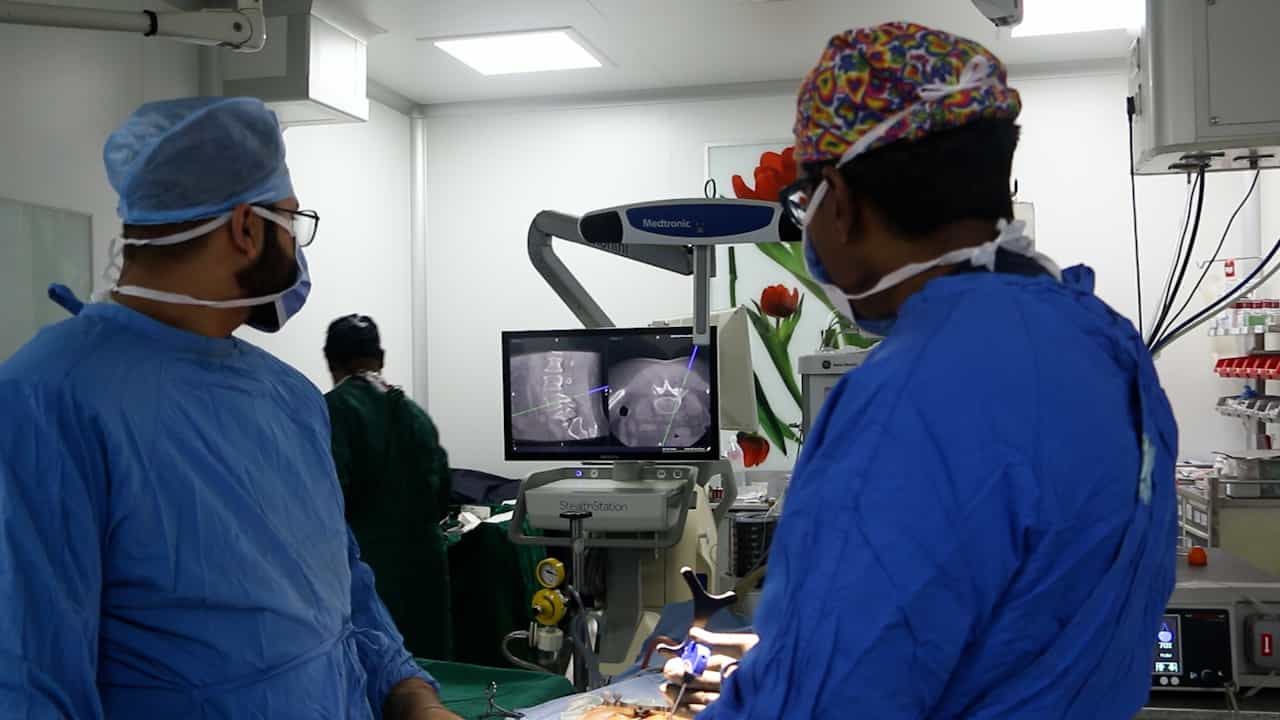

Optimizing Minimally Invasive Spine Surgery: A Fully 3D CT O-Arm Navigated Workflow in MIS TLIF
Published on: October 17, 2025
3D navigation and monitoring for spinal milling operation based on registration between multiplanar fluoroscopy and
Sheng Luan1, Tianmiao Wang, Weishi Li
1School of Computer Science and Engineering, Beihang University, China.

Abstract:
Milling operations in spinal surgery demand much experience and skill for the surgeon to perform the procedure safely. A 3D navigation method is introduced aiming at providing a monitoring system with enhanced safety and minimal intraoperative interaction. An automatic registration method is presented to establish the 3D-3D transformation between the preoperative CT images and a common reference system in the surgical space, and an intensity-based similarity metric adapted for the multi-planar configuration is introduced in the registration procedure. A critical region is defined for real-time monitoring in order to prevent penetration of the lamina and avoid violation of nerve structures. The contour of the spinal canal is reconstructed as the critical region, and different levels of warning limits are defined. During the milling procedure, the position of the surgical instrument relative to the critical region is provided with augmented display and audio warnings. Timely alarm is provided for surgeons to prevent surgical failure when the mill approaches the critical region. Our validation experiment shows that real-time 3D navigation and monitoring is advantageous for improving the safety of the milling operation.