Related Experiment Video
Updated: May 23, 2026
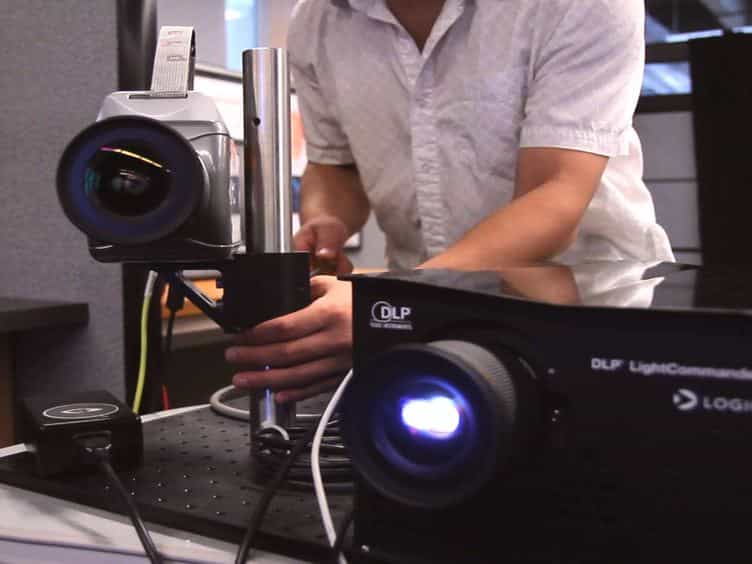

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
3-d motion estimation, understanding, and prediction from noisy image sequences
1Coordinated Science Laboratory, University of Illinois, Urbana, IL 61801.

Abstract:
This paper presents an approach to understanding general 3-D motion of a rigid body from image sequences. Based on dynamics, a locally constant angular momentum (LCAM) model is introduced. The model is local in the sense that it is applied to a limited number of image frames at a time. Specifically, the model constrains the motion, over a local frame subsequence, to be a superposition of precession and translation. Thus, the instantaneous rotation axis of the object is allowed to change through the subsequence. The trajectory of the rotation center is approximated by a vector polynomial. The parameters of the model evolve in time so that they can adapt to long term changes in motion characteristics. The nature and parameters of short term motion can be estimated continuously with the goal of understanding motion through the image sequence. The estimation algorithm presented in this paper is linear, i.e., the algorithm consists of solving simultaneous linear equations. Based on the assumption that the motion is smooth, object positions and motion in the near future can be predicted, and short missing subsequences can be recovered. Noise smoothing is achieved by overdetermination and a leastsquares criterion. The framework is flexible in the sense that it allows both overdetermination in number of feature points and the number of image frames.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...