Related Experiment Video
Updated: May 22, 2026
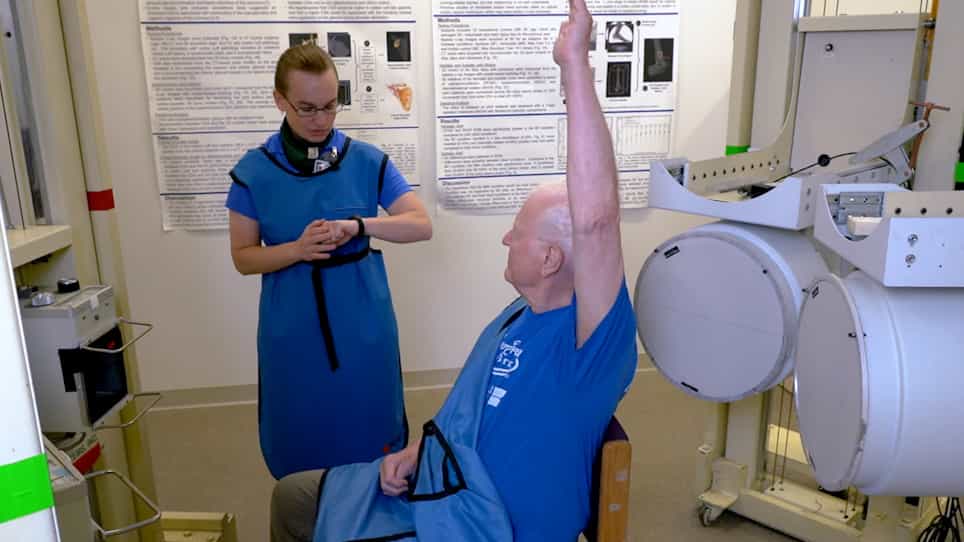

Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Three-dimensional in vivo motion analysis of normal knees employing transepicondylar axis as an evaluation parameter
Osamu Tanifuji1, Takashi Sato, Koichi Kobayashi
1Division of Orthopaedic Surgery, Department of Regenerative and Transplant Medicine, Niigata University Graduate School of Medicine and Dental Science, 757 Asahimachi-dori 1, Niigata, Niigata, 951-8510, Japan, tanifuji06242000@yahoo.co.jp.

Purpose:
The transepicondylar axis (TEA) has been used as a flexion axis of the knee and a reference of the rotational alignment of the femoral component. However, no study has showed dynamic normal knee kinematics employing TEA as the evaluation parameter throughout the full range of motion in vivo. The purpose of this study was to analyze dynamic kinematics of the normal knee through the full range of motion via the 3-dimensional to 2-dimensional registration technique employing TEA as the evaluation parameter.
Methods:
Dynamic motion of the right knee was analyzed in 20 healthy volunteers (10 female, 10 male; mean age 37.2 years). Knee motion was observed as subjects squatted from standing with knee fully extended to maximum flexion. The following parameters were determined: (1) Anteroposterior translations of the medial and lateral ends of the TEA; and (2) changes in the angle of the TEA on the tibial axial plane (rotation angle).
Results:
The medial end of the TEA demonstrated anterior translation (3.6 ± 3.0 mm) from full extension to 30° flexion and demonstrated posterior translation (18.1 ± 3.7 mm) after 30°, while the lateral end of the TEA demonstrated consistent posterior translation (31.1 ± 7.3 mm) throughout knee flexion. All subjects exhibited femoral external rotation (16.9 ± 6.2°) relative to the tibia throughout knee flexion.
Conclusion:
Compared to previously used parameters, the TEA showed bicondylar posterior translation from early flexion phase. These results provide control data for dynamic kinematic analyses of pathologic knees in the future and will be useful in the design of total knee prostheses.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris group...
 01:10
Relative Motion Analysis - Acceleration