Related Experiment Video
Updated: May 22, 2026
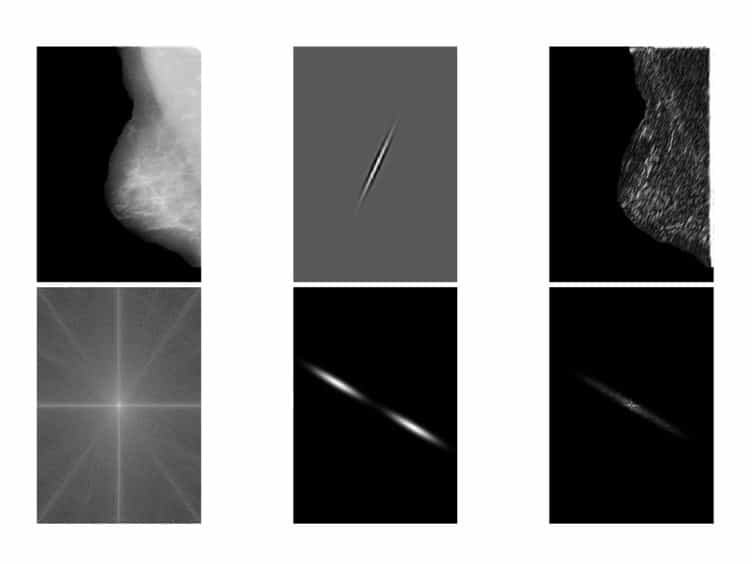

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Geometry of inertial manifolds probed via a Lyapunov projection method
1Institute of Mechatronics, Reichenhainer Strasse 88, D-09126 Chemnitz, Germany.

Abstract:
A method for determining the dimension and state space geometry of inertial manifolds of dissipative extended dynamical systems is presented. It works by projecting vector differences between reference states and recurrent states onto local linear subspaces spanned by the Lyapunov vectors. A sharp characteristic transition of the projection error occurs as soon as the number of basis vectors is increased beyond the inertial manifold dimension. Since the method can be applied using standard orthogonal Lyapunov vectors, it provides a possible way to also determine experimentally inertial manifolds and their geometric characteristics.

Related Concept Videos
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...
 01:03
Inertial Frames of Reference