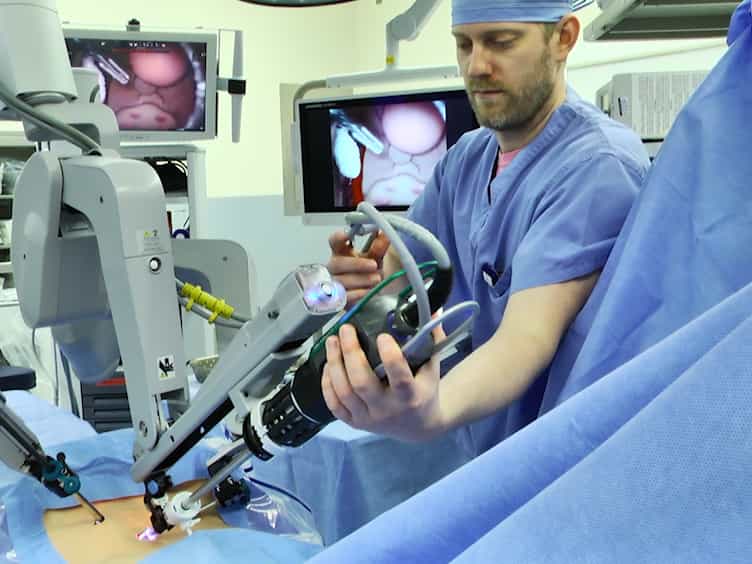
Related Experiment Video
Updated: May 22, 2026


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Selective automation and skill transfer in medical robotics: a demonstration on surgical knot-tying
Alois Knoll1, Hermann Mayer, Christoph Staub
1Robotics and Embedded Systems, Technische Universität München, Garching, Germany. knoll@in.tum.de

Background:
Transferring non-trivial human manipulation skills to robot systems is a challenging task. There have been a number of attempts to design research systems for skill transfer, but the level of the complexity of the actual skills transferable to the robot was rather limited, and delicate operations requiring a high dexterity and long action sequences with many sub-operations were impossible to transfer.
Methods:
A novel approach to human-machine skill transfer for multi-arm robot systems is presented. The methodology capitalizes on the metaphor of 'scaffolded learning', which has gained widespread acceptance in psychology. The main idea is to formalize the superior knowledge of a teacher in a certain way to generate support for a trainee. In our case, the scaffolding is constituted by abstract patterns, which facilitate the structuring and segmentation of information during 'learning by demonstration'. The actual skill generalization is then based on simulating fluid dynamics.
Results:
The approach has been successfully evaluated in the medical domain for the delicate task of automated knot-tying for suturing with standard surgical instruments and a realistic minimally invasive robotic surgery system.