Related Experiment Video
Updated: May 22, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Ophiuroid robot that self-organizes periodic and non-periodic arm movements
Takeshi Kano1, Shota Suzuki, Wataru Watanabe
1Research Institute of Electrical Communication, Tohoku University, 2-1-1 Katahira, Aoba-ku, Sendai 980-8577, Japan. tkano@riec.tohoku.ac.jp

Abstract:
Autonomous decentralized control is a key concept for understanding the mechanism underlying adaptive and versatile locomotion of animals. Although the design of an autonomous decentralized control system that ensures adaptability by using coupled oscillators has been proposed previously, it cannot comprehensively reproduce the versatility of animal behaviour. To tackle this problem, we focus on using ophiuroids as a simple model that exhibits versatile locomotion including periodic and non-periodic arm movements. Our existing model for ophiuroid locomotion uses an active rotator model that describes both oscillatory and excitatory properties. In this communication, we develop an ophiuroid robot to confirm the validity of this proposed model in the real world. We show that the robot travels by successfully coordinating periodic and non-periodic arm movements in response to external stimuli.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 00:51
Anatomical Movements
Here are some common anatomical movements:
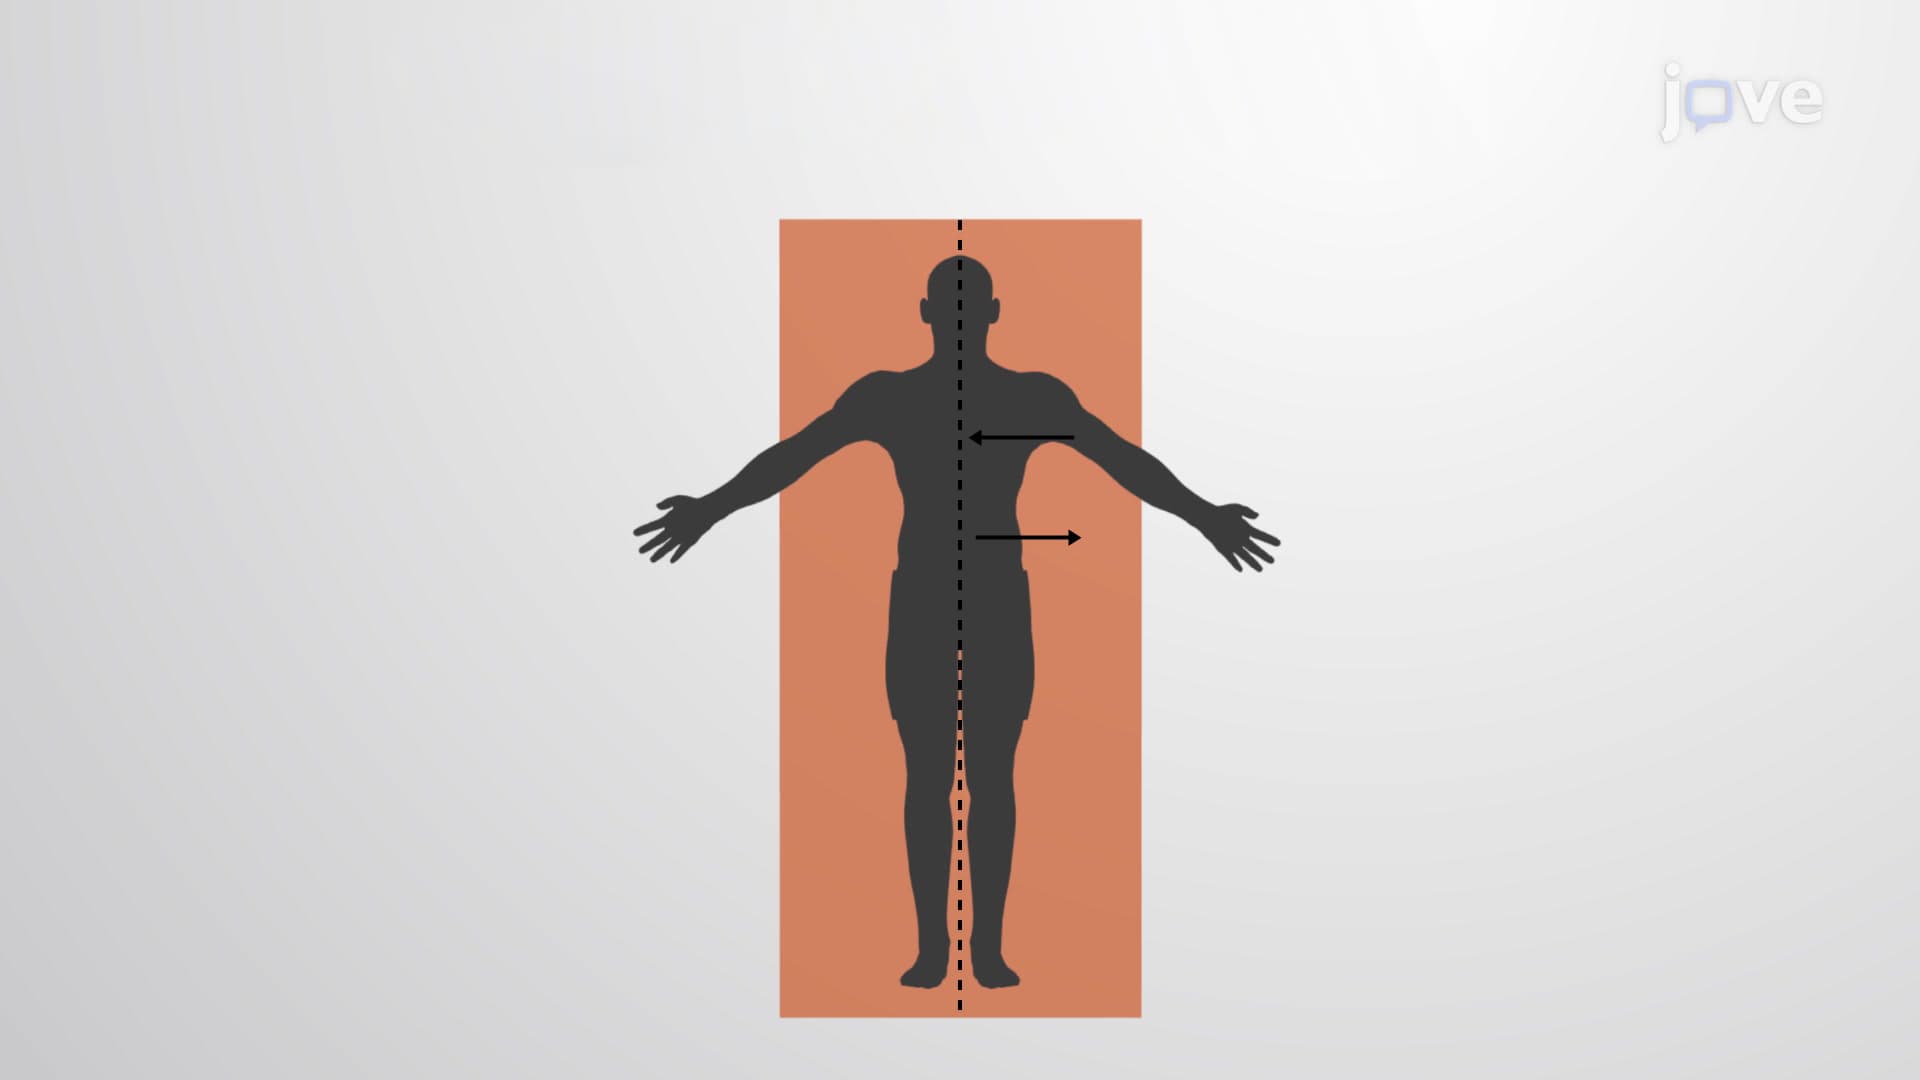
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist, metacarpophalangeal,...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:21
Simple Harmonic Motion