Related Experiment Video
Updated: May 21, 2026

Measuring Attention and Visual Processing Speed by Model-based Analysis of Temporal-order Judgments
Published on: January 23, 2017
A comparison of alternative variants of the lead and lag time TTO
Nancy Devlin1, Ken Buckingham, Koonal Shah
1Office of Health Economics, London, UK. ndevlin@ohe.org

Abstract:
'Lead Time' TTO improves upon conventional TTO by providing a uniform method for eliciting positive and negative values. This research investigates (i) the values generated from different combinations of time in poor health and in full health; and the order in which these appear (lead vs. lag); (ii) whether values concur with participants' views about states; (iii) methods for handling extreme preferences. n = 208 participants valued five EQ-5D states, using two of four variants. Combinations of lead time and health state duration were: 10 years and 20 years; 5 years and 1 year; 5 years and 10 years; and a health state duration of 5 years with a lag time of 10 years. Longer lead times capture more preferences, but may involve a framing effect. Lag time results in less non-trading for mild states, and less time being traded for severe states. Negative values broadly agree with participants' stated opinion that the state is worse than dead. The values are sensitive to the ratio of lead time to duration of poor health, and the order in which these appear (lead vs. lag). It is feasible to handle extreme preferences though challenges remain.
Related Concept Videos
 01:09
Comparing Experimental Results: Student's t-Test
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
 01:22
Mean free path and Mean free time
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
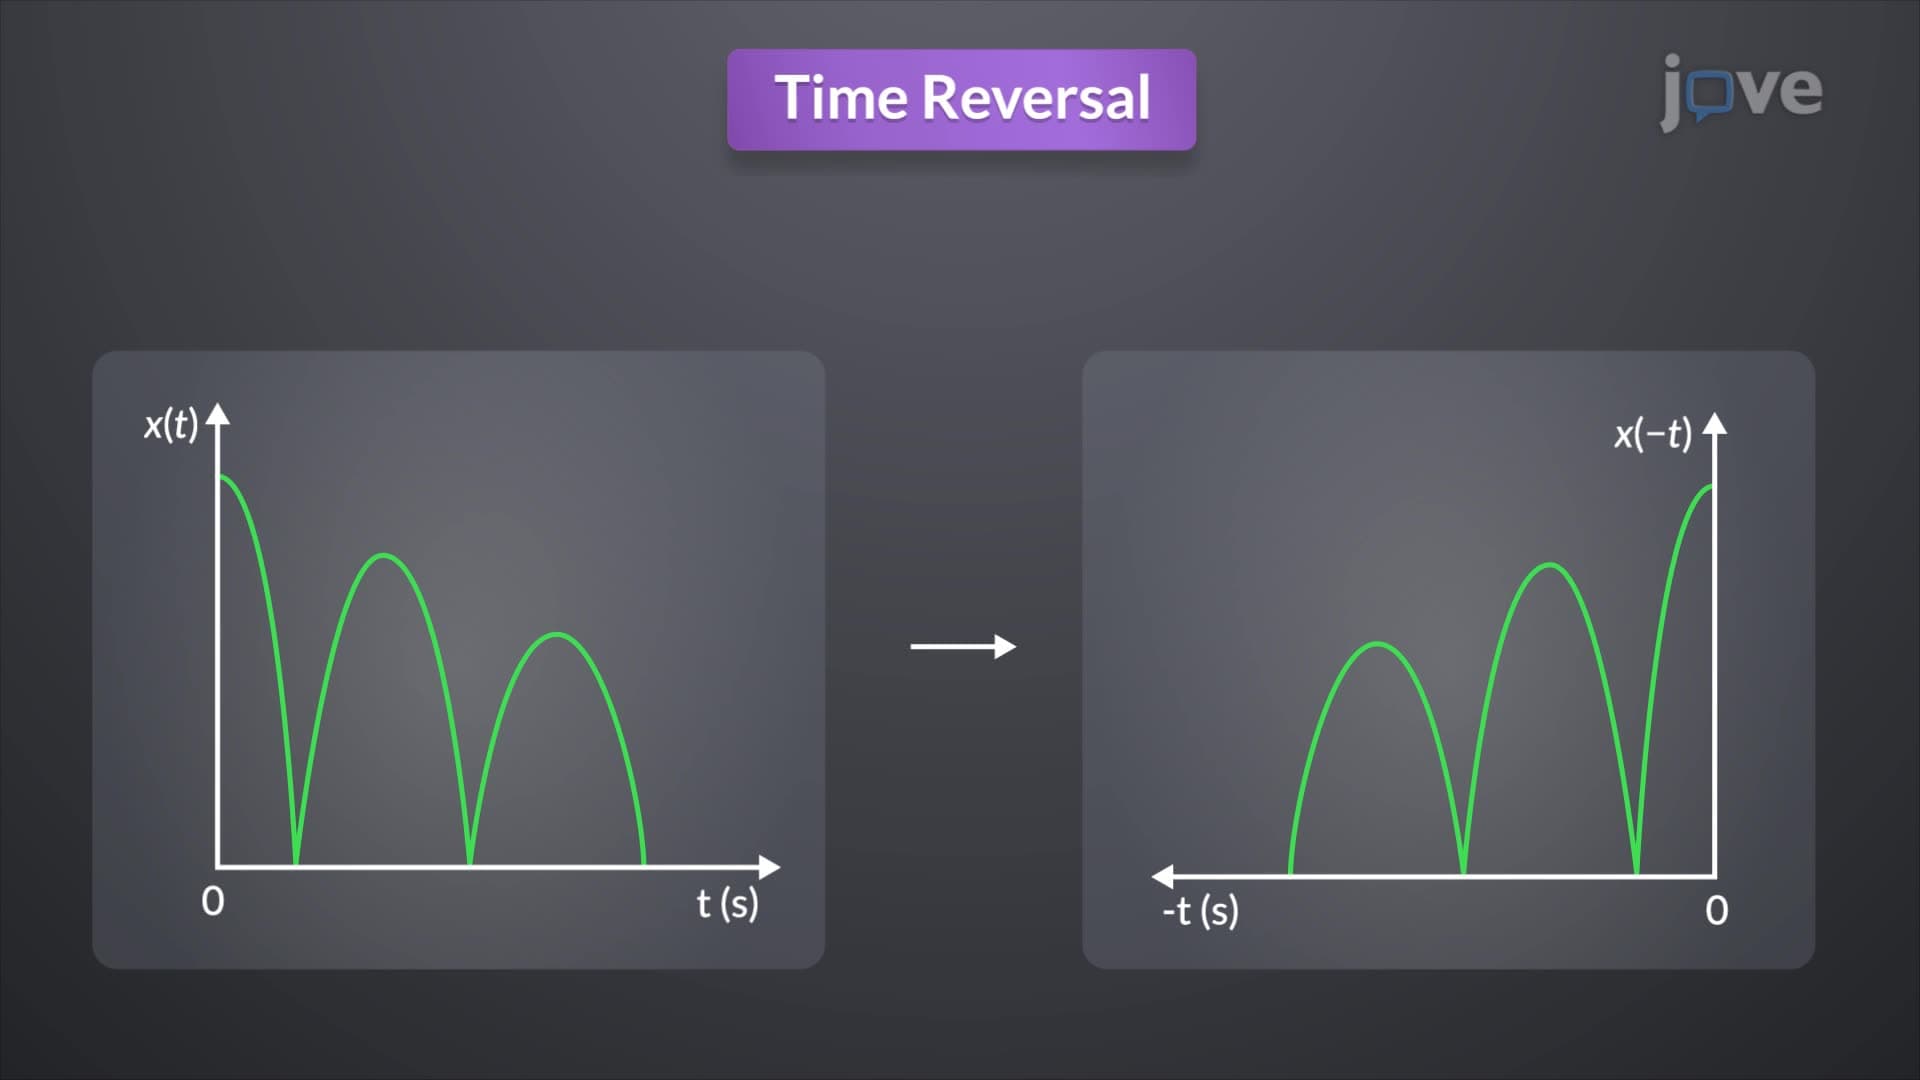 01:22
Basic Operations on Signals
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.