Related Experiment Video
Updated: May 20, 2026


Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Best-compromise between mechanical energy expenditure and foot clearance predicts leading limb motion during
Tung-Wu Lu1, Sheng-Chang Chen, Hung-Chie Chiu
1Institute of Biomedical Engineering, National Taiwan University, Taiwan. twlu@ntu.edu.tw

Abstract:
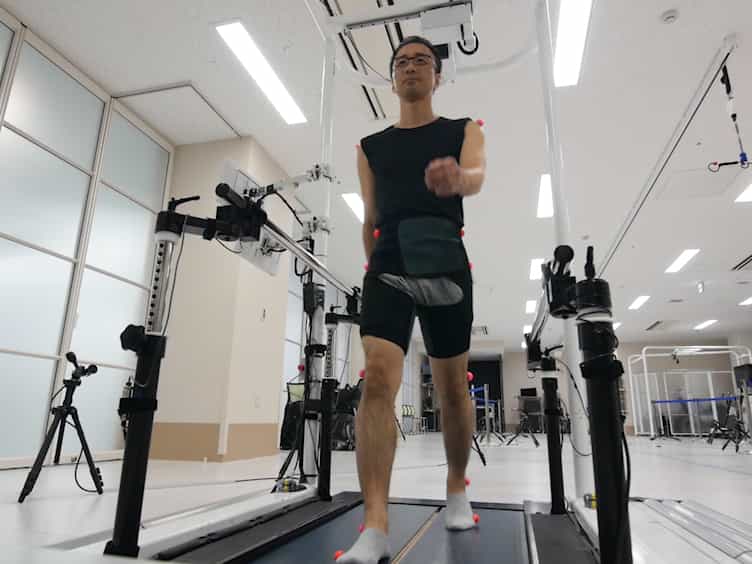
This study aimed to identify the control strategy of obstacle-crossing of different heights with a multi-objective optimal control technique. Twelve young healthy adults walked and crossed obstacles of three different heights while their kinematic and ground reaction force data were measured simultaneously. Obstacle-crossing was formulated as an optimal control problem with two conflicting objectives: minimization of mechanical energy expenditure and maximization of foot-obstacle clearance. The results supported the hypothesis that experimentally measured ankle trajectories and joint angles of the swing limb and the joint moments of the stance limb could be predicted by the best compromise between these objectives, which was also independent of obstacle height. This control strategy was fundamentally different from that for unobstructed gait, and appeared to be pre-programmed into the nervous system. The results will serve as baseline data and the current technique be used for identifying changes in obstacle-crossing control strategies in people at higher risk of falling.