Pneumatic muscle actuator (PMA) task-specific resistance for potential use in microgravity exercise
Related Experiment Video
Updated: May 20, 2026
Rapid Manufacturing of Thin Soft Pneumatic Actuators and Robots
Published on: November 8, 2019
Kara L Hall1, Chandler A Phillips, David B Reynolds
1Wright State University, Dayton, OH, USA.

Introduction:
A pneumatic muscle actuator (PMA) is a device that mimics the behavior of skeletal muscle by contracting and generating force when activated. This type of actuator has a high power to weight ratio and unique characteristics which make it ideal for human interaction. PMAs, however, are difficult to control due to nonlinear dynamics. Our objective was to control a PMA as a source of task-specific resistance in simulated isokinetic strength training. Task-specific resistance will benefit those in need of strength training through a joint's range of motion, including astronauts who need to counteract muscle atrophy during prolonged spaceflight. The lightweight, clean, and compact PMA driven by pressurized air is able to produce resistance in microgravity.
Methods:
An open-loop control method based on a three-element phenomenological inverse model was developed to control the PMA. A motor was simultaneously controlled to act as simulated human quadriceps working against the PMA-produced resistance.
Results:
For ankle weight replacement resistance profiles, the PMA control method produced resistance and PMA displacement tracking errors (RMSE) of 0.36-1.61 Nm and 0.55-1.59 mm, respectively. Motor position (simulated joint angle) tracking errors ranged from 0.47 to 2.82 degrees.
Discussion:
Results indicate that the inverse model based control system produces task-specific PMA resistance and displacement. Closed-loop motor control was able to simulate isokinetic movement successfully. More complicated resistance profiles reveal the need for closed-loop control. Future work focuses on advancing both the PMA control strategies and the capabilities of the human simulator so that actual human operator applications can be realized.
More Related Videos
Related Concept Videos
 01:34
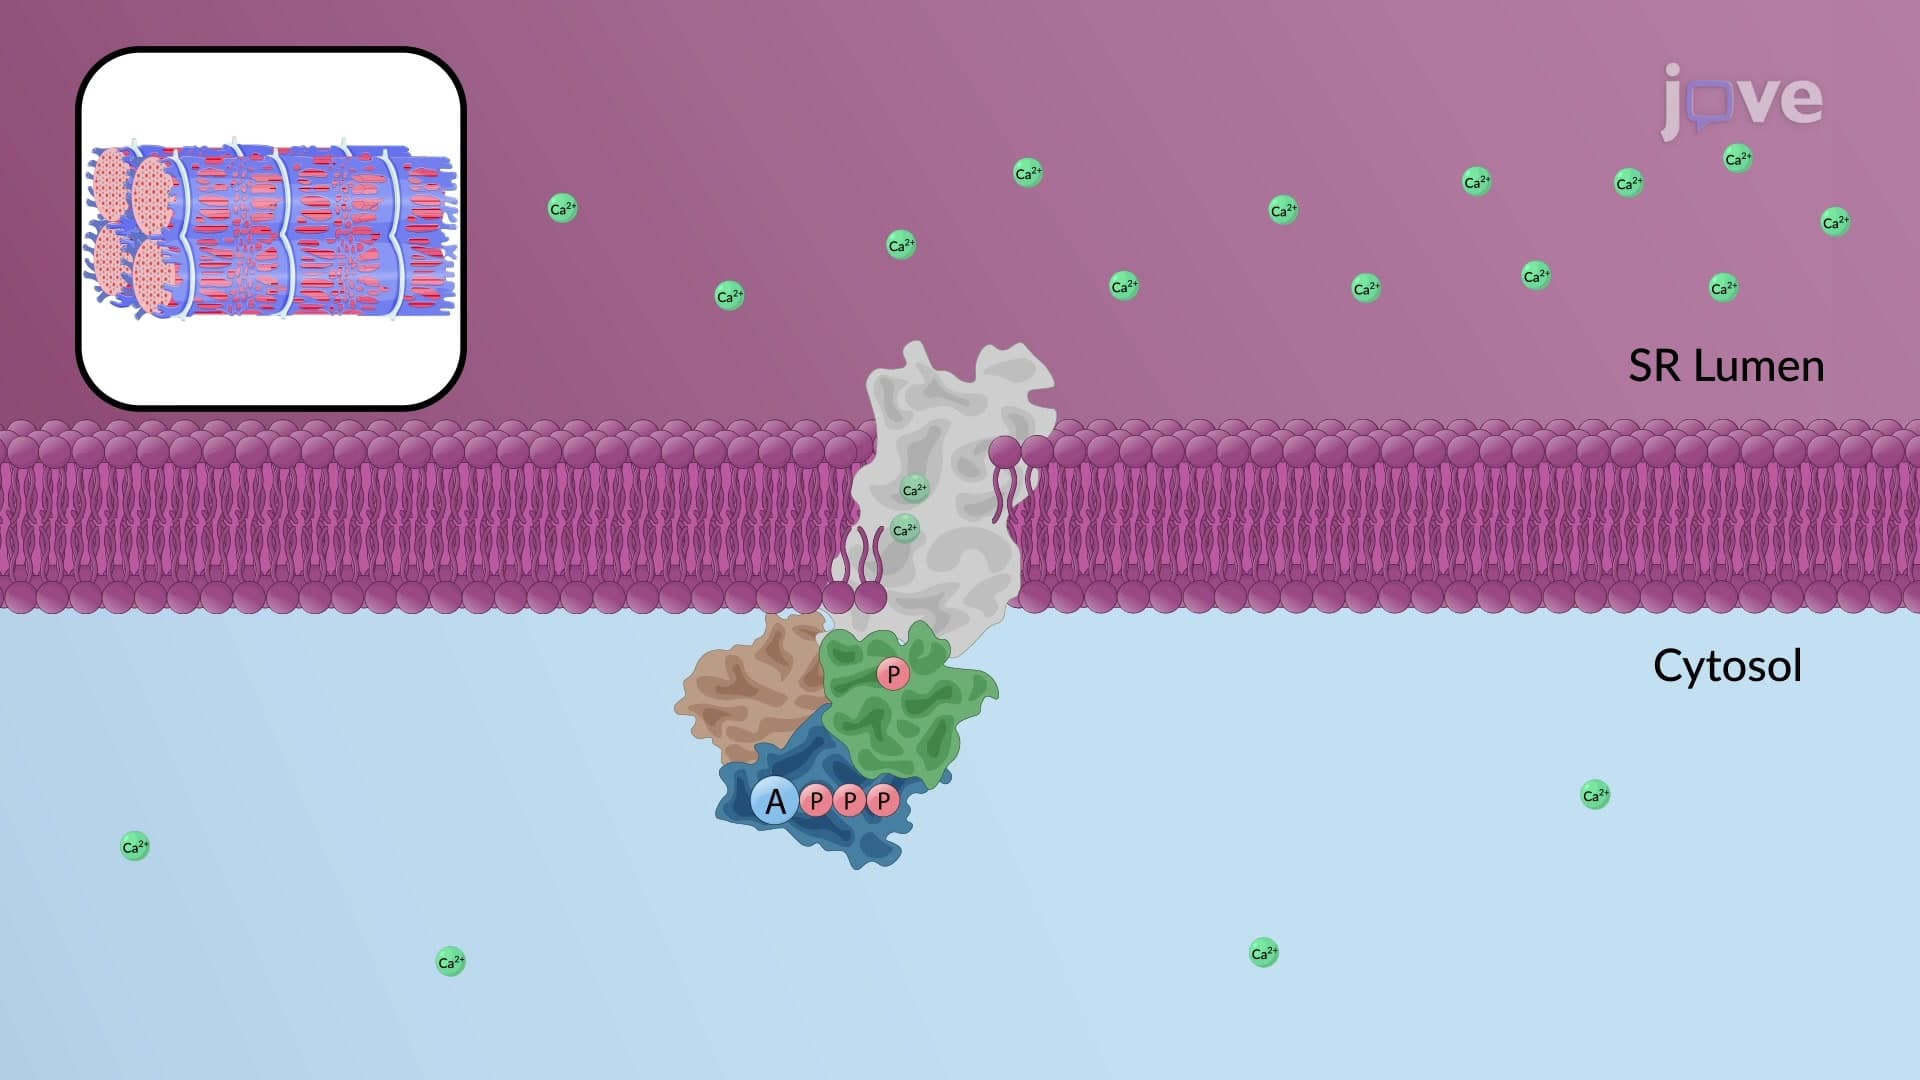
ATP Driven Pumps II: P-type Pumps
A typical P-type pump has three cytosolic domains: nucleotide-binding (N), phosphorylation (P), and activator (A) domains. These domains are connected to the membrane-spanning helices by short amino acid segments. ATP hydrolysis and covalent phosphoenzyme intermediate formation are crucial parts of the catalytic cycle. At the highly...
 01:14
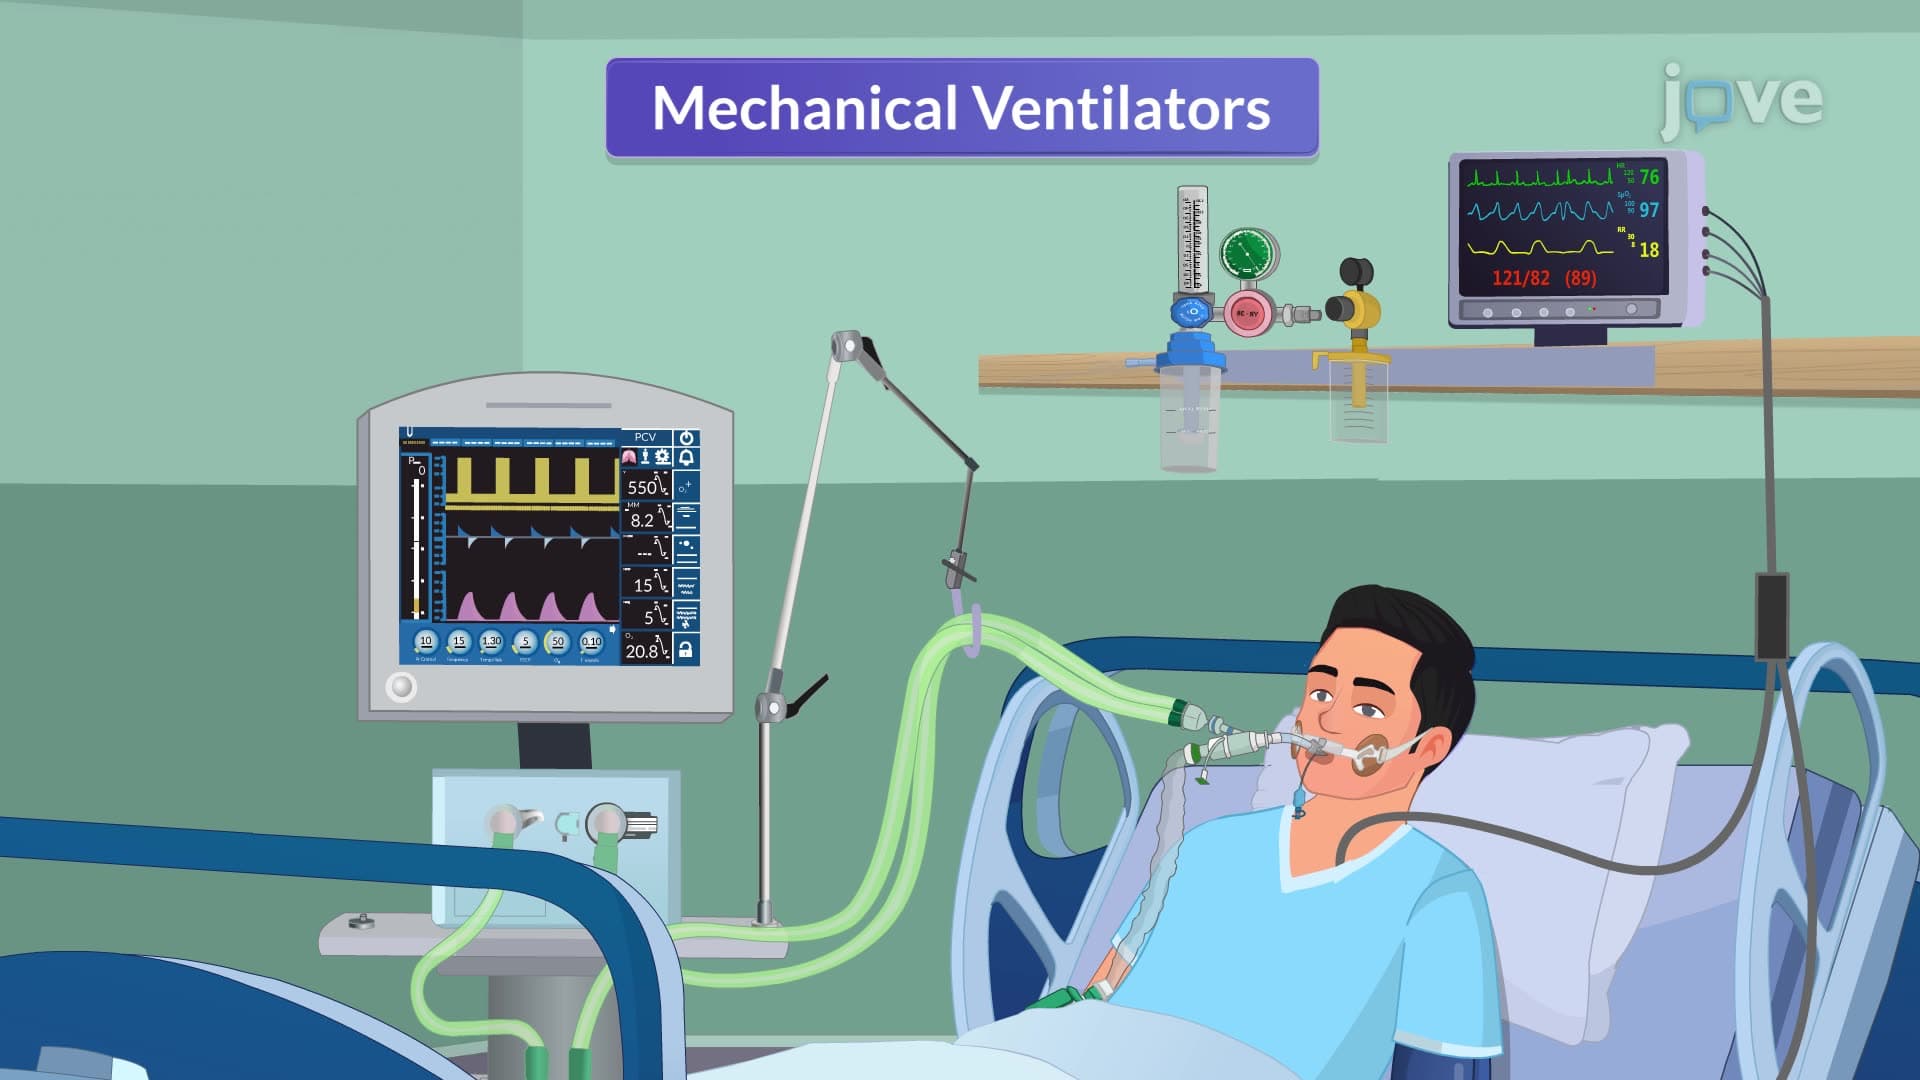
Ventilatory Modes
There are three ventilatory modes: full support, partial support, and spontaneous. These are described below.
Full Support Modes
Full support modes include controlled mechanical ventilation, continuous mandatory...