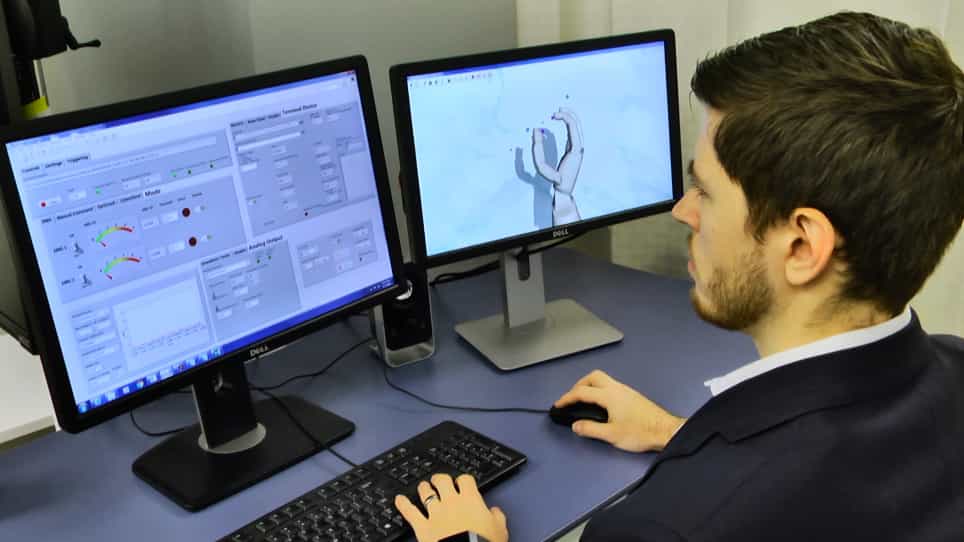
Related Experiment Video
Updated: May 19, 2026
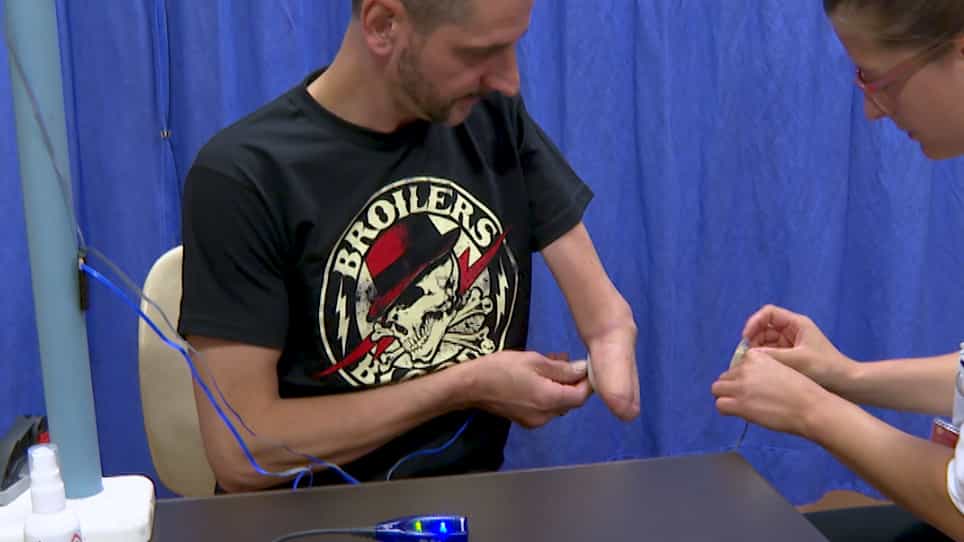

Surface Electromyographic Biofeedback as a Rehabilitation Tool for Patients with Global Brachial Plexus Injury Receiving Bionic Reconstruction
Published on: September 28, 2019
Haptic feedback enhances grip force control of sEMG-controlled prosthetic hands in targeted reinnervation amputees
Keehoon Kim1, J Edward Colgate
1Interaction and Robotics Research Center, Korea Institute of Science and Technology, Seoul 136-791, Korea. khk@kist.re.kr

Abstract:
In this study, we hypothesized that haptic feedback would enhance grip force control of surface electromyography (sEMG)-controlled prosthetic hands for targeted reinnervation (TR) amputees. A new miniature haptic device, a tactor, that can deliver touch, pressure, shear, and temperature sensation, allows modality-matching haptic feedback. TR surgery that creates sensory regions on the patient's skin that refer to the surface of the missing limb allows somatotopic-matching haptic feedback. This paper evaluates the hypothesis via an sEMG-controlled virtual prosthetic arm operated by TR amputees under diverse haptic feedback conditions. The results indicate that the grip force control is significantly enhanced via the haptic feedback. However, the simultaneous display of two haptic channels (pressure and shear) does not enhance, but instead degrades, grip force control.