Related Experiment Video
Updated: May 19, 2026

Computational Modeling of Retinal Neurons for Visual Prosthesis Research - Fundamental Approaches
Published on: June 21, 2022
A nonlinear autoregressive Volterra model of the Hodgkin-Huxley equations
Steffen E Eikenberry1, Vasilis Z Marmarelis
1Department of Biomedical Engineering, University of Southern California, 1042 Downey Way, Los Angeles, CA 90089, USA. seikenbe@usc.edu

Abstract:
We propose a new variant of Volterra-type model with a nonlinear auto-regressive (NAR) component that is a suitable framework for describing the process of AP generation by the neuron membrane potential, and we apply it to input-output data generated by the Hodgkin-Huxley (H-H) equations. Volterra models use a functional series expansion to describe the input-output relation for most nonlinear dynamic systems, and are applicable to a wide range of physiologic systems. It is difficult, however, to apply the Volterra methodology to the H-H model because is characterized by distinct subthreshold and suprathreshold dynamics. When threshold is crossed, an autonomous action potential (AP) is generated, the output becomes temporarily decoupled from the input, and the standard Volterra model fails. Therefore, in our framework, whenever membrane potential exceeds some threshold, it is taken as a second input to a dual-input Volterra model. This model correctly predicts membrane voltage deflection both within the subthreshold region and during APs. Moreover, the model naturally generates a post-AP afterpotential and refractory period. It is known that the H-H model converges to a limit cycle in response to a constant current injection. This behavior is correctly predicted by the proposed model, while the standard Volterra model is incapable of generating such limit cycle behavior. The inclusion of cross-kernels, which describe the nonlinear interactions between the exogenous and autoregressive inputs, is found to be absolutely necessary. The proposed model is general, non-parametric, and data-derived.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:27
Linear Differential Equations
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:25
Modeling with Differential Equations
 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
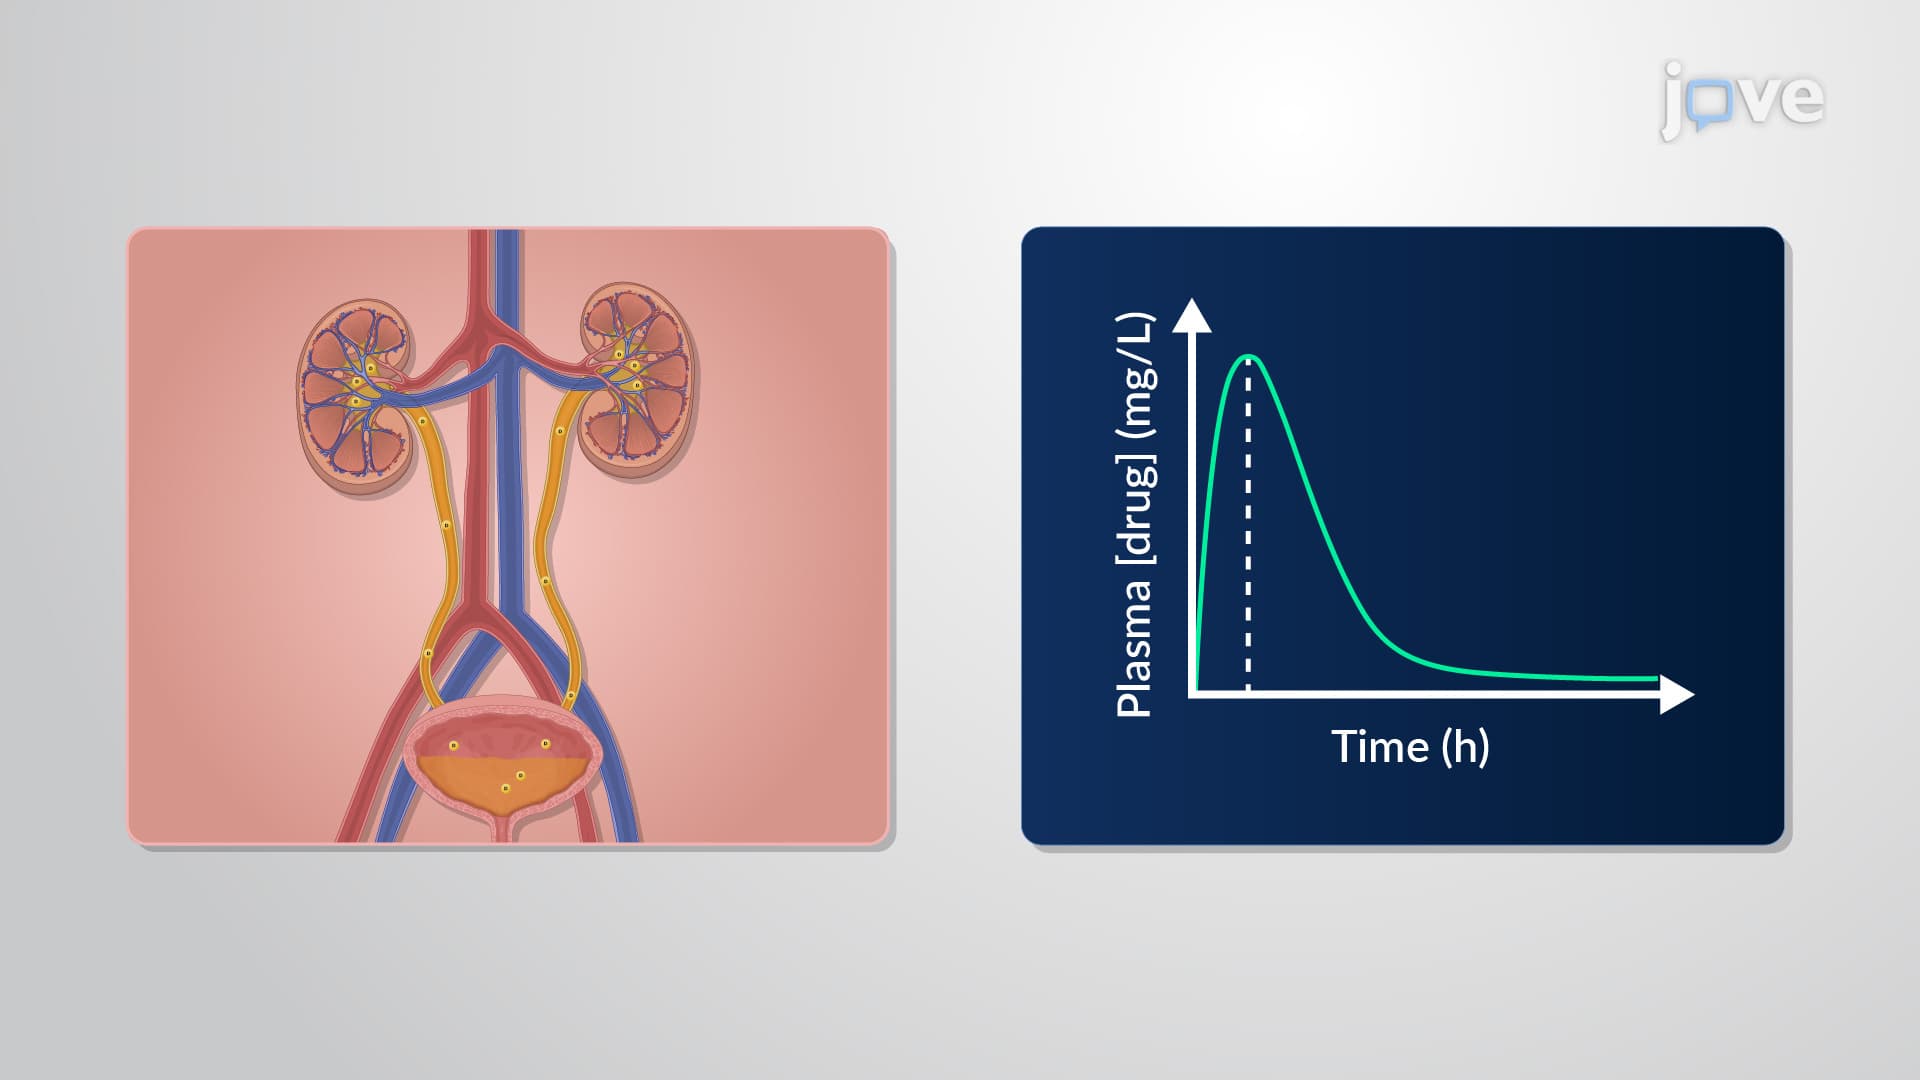
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...