Maintaining a cognitive map in darkness: the need to fuse boundary knowledge with path integration
Related Experiment Video
Updated: May 19, 2026
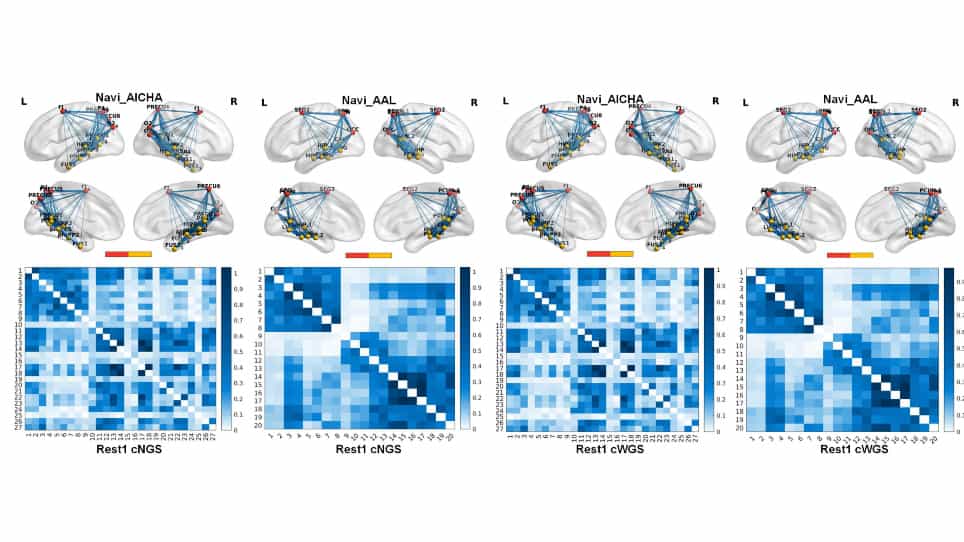
Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Allen Cheung1, David Ball, Michael Milford
1The University of Queensland, Queensland Brain Institute, Brisbane, Queensland, Australia. a.cheung@uq.edu.au

Abstract:
Spatial navigation requires the processing of complex, disparate and often ambiguous sensory data. The neurocomputations underpinning this vital ability remain poorly understood. Controversy remains as to whether multimodal sensory information must be combined into a unified representation, consistent with Tolman's "cognitive map", or whether differential activation of independent navigation modules suffice to explain observed navigation behaviour. Here we demonstrate that key neural correlates of spatial navigation in darkness cannot be explained if the path integration system acted independently of boundary (landmark) information. In vivo recordings demonstrate that the rodent head direction (HD) system becomes unstable within three minutes without vision. In contrast, rodents maintain stable place fields and grid fields for over half an hour without vision. Using a simple HD error model, we show analytically that idiothetic path integration (iPI) alone cannot be used to maintain any stable place representation beyond two to three minutes. We then use a measure of place stability based on information theoretic principles to prove that featureless boundaries alone cannot be used to improve localization above chance level. Having shown that neither iPI nor boundaries alone are sufficient, we then address the question of whether their combination is sufficient and--we conjecture--necessary to maintain place stability for prolonged periods without vision. We addressed this question in simulations and robot experiments using a navigation model comprising of a particle filter and boundary map. The model replicates published experimental results on place field and grid field stability without vision, and makes testable predictions including place field splitting and grid field rescaling if the true arena geometry differs from the acquired boundary map. We discuss our findings in light of current theories of animal navigation and neuronal computation, and elaborate on their implications and significance for the design, analysis and interpretation of experiments.
More Related Videos
Related Concept Videos
 01:42
Schemas
 01:15
Depth Perception and Spatial Vision
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:12
Visual Agnosia
 01:21
Gestalt Principles of Perception
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...