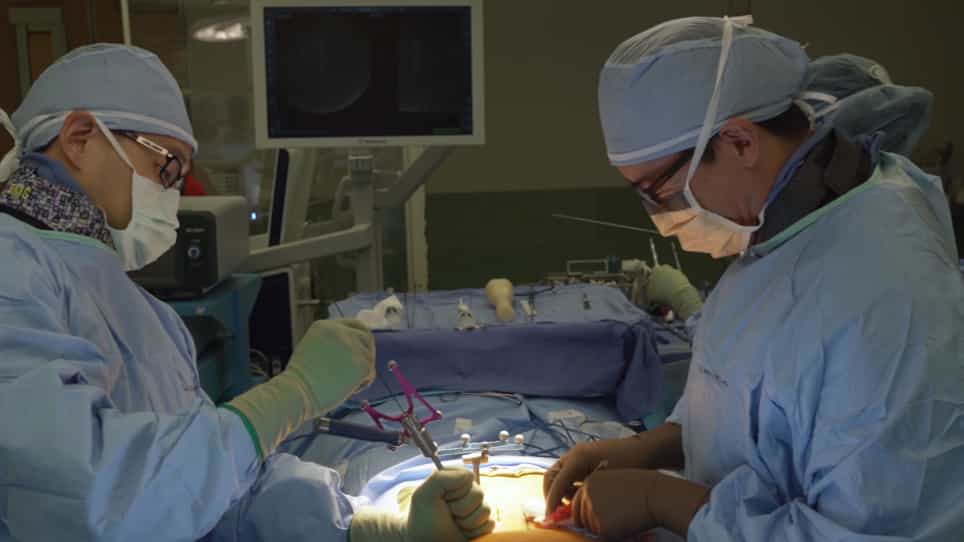
Related Experiment Video
Updated: May 18, 2026


A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Computer-assisted fluoroscopic navigation of percutaneous spinal interventions
Jörg A K Ohnsorge1, Khaled H Salem, Andreas Ladenburger
1Helmholtz-Institute of Biomedical Technologies, RWTH Aachen University, Aachen, Germany. joerg.ohnsorge@kk-om.de

Purpose:
Percutaneous spine procedures may occasionally be difficult and subject to complications. Navigation using a dynamic reference base (DRB) may ease the procedure. Yet, besides other shortcomings, its fixation demands additional incisions and thereby defies the percutaneous character of the procedure.
Methods:
A new concept of atraumatic referencing was invented including a special epiDRB. The accuracy of navigated needle placement in soft tissue and bone was experimentally scrutinised. Axial and pin-point deviations from the planned trajectory were investigated with a CT-based 3D computer system. Clinical evaluation in a series of ten patients was also done.
Results:
The new epiDRB proved convenient and reliable. Its fixation to the skin with adhesive foil provided a stable reference for navigation that improves the workflow of percutaneous interventions, reduces radiation exposure and helps avoid complications.
Conclusions:
Percutaneous spine interventions can be safely and accurately navigated using epiDRB with minimal trauma or radiation exposure and without additional skin incisions.