Related Experiment Video
Updated: May 18, 2026

Implementation of a Reference Interferometer for Nanodetection
Published on: April 26, 2014
Understanding the effects of Doppler phenomena in white light Fabry-Perot interferometers for simultaneous position
Erik A Moro1, Michael D Todd, Anthony D Puckett
1Department of Structural Engineering, University of California San Diego, La Jolla, 92093, USA. moro@lanl.gov

Abstract:
In static tests, low-power (<5 mW) white light extrinsic Fabry-Perot interferometric position sensors offer high-accuracy (μm) absolute measurements of a target's position over large (cm) axial-position ranges, and since position is demodulated directly from phase in the interferogram, these sensors are robust to fluctuations in measured power levels. However, target surface dynamics distort the interferogram via Doppler shifting, introducing a bias in the demodulation process. With typical commercial off-the-shelf hardware, a broadband source centered near 1550 nm, and an otherwise typical setup, the bias may be as large as 50-100 μm for target surface velocities as low as 0.1 mm/s. In this paper, the authors derive a model for this Doppler-induced position bias, relating its magnitude to three swept-filter tuning parameters. Target velocity (magnitude and direction) is calculated using this relationship in conjunction with a phase-diversity approach, and knowledge of the target's velocity is then used to compensate exactly for the position bias. The phase-diversity approach exploits side-by-side measurement signals, transmitted through separate swept filters with distinct tuning parameters, and permits simultaneous measurement of target velocity and target position, thereby mitigating the most fundamental performance limitation that exists on dynamic white light interferometric position sensors.
Related Concept Videos
 00:56
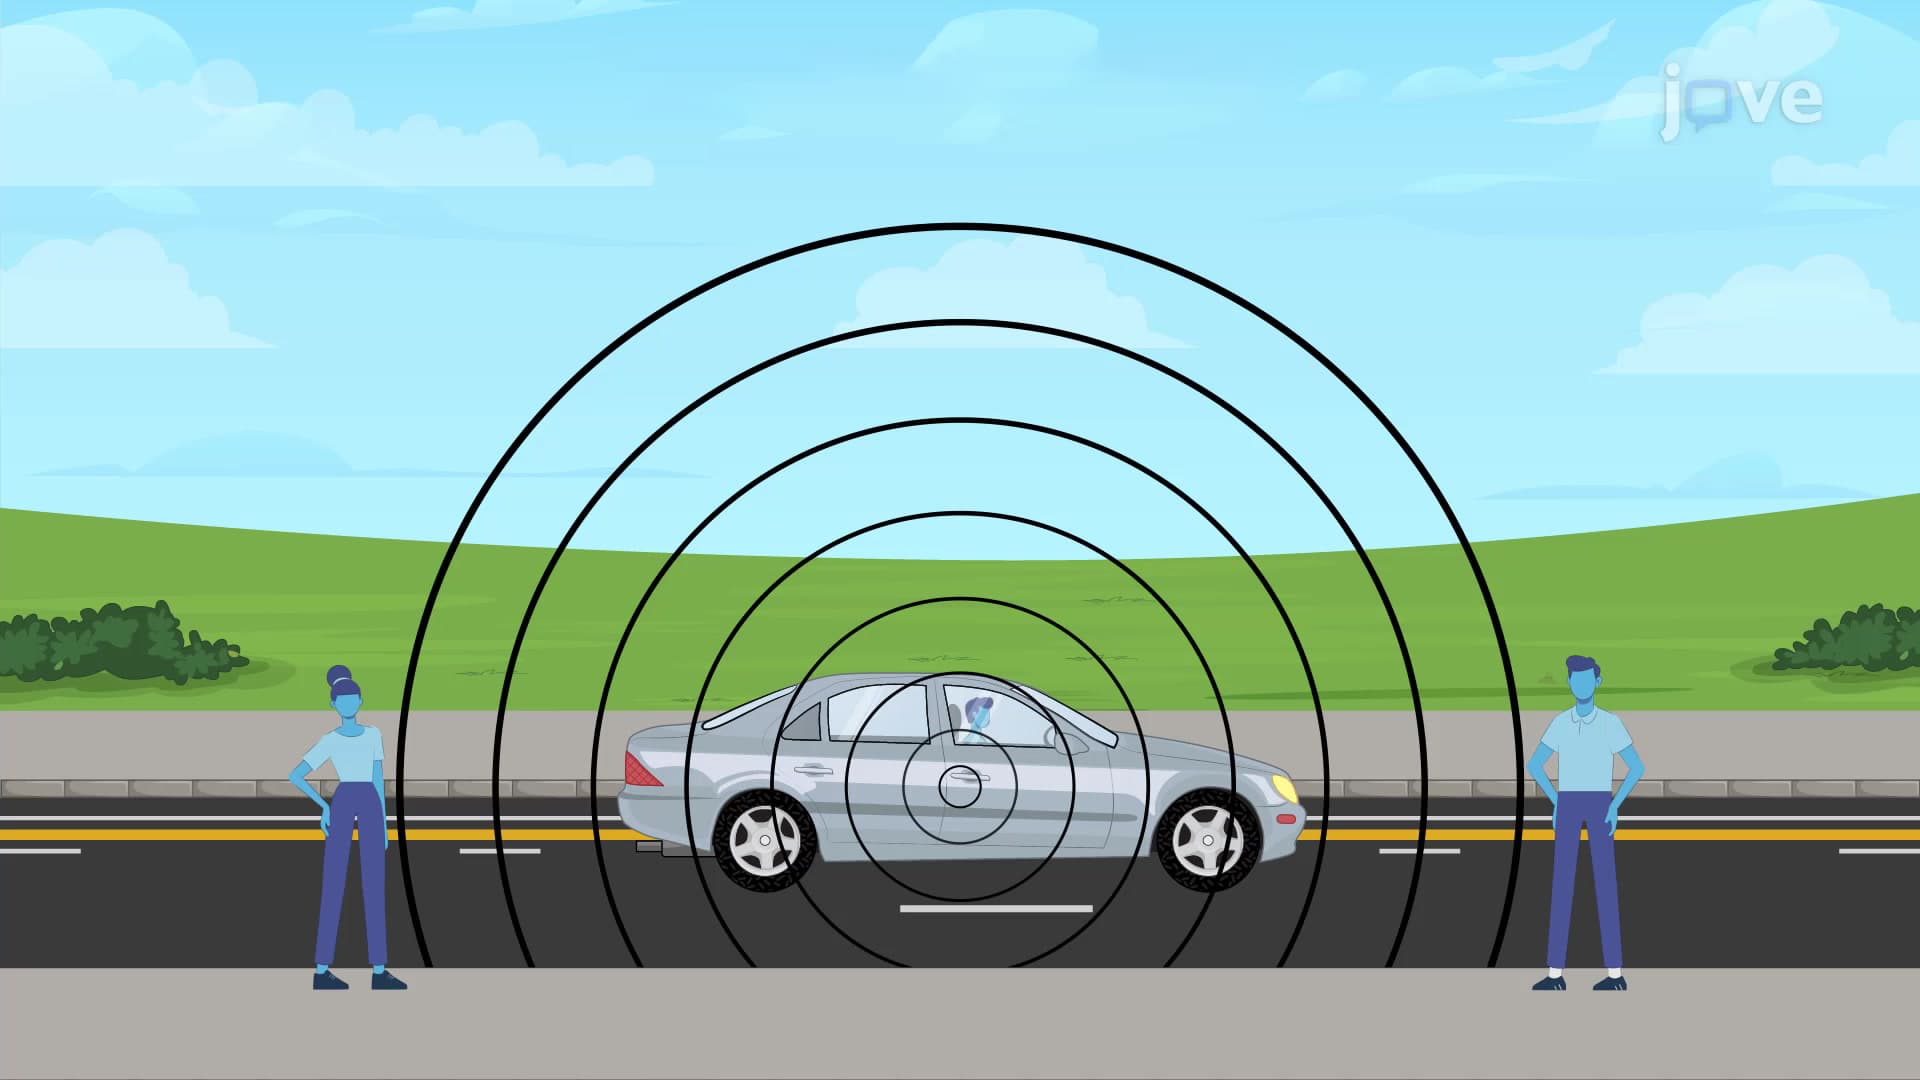
Doppler Effect - I
 01:05
Doppler Effect - II
 01:11
Relative Velocity in Two Dimensions
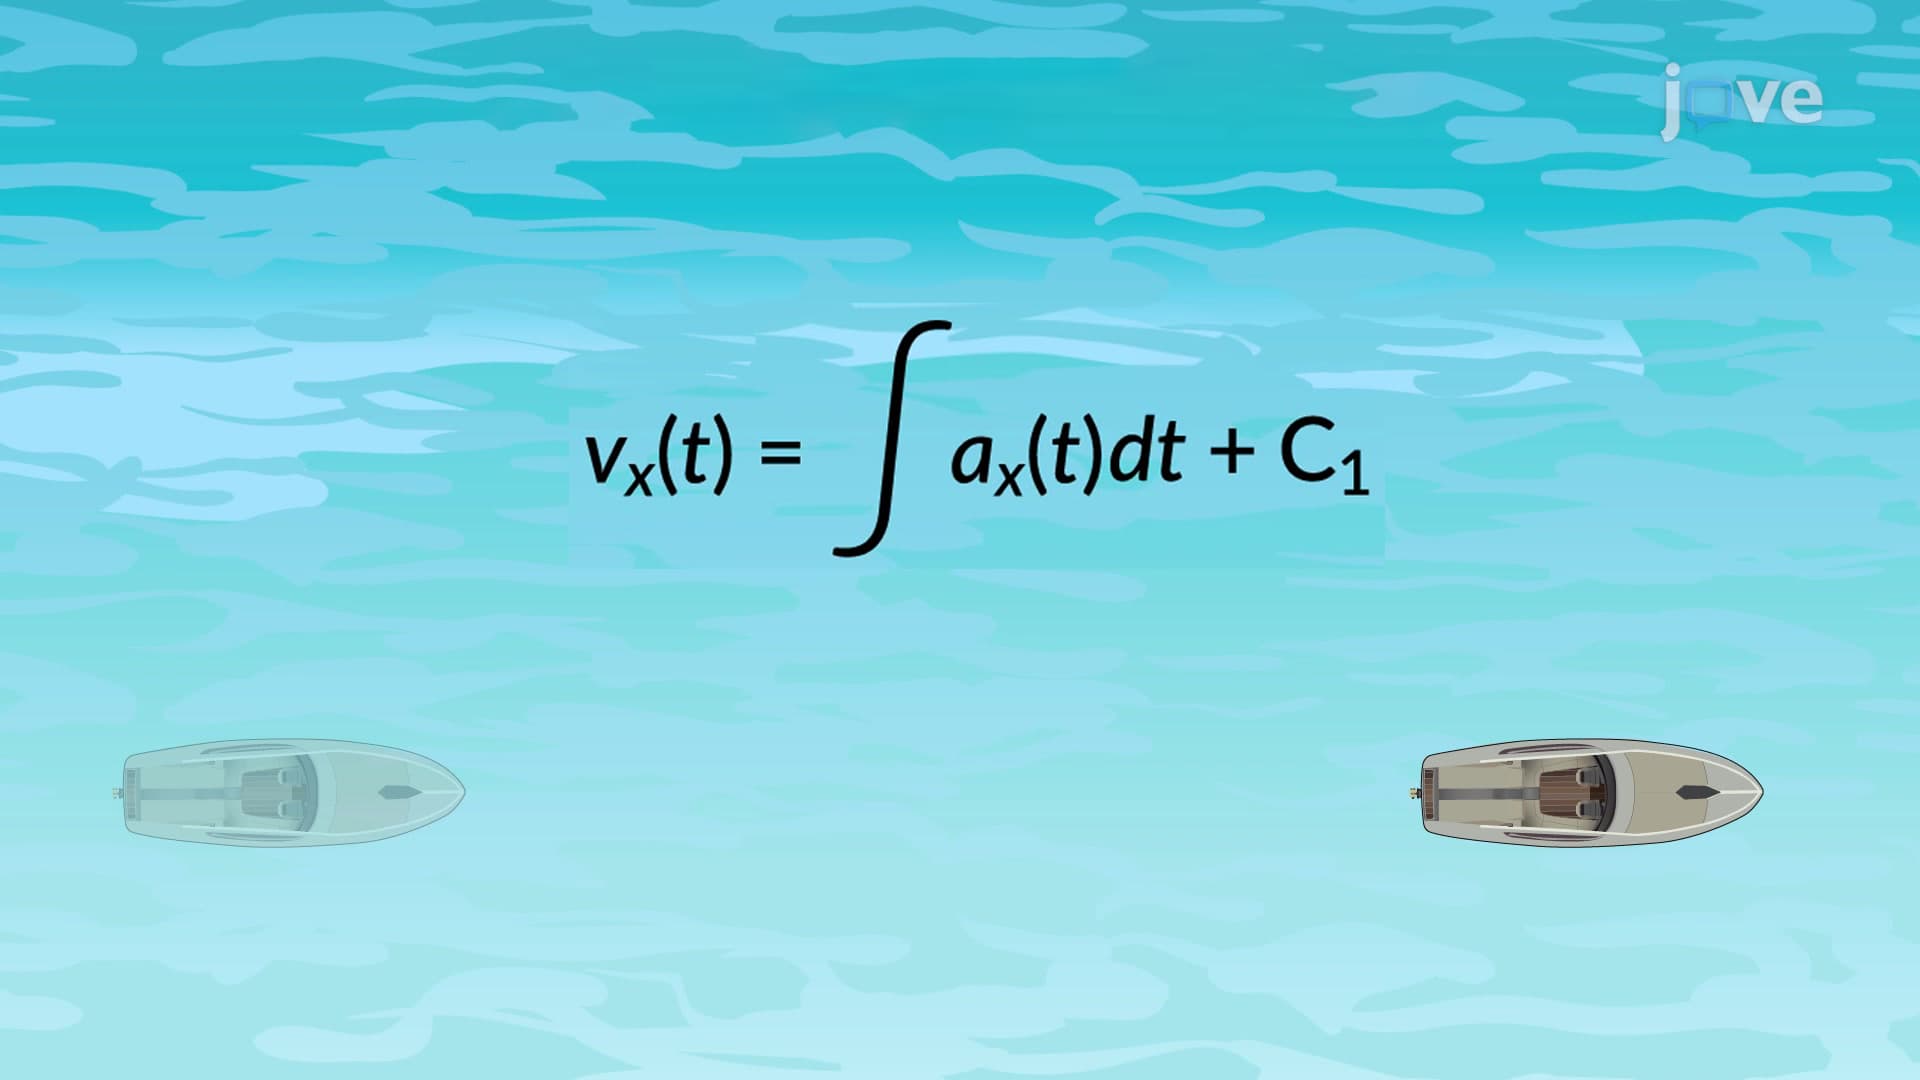 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...