Related Experiment Video
Updated: May 18, 2026

Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Analysis of the stability of PTW riders in autonomous braking scenarios
Ioannis Symeonidis1, Gueven Kavadarli, Schuller Erich
1University of Munich, Institute for Legal Medicine, Nußbaumstr. 26, D-80336 Munich, Germany. ioannis.sym@gmail.com

Abstract:
While fatalities of car occupants in the EU decreased remarkably over the last decade, Powered Two Wheelers (PTWs) fatalities still increase following the increase of PTW ownership. Autonomous braking systems have been implemented in several types of vehicles and are presently addressed by research in the field of PTWs. A major concern in this context is the rider stability. Experiments with volunteers were performed in order to find out whether autonomous braking for PTWs will produce a greater instability of the rider in comparison to manual braking. The PTW's braking conditions were simulated in a laboratory with a motorcycle mock-up mounted on a sled, which was accelerated with an average of 0.35 g. The motion of the rider was captured in autonomous braking scenarios with and without pre-warning as well as in manual braking scenarios. No significant differences between the scenarios were found with respect to maximum forward displacement of the volunteer's torso and head (p<0.05). By performing clustering analysis on two kinematic parameters, two different strategies of the volunteers were identified. They were not related to the braking scenarios. A relation of the clusters with the initial posture represented by the elbow angle was revealed (p<0.05). It is concluded that autonomous braking at low deceleration will not cause significant instabilities of the rider in comparison to manual braking in idealized laboratory conditions. Based on this, further research into the development and implementation of autonomous braking systems for PTWs, e.g. by extensive riding tests, seems valuable.


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:17
Rolling Resistance: Problem Solving
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:28
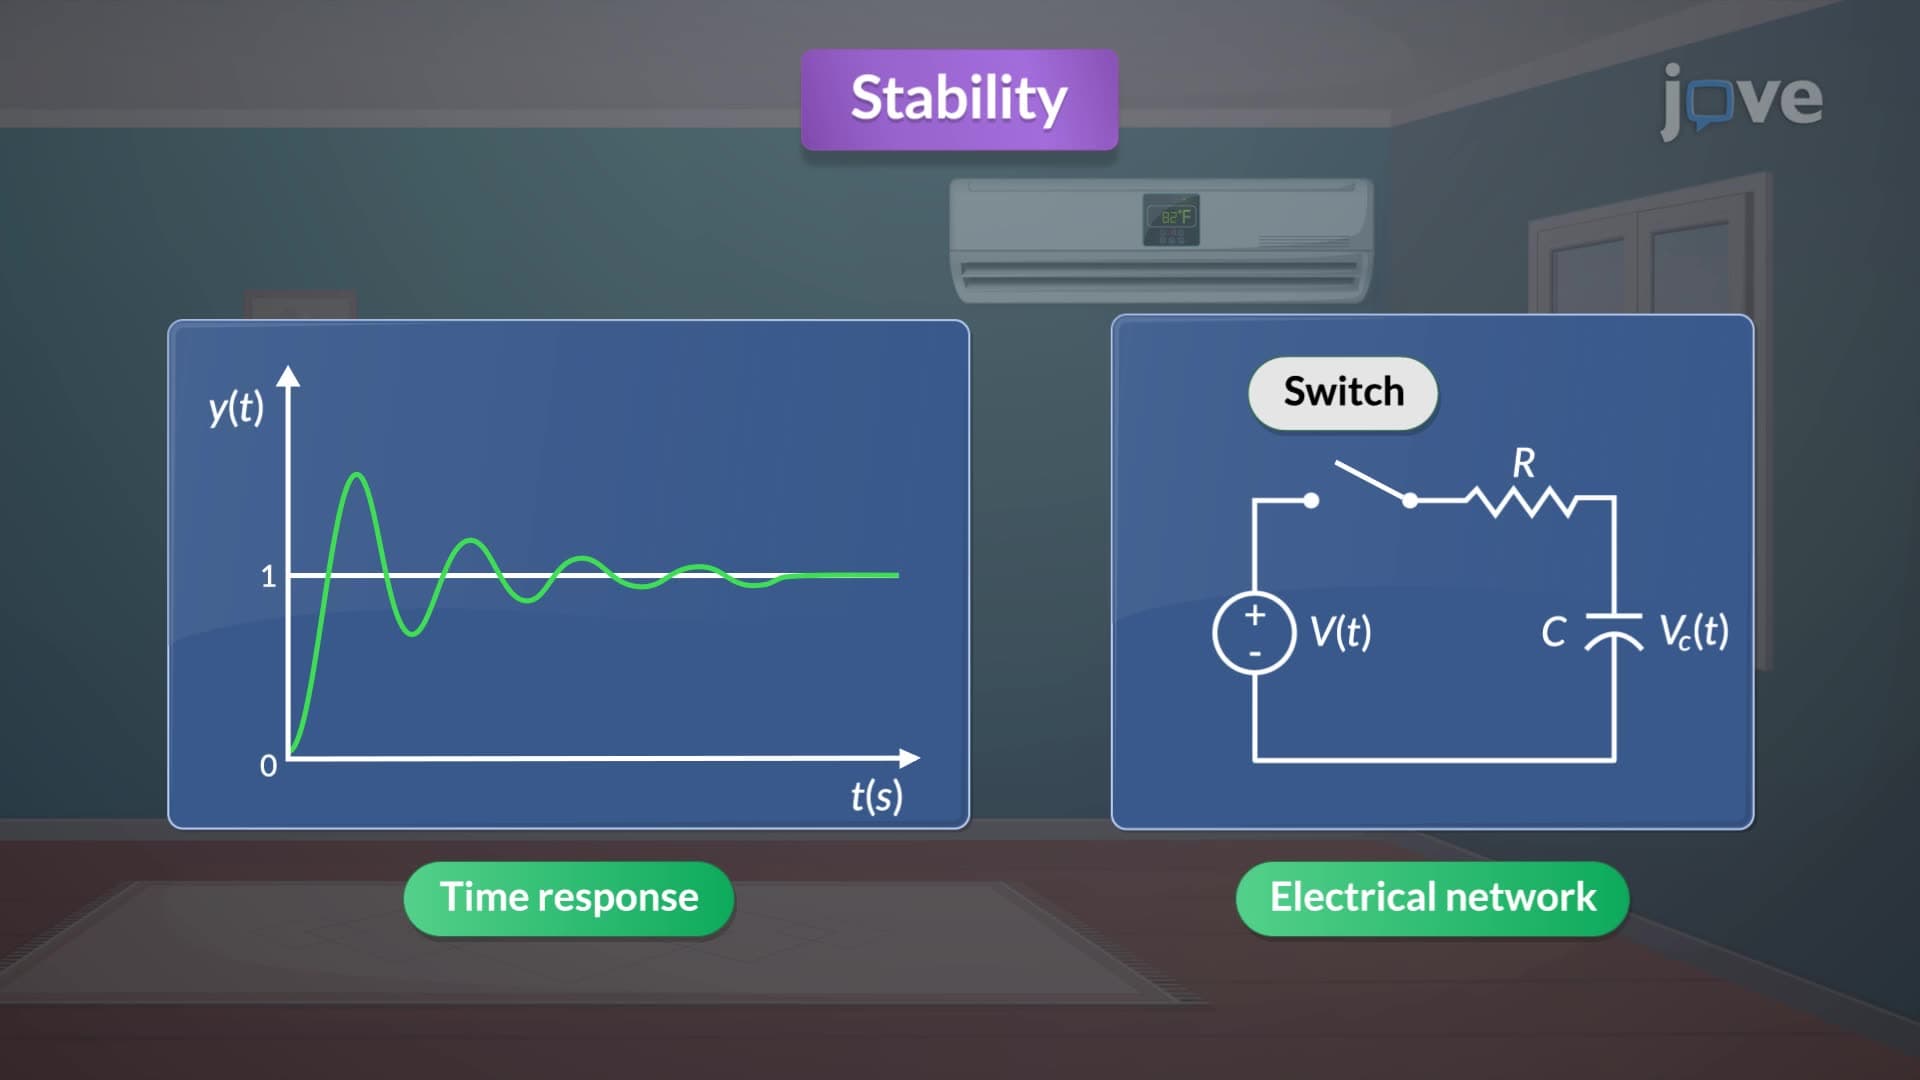
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:14
Stability of structures
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...