Related Experiment Video
Updated: May 18, 2026


An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024
Motor modules in robot-aided walking
Leonardo Gizzi1, Jørgen Feldbæk Nielsen, Francesco Felici
1Pain Clinic, Center for Anesthesiology, Emergency and Intensive Care Medicine, University Hospital Göttingen, Göttingen, Germany.

Background:
It is hypothesized that locomotion is achieved by means of rhythm generating networks (central pattern generators) and muscle activation generating networks. This modular organization can be partly identified from the analysis of the muscular activity by means of factorization algorithms. The activity of rhythm generating networks is described by activation signals whilst the muscle intervention generating network is represented by motor modules (muscle synergies). In this study, we extend the analysis of modular organization of walking to the case of robot-aided locomotion, at varying speed and body weight support level.
Methods:
Non Negative Matrix Factorization was applied on surface electromyographic signals of 8 lower limb muscles of healthy subjects walking in gait robotic trainer at different walking velocities (1 to 3 km/h) and levels of body weight support (0 to 30%).
Results:
The muscular activity of volunteers could be described by low dimensionality (4 modules), as for overground walking. Moreover, the activation signals during robot-aided walking were bursts of activation timed at specific phases of the gait cycle, underlying an impulsive controller, as also observed in overground walking. This modular organization was consistent across the investigated speeds, body weight support level, and subjects.
Conclusions:
These results indicate that walking in a Lokomat robotic trainer is achieved by similar motor modules and activation signals as overground walking and thus supports the use of robotic training for re-establishing natural walking patterns.

Related Concept Videos
 01:11
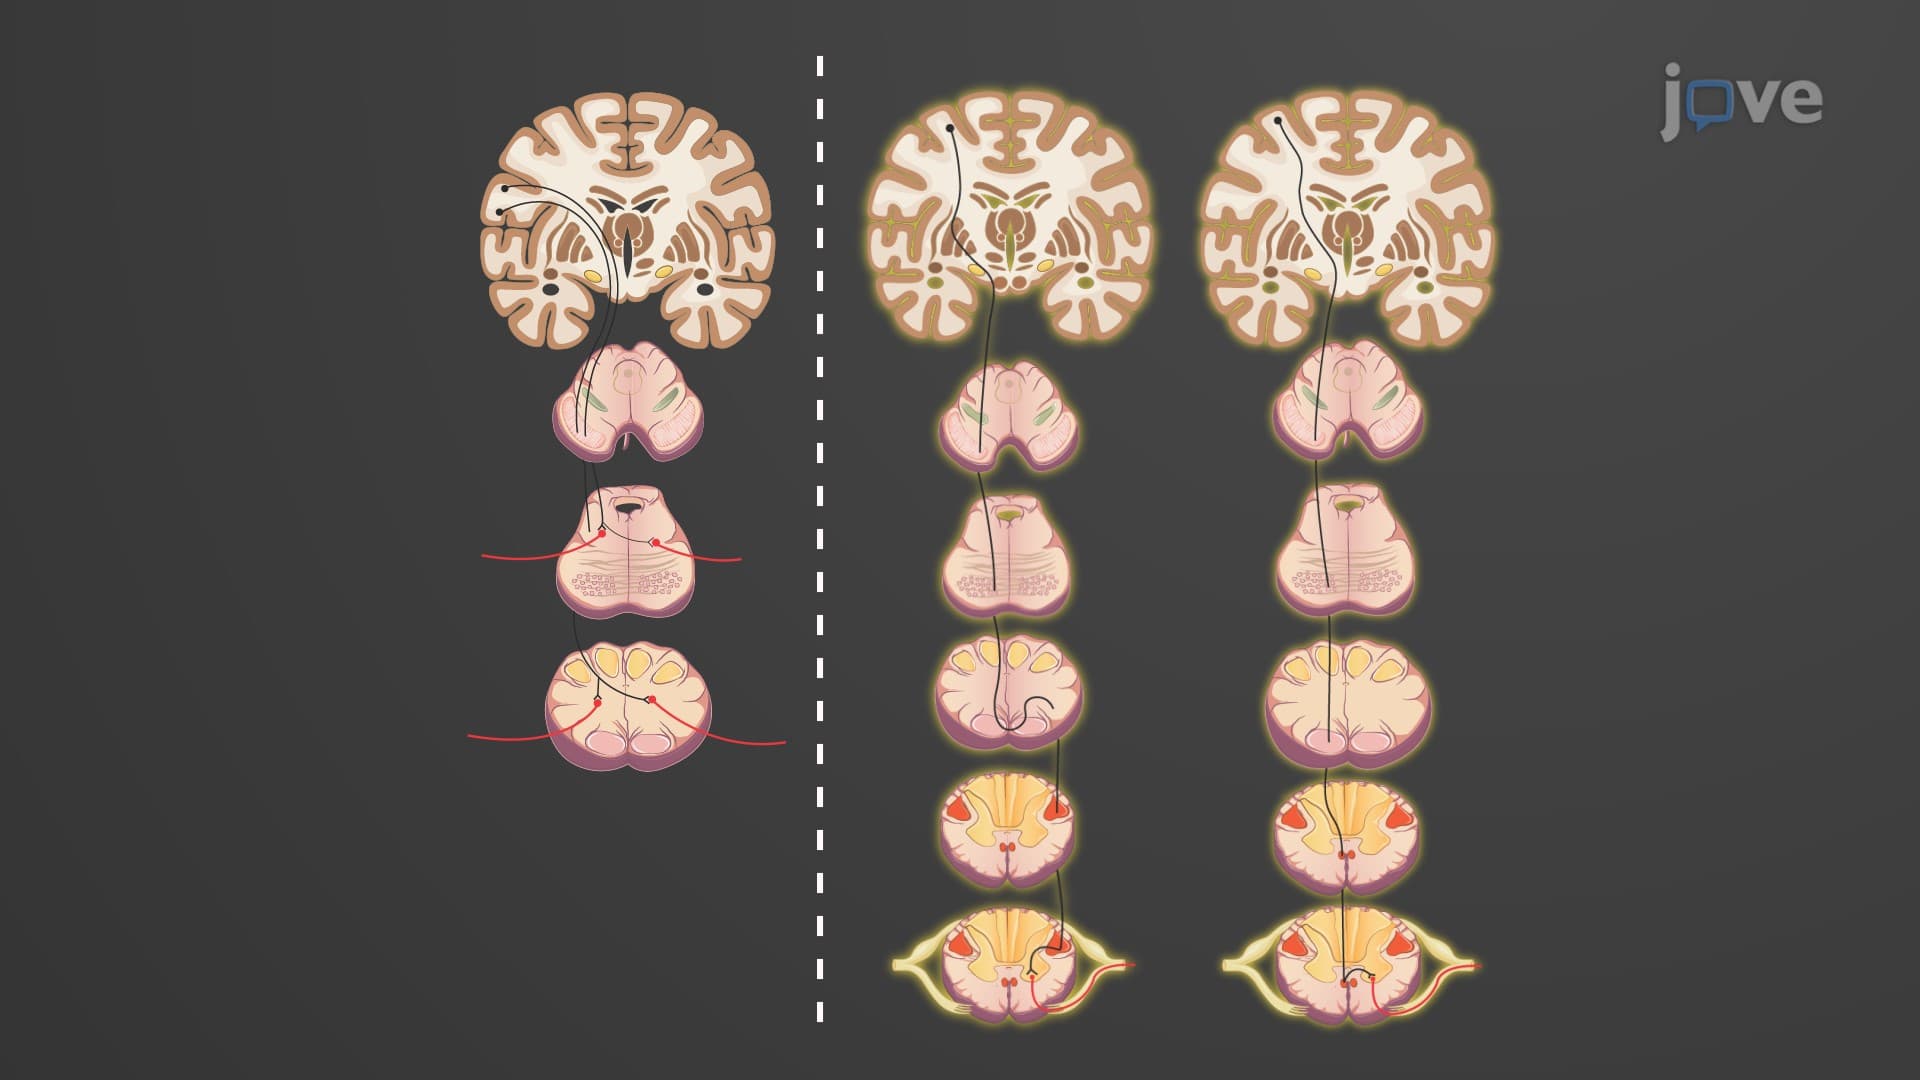
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 00:46
Motor Units
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...