Related Experiment Video
Updated: May 17, 2026


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Influence of the helical and six available Cardan sequences on 3D ankle joint kinematic parameters
J Sinclair1, P J Taylor, C J Edmundson
1School of Sport Exercise and Nutritional Sciences, University of Central Lancashire, Preston, UK. jsinclair1@uclan.ac.uk

Insights
The XYZ Cardan sequence minimizes planar crosstalk in 3D ankle joint kinematics during running. This recommended sequence provides more accurate angular motion calculations compared to other Cardan or helical methods.
Area of Science:
- Biomechanics
- Kinesiology
- Motion Analysis
Background:
- Cardan/Euler and helical angles quantify angular kinematics, but Cardan angles are sequence-dependent and prone to crosstalk.
- The International Society of Biomechanics (ISB) recommends an XYZ (sagittal, coronal, transverse) rotation sequence.
- Alternative sequences may be more appropriate for non-sagittal plane rotations.
Purpose of the Study:
- To investigate the influence of helical and six Cardan sequences on 3D ankle joint kinematics.
- To compare kinematic parameters and identify planar crosstalk across different rotation sequences.
Main Methods:
- Obtained 3D ankle kinematic data from participants running at 4.0 m/s using an eight-camera motion analysis system.
- Utilized repeated measures ANOVAs to compare kinematic parameters.
- Employed intraclass correlations to assess planar crosstalk.
Main Results:
- The YXZ and ZXY Cardan sequences yielded significantly greater peak angle and range of motion values in the transverse and coronal planes.
- YXZ and ZXY sequences showed the strongest correlations with sagittal plane rotations.
- The XYZ sequence exhibited the lowest degree of planar crosstalk.
Conclusions:
- The XYZ sequence is associated with minimal planar crosstalk for 3D ankle joint kinematics.
- The XYZ sequence is recommended for accurate representation of ankle joint motion during activities like running.
Abstract:
Cardan/Euler and helical angles are the popular methods of quantifying angular kinematics. Cardan angles are sequence dependent and crosstalk can influence the kinematic calculations. The International Society of Biomechanics (ISB) recommends a sagittal, coronal, and then transverse (XYZ) sequence of rotations, although it has been proposed that when calculating rotations outside of the sagittal plane, this may not be the most appropriate method. This study investigated the influence of the helical and six available Cardan sequences on three-dimensional (3D) ankle joint kinematics. Kinematic data were obtained using an eight-camera motion analysis system as participants ran at 4.0 m/s +/- 5%. Repeated measures ANOVAs were used to compare kinematic parameters, and intraclass correlations were employed to identify evidence of crosstalk across planes. The results indicate that in the transverse and coronal planes, peak angle and range of motion values using the YXZ and ZXY sequences were significantly greater than the other sequences. Furthermore, utilization of YXZ and ZXY sequences was associated with the strongest correlations from the sagittal plane, and the XYZ sequence was found to be associated with the lowest correlations. It appears that for the representation of 3D ankle joint kinematics, the XYZ sequence is associated with minimal planar crosstalk and as such its use is encouraged.

Related Concept Videos
 01:10
Ankle Joint
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:09
Functional Classification of Joints
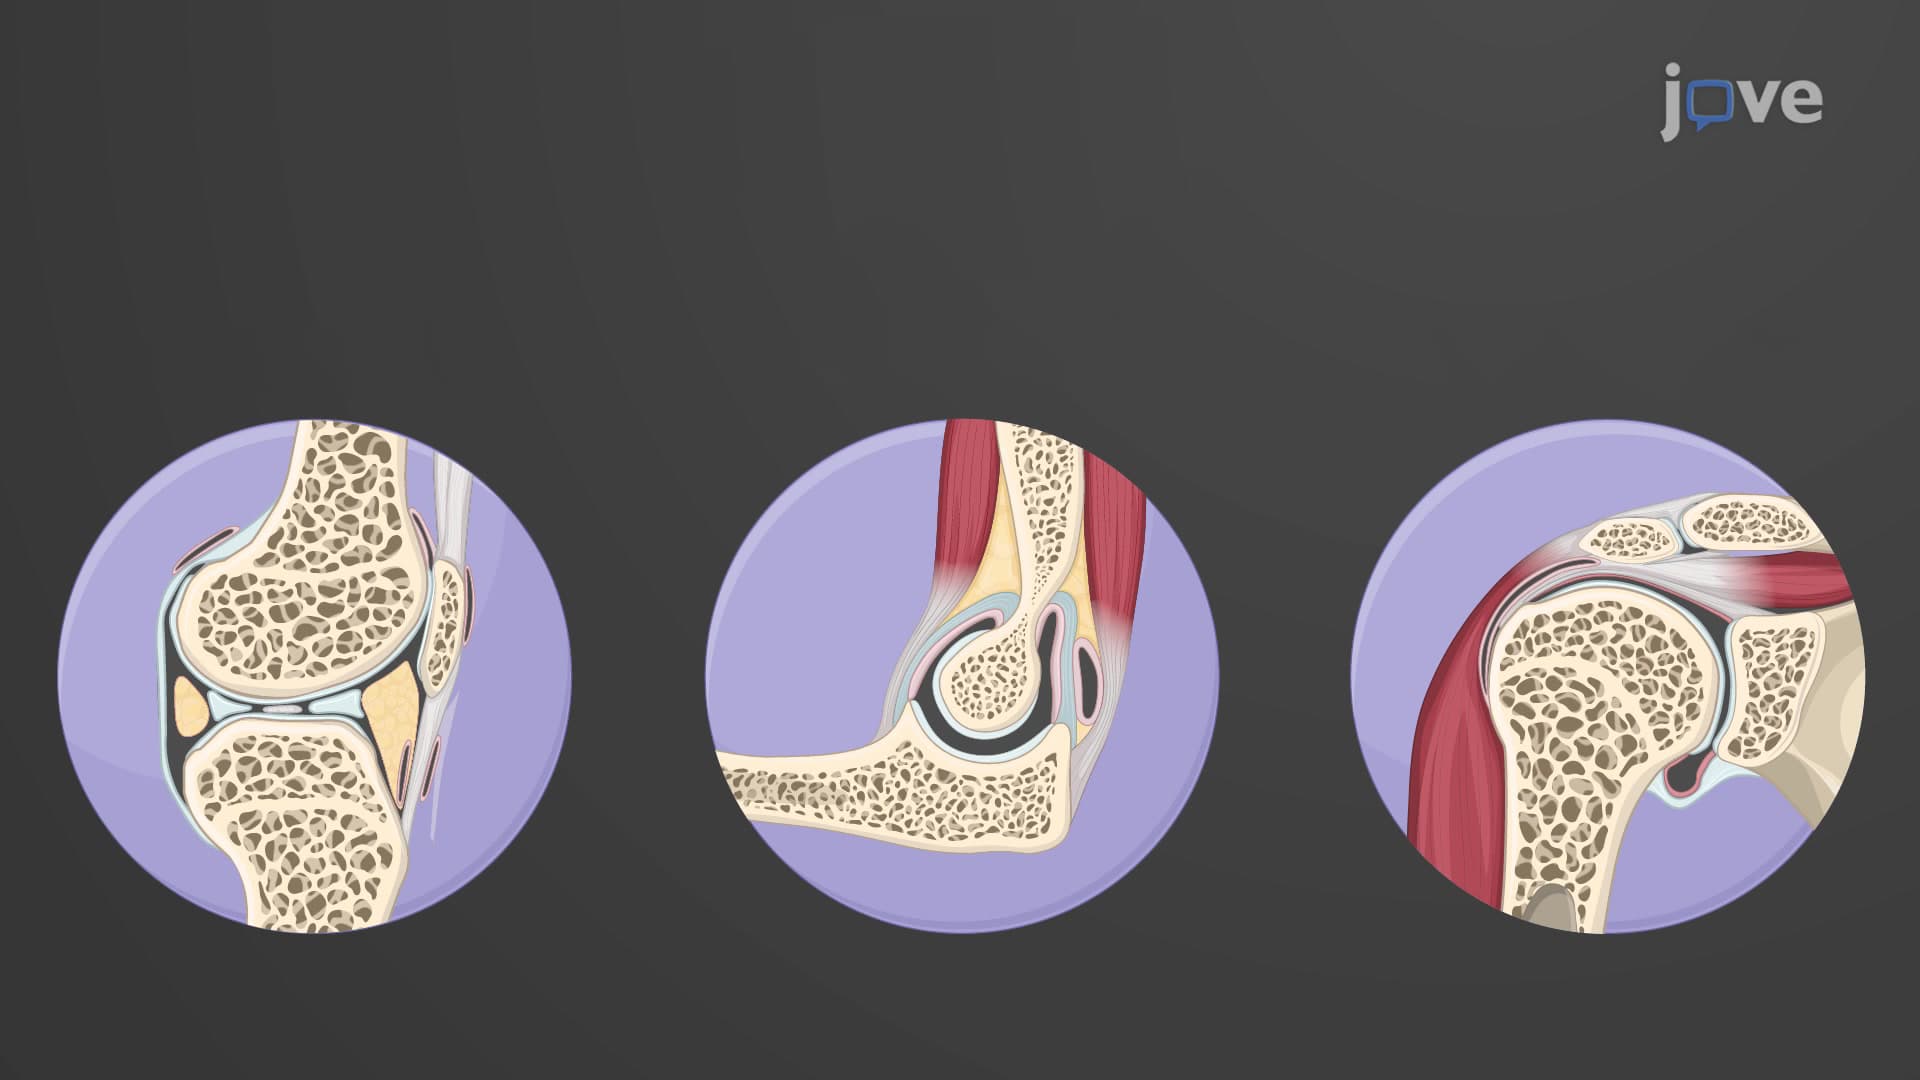
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An immobile...