Related Experiment Video
Updated: May 17, 2026

Inherent Dynamics Visualizer, an Interactive Application for Evaluating and Visualizing Outputs from a Gene Regulatory Network Inference Pipeline
Published on: December 7, 2021
Fitting Boolean networks from steady state perturbation data
Anthony Almudevar1, Matthew N McCall, Helene McMurray
1University of Rochester, USA.

Abstract:
Gene perturbation experiments are commonly used for the reconstruction of gene regulatory networks. Typical experimental methodology imposes persistent changes on the network. The resulting data must therefore be interpreted as a steady state from an altered gene regulatory network, rather than a direct observation of the original network. In this article an implicit modeling methodology is proposed in which the unperturbed network of interest is scored by first modeling the persistent perturbation, then predicting the steady state, which may then be compared to the observed data. This results in a many-to-one inverse problem, so a computational Bayesian approach is used to assess model uncertainty. The methodology is first demonstrated on a number of synthetic networks. It is shown that the Bayesian approach correctly assigns high posterior probability to the network structure and steady state behavior. Further, it is demonstrated that where uncertainty of model features is indicated, the uncertainty may be accurately resolved with further perturbation experiments. The methodology is then applied to the modeling of a gene regulatory network using perturbation data from nine genes which have been shown to respond synergistically to known oncogenic mutations. A hypothetical model emerges which conforms to reported regulatory properties of these genes. Furthermore, the Bayesian methodology is shown to be consistent in the sense that multiple randomized applications of the fitting algorithm converge to an approximately common posterior density on the space of models. Such consistency is generally not feasible for algorithms which report only single models. We conclude that fully Bayesian methods, coupled with models which accurately account for experimental constraints, are a suitable tool for the inference of gene regulatory networks, in terms of accuracy, estimation of model uncertainty, and experimental design.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state response.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
State Space to Transfer Function
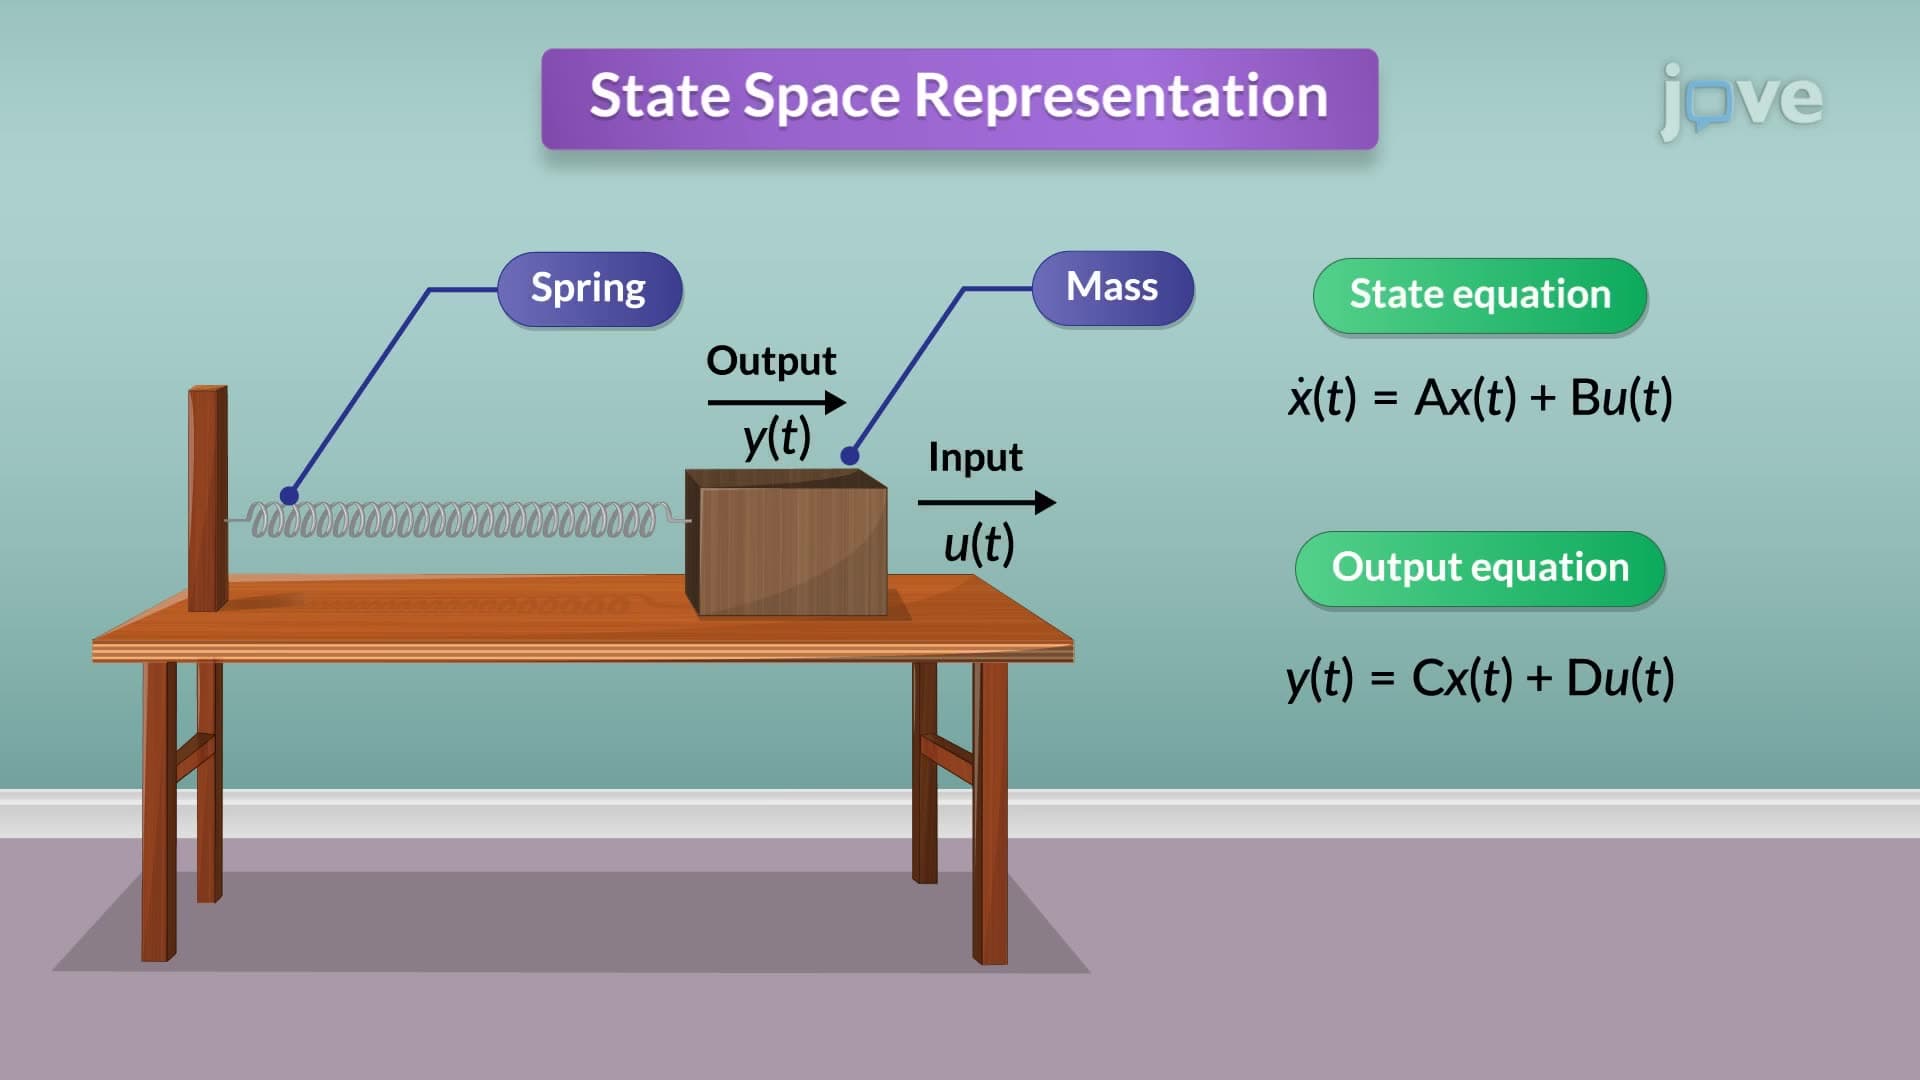
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:25
Modeling with Differential Equations