Transfer of object category knowledge across visual and haptic modalities: experimental and computational studies
Related Experiment Video
Updated: May 17, 2026
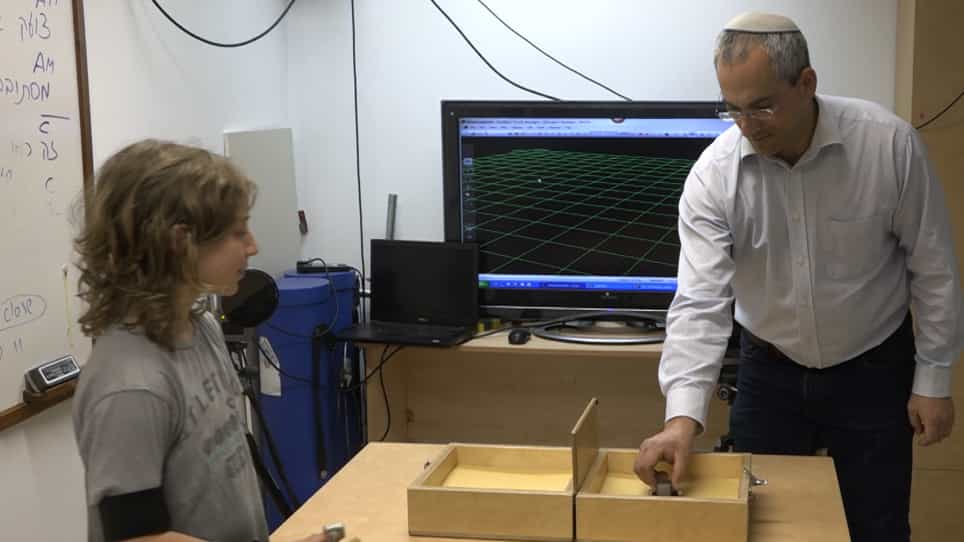
Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Ilker Yildirim1, Robert A Jacobs
1Department of Brain and Cognitive Sciences, University of Rochester, Rochester, NY 14627, United States. iyildirim@bcs.rochester.edu

Abstract:
We study people's abilities to transfer object category knowledge across visual and haptic domains. If a person learns to categorize objects based on inputs from one sensory modality, can the person categorize these same objects when the objects are perceived through another modality? Can the person categorize novel objects from the same categories when these objects are, again, perceived through another modality? Our work makes three contributions. First, by fabricating Fribbles (3-D, multi-part objects with a categorical structure), we developed visual-haptic stimuli that are highly complex and realistic, and thus more ecologically valid than objects that are typically used in haptic or visual-haptic experiments. Based on these stimuli, we developed the See and Grasp data set, a data set containing both visual and haptic features of the Fribbles, and are making this data set freely available on the world wide web. Second, complementary to previous research such as studies asking if people transfer knowledge of object identity across visual and haptic domains, we conducted an experiment evaluating whether people transfer object category knowledge across these domains. Our data clearly indicate that we do. Third, we developed a computational model that learns multisensory representations of prototypical 3-D shape. Similar to previous work, the model uses shape primitives to represent parts, and spatial relations among primitives to represent multi-part objects. However, it is distinct in its use of a Bayesian inference algorithm allowing it to acquire multisensory representations, and sensory-specific forward models allowing it to predict visual or haptic features from multisensory representations. The model provides an excellent qualitative account of our experimental data, thereby illustrating the potential importance of multisensory representations and sensory-specific forward models to multisensory perception.

Related Concept Videos
 01:15
Sensory Modalities
General senses refer to the broad category of sensory information detected by receptors in the body and can be further grouped into somatic and visceral senses. Somatic sensations include touch, pressure, temperature, and pain and are essential for navigating our environment and...
 01:11
Sensory Perception: Organization of the Somatosensory System
The receptor level:
The receptor level is the first stage of sensation. It involves the detection of a stimulus by specialized sensory receptors. The stimulus must arrive within the receptor's receptive field. Next, the receptor converts the energy of the stimulus...
 01:33
Somatosensation
 01:26
Introduction to Special Senses
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:14
Motor and Sensory Areas of the Cortex
Motor Areas
The motor areas located in the frontal lobe are central to controlling voluntary movements. This region is further subdivided into the primary motor cortex and the premotor cortex.