Related Experiment Video
Updated: May 16, 2026


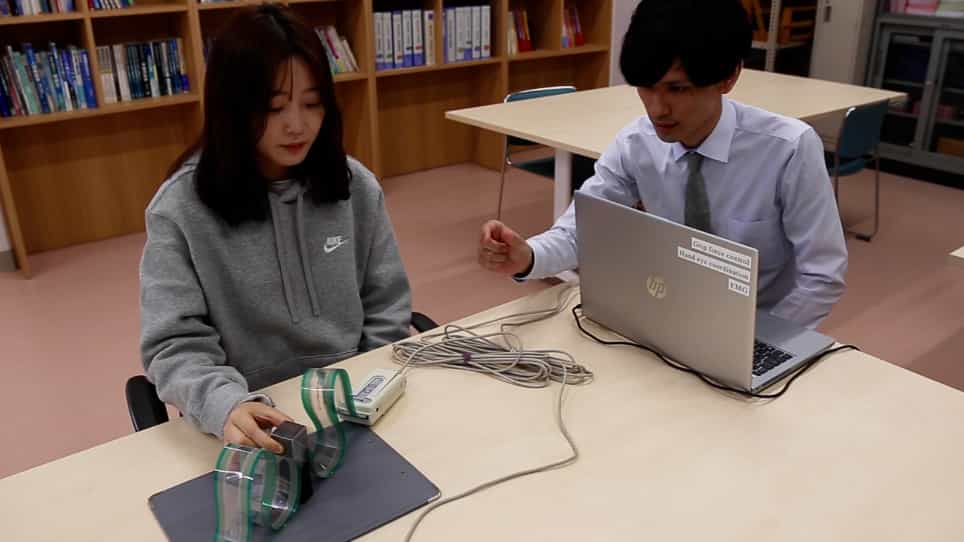
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Bimanual interference associated with handling different tool transformations
Cristina Massen1, Christine Sattler
1Leibniz Research Centre for Working Environment and Human Factors, Ardeystrasse 67, Dortmund, Germany. massen@ifado.de.

Abstract:
Research on bimanual coordination of hand movements has identified several loci of bimanual interference, including interference because of programming different movement parameters or selecting different targets for the two hands. This study investigates the extent and origin of interference when participants execute bimanual actions with tools. In the experiments, participants moved two tools, one with each hand, to two directly cued target locations. One type of tool transformed the body movement into a spatially compatible movement of the effective part of the tool, whereas the other transformed it into a spatially incompatible movement. Tool transformations for the two hands were either the same or different. Furthermore, target locations were either in the same or in different spatial directions. Results indicated significantly shorter reaction times (RTs) and less errors when tool transformations were the same for both hands. In addition, movements were initiated more quickly and less error-prone when targets were in the same direction, but this effect was modulated by the congruency of the two lever transformations. Investigations of the time course of the effects revealed that they were not because of early perceptual processing (Experiment 2). Furthermore, the general pattern of results occurred for different grip positions (Experiment 3) and different lever types (Experiment 4), suggesting that it reflects rather general constraints in bimanual coordination of tool-use actions.

Related Concept Videos
 01:19
Machines
A free-body diagram of the...
 01:23
Simplification of a Force and Couple System: II
 01:23
Unsymmetric Loading of Thin-Walled Members
The concept of the shear center is crucial in countering the...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:18
Unsymmetric Bending
 01:13
Angle of Twist: Problem Solving