Modeling the frictional interaction in the tendon-pulley system of the human finger for use in robotics
Related Experiment Video
Updated: May 16, 2026

A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
Konstantinos Dermitzakis1, Marco Roberto Morales, Andreas Schweizer
1University of Zurich. dermitza@ifi.uzh.ch

Abstract:
Physiological studies of the human finger indicate that friction in the tendon-pulley system accounts for a considerable fraction of the total output force (9-12%) in a high-load static posteccentric configuration. Such a phenomenon can be exploited for robotic and prosthetic applications, as it can result in (1) an increase of output force or (2) a reduction of energy consumption and actuator weight. In this study, a simple frictional, two-link, one-degree-of-freedom model of a human finger was created. The model is validated against in vitro human finger data, and its behavior is examined with respect to select physiological parameters. The results point to clear benefits of incorporating friction in tendon-driven robotic fingers for actuator mass and output force. If it is indeed the case that the majority of high-load hand grasps are posteccentric, there is a clear benefit of incorporating friction in tendon-driven prosthetic hand replacements.
Related Concept Videos
 01:05
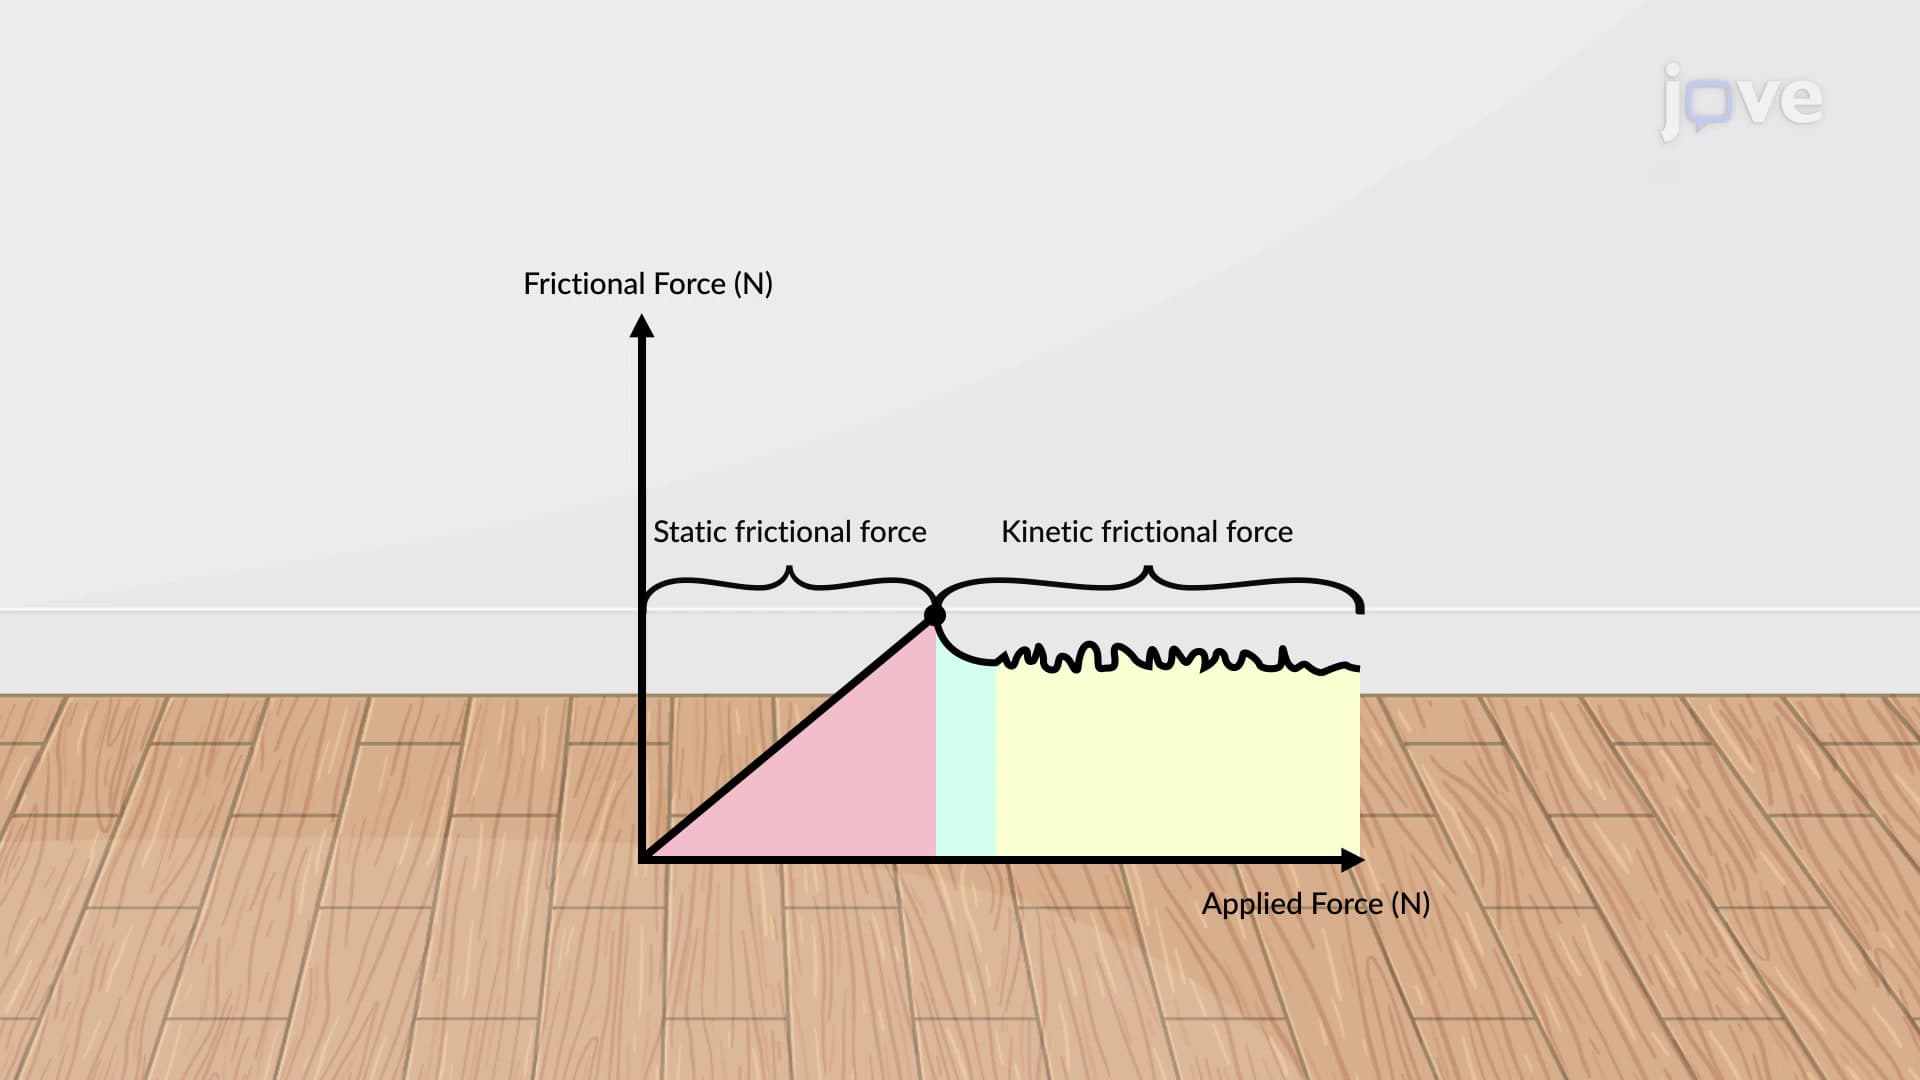
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:23
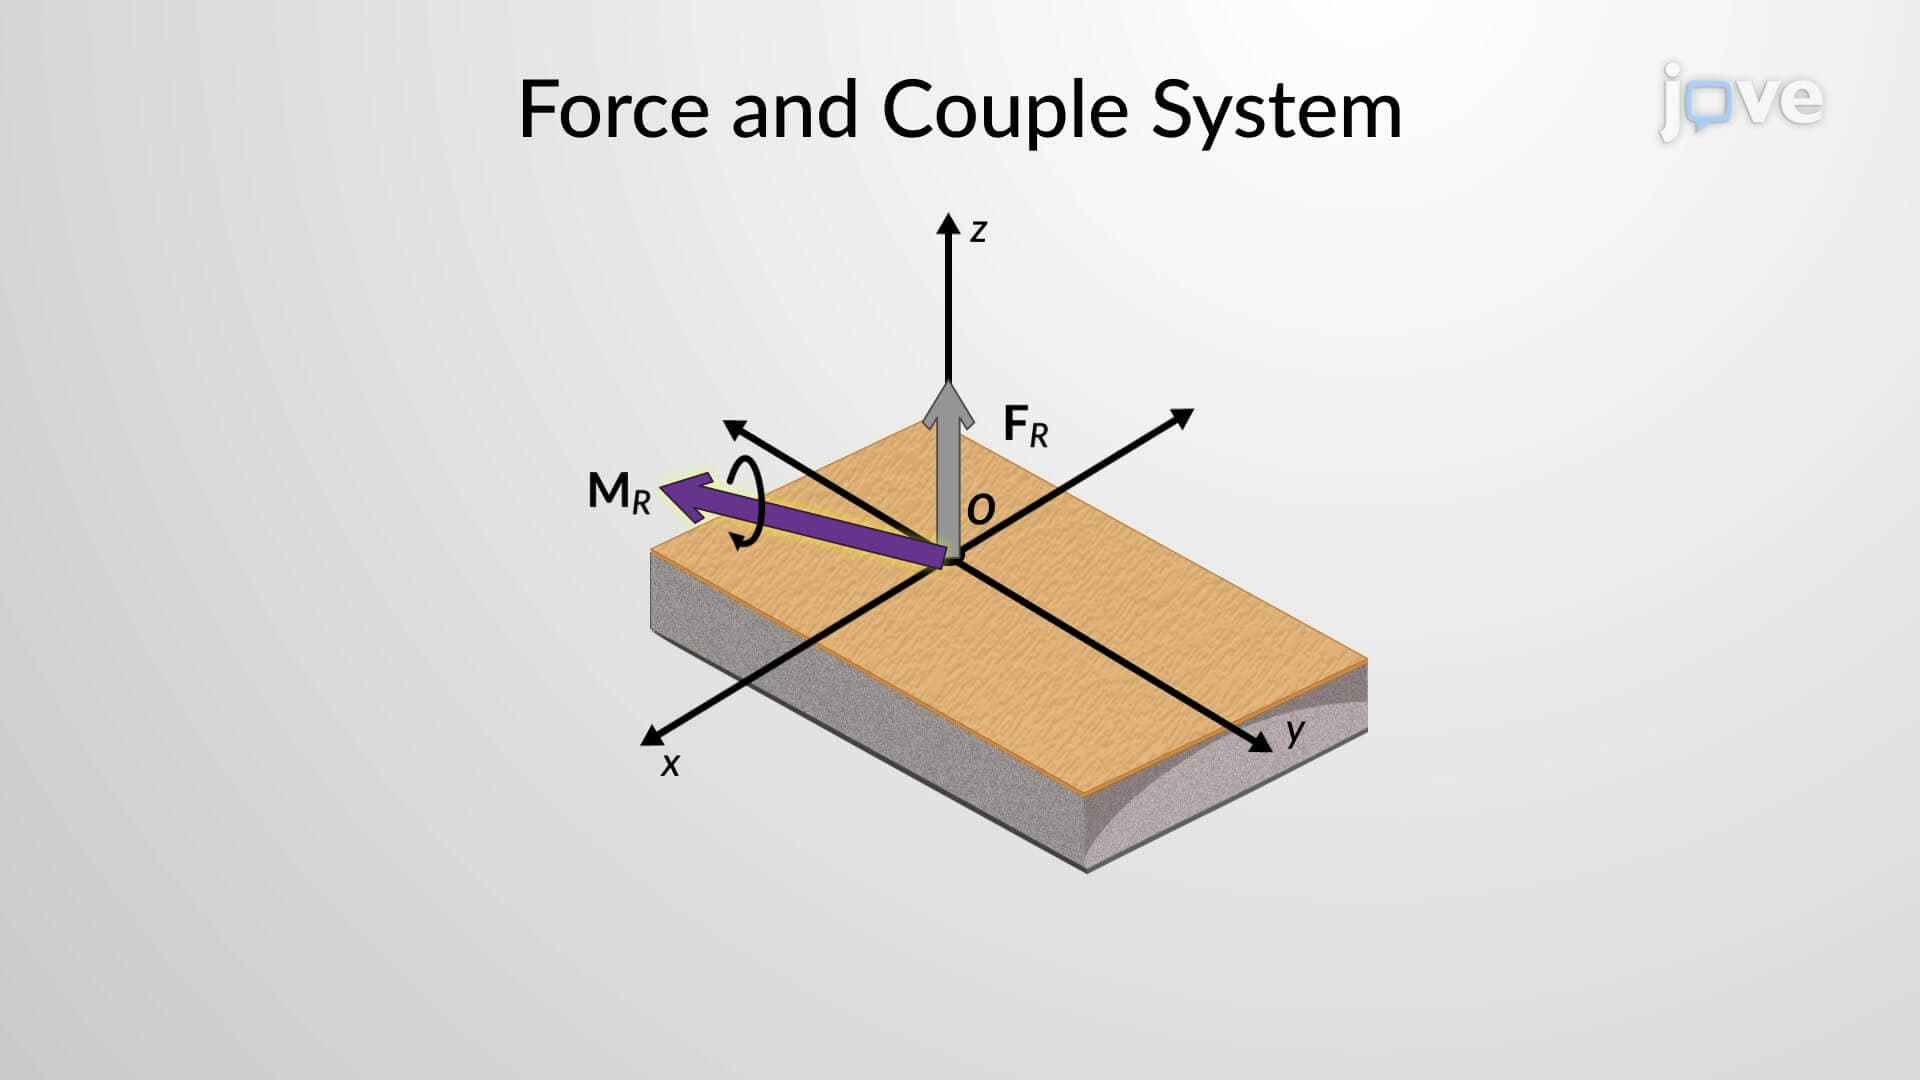
Simplification of a Force and Couple System: II
 01:28
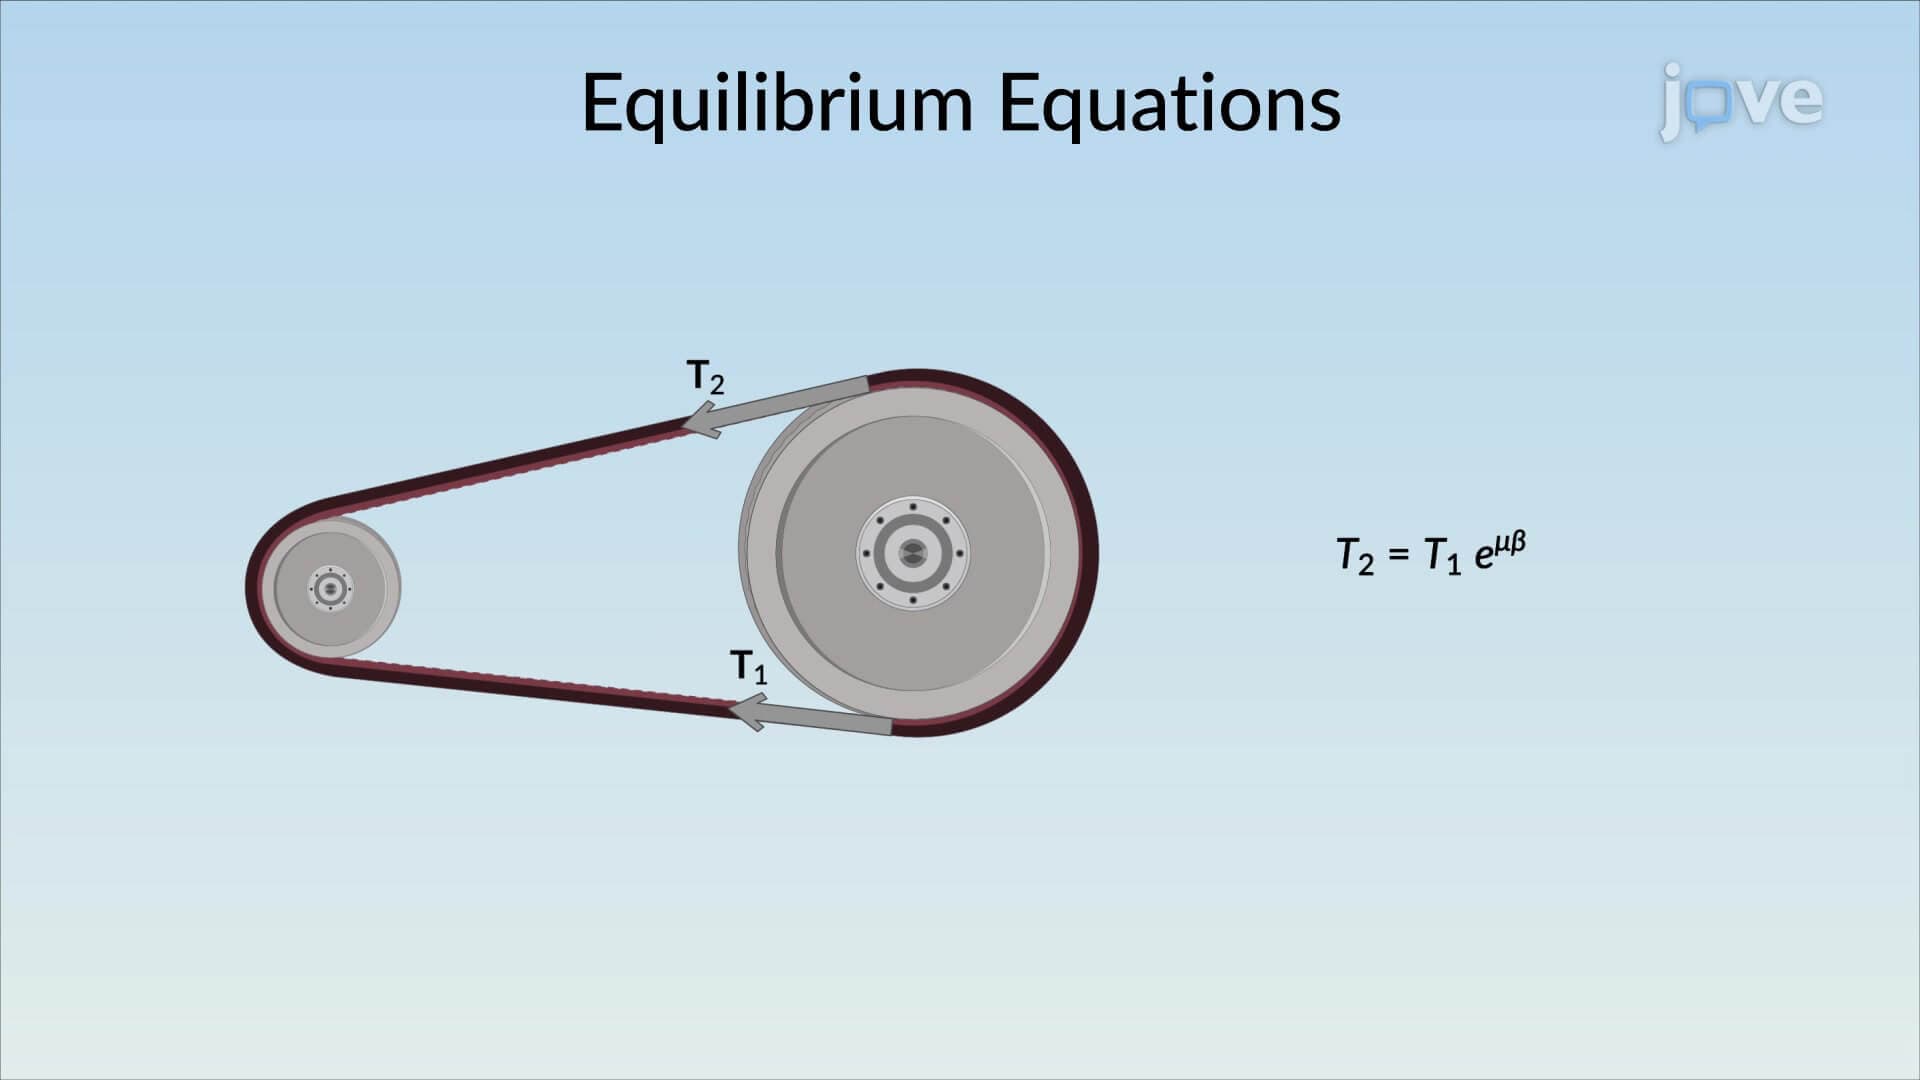
Frictional Forces on Flat Belts
 01:26
Kinetic Friction
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...