Related Experiment Video
Updated: May 15, 2026
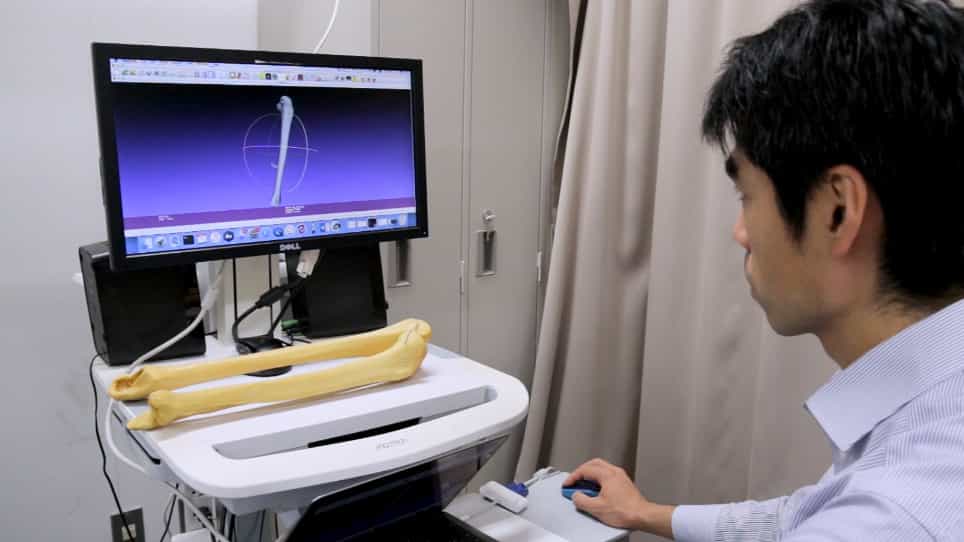

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Principal direction of inertia for 3D trajectories from patient-specific TMJ movement
Dae-Seung Kim1, Soon-Chul Choi, Sam-Sun Lee
1Interdisciplinary Program in Radiation Applied Life Science Major, College of Medicine, BK21, and Dental Research Institute, Seoul National University, South Korea.

Abstract:
Accurate simulation and evaluation of mandibular movement is fundamental for the analysis of functional changes and effects of the mandible and maxilla before and after surgical treatments. We applied principal axes of inertia to the three-dimensional (3D) trajectories generated by patient-specific simulations of TMJ movements for the functional evaluations of mandible movement. Three-dimensional movements of the mandible and the maxilla were tracked based on a patient-specific splint and an optical tracking system. The dental occlusion recorded on the sprint provided synchronization for initial movement in the tracking and the simulation phases. The translation and rotation recorded during movement tracking was applied sequentially to the mandibular model in relation to a fixed maxilla model. The sequential 3D positions of selected landmarks on the mandible were calculated based on the reference coordinate system. The landmarks selected for analysis were bilateral condyles and pogonion points. The moment of inertia tensor was calculated with respect to the 3D trajectory points. Using the unit vectors along the principal axes derived from the tensor matrix, α, β and γ rotations around z-, y- and x-axes were determined to represent the principal directions as principal rotations respectively. The γ direction showed the higher standard deviation, variation of directions, than other directions at all the landmarks. The mandible movement has larger kinematic redundancy in the γ direction than α and β during mouth opening and closing. Principal directions of inertia would be applied to analyzing the changes in angular motion of trajectories introduced by mandibular shape changes from surgical treatments and also to the analysis of the influence of skeletal deformities on mandibular movement asymmetry.
More Related Videos
Related Concept Videos
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:15
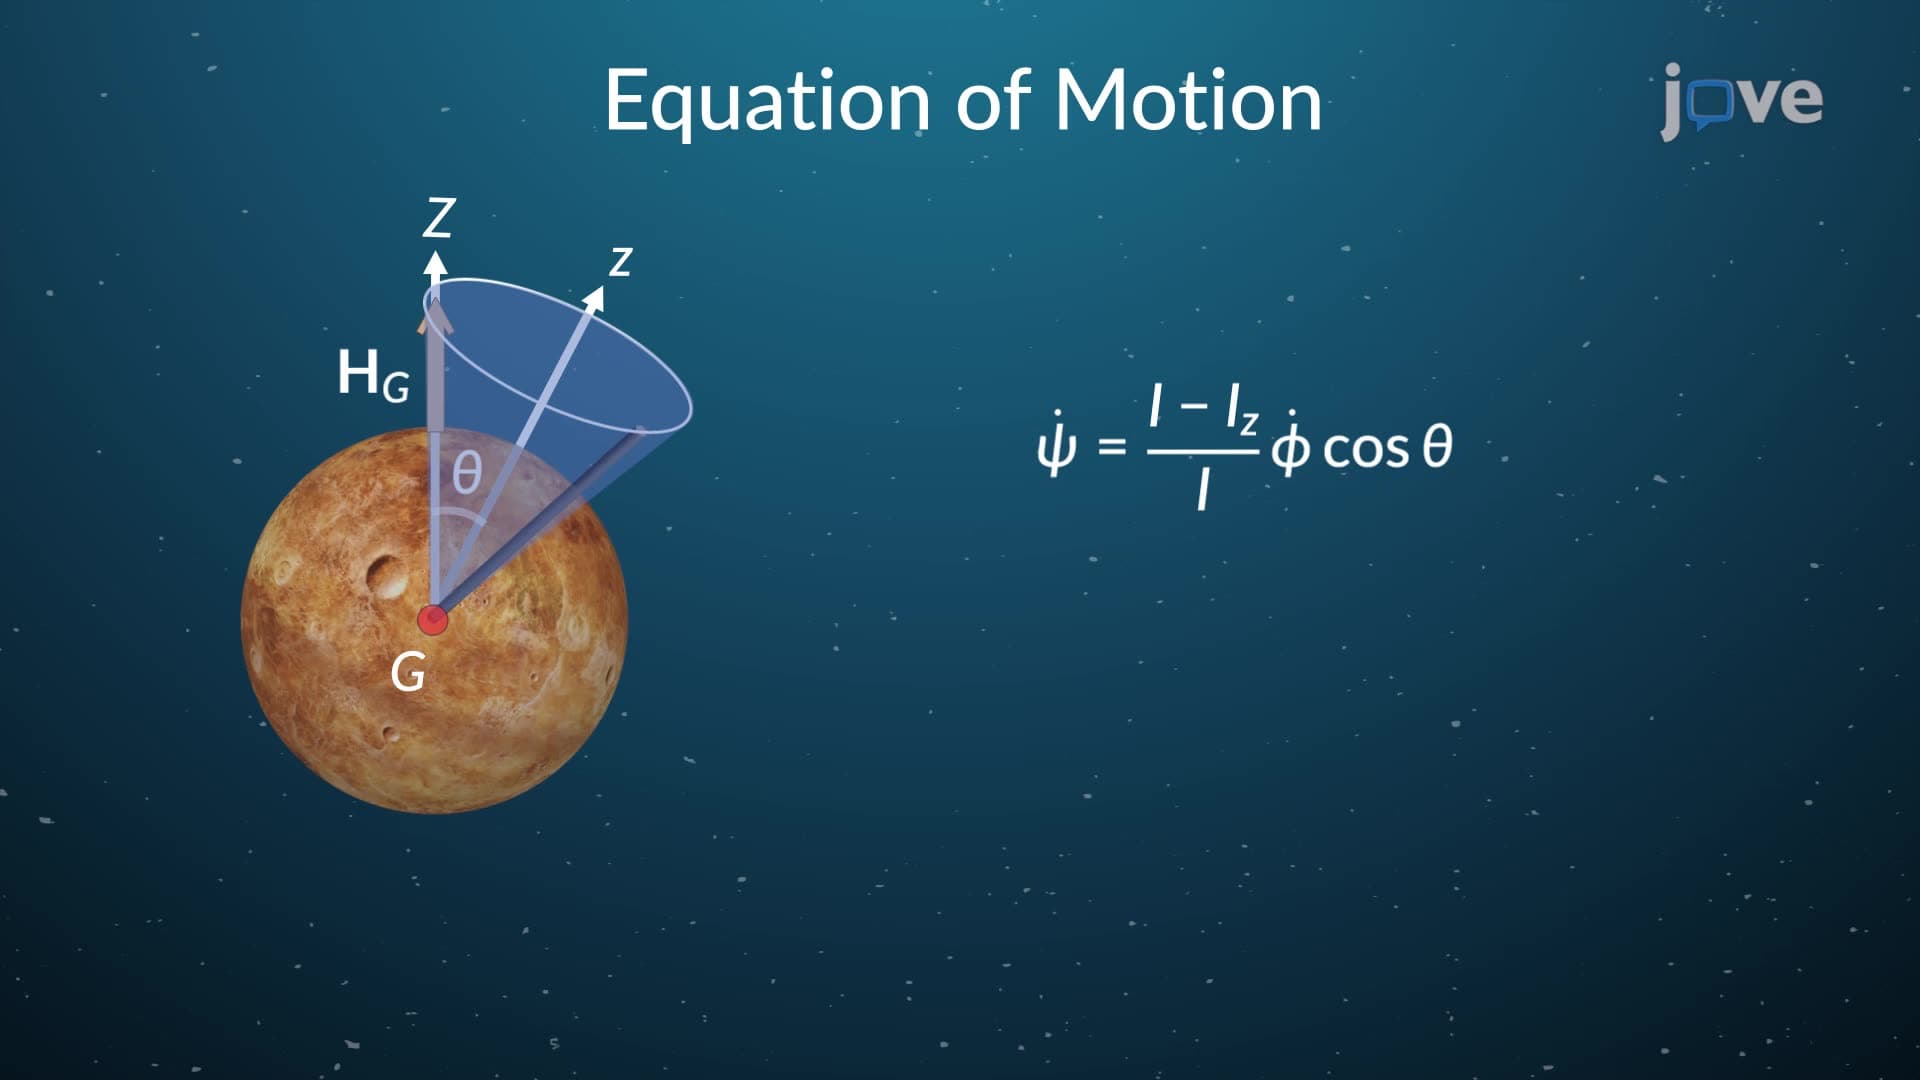
Torque Free Motion
 01:11
Angular Momentum about an Arbitrary Axis
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into the angular...
 01:15
Principle of Impulse and Moment
 01:26
Orthogonal Trajectories