Related Experiment Video
Updated: May 14, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Influence of center of pressure estimation errors on 3D inverse dynamics solutions during gait at different
Franklin Camargo-Junior1, Marko Ackermann, Jefferson F Loss
1Department of Physical Therapy, Speech and Occupational Therapy, School of Medicine, University of São Paulo, São Paulo, Brazil.

Abstract:
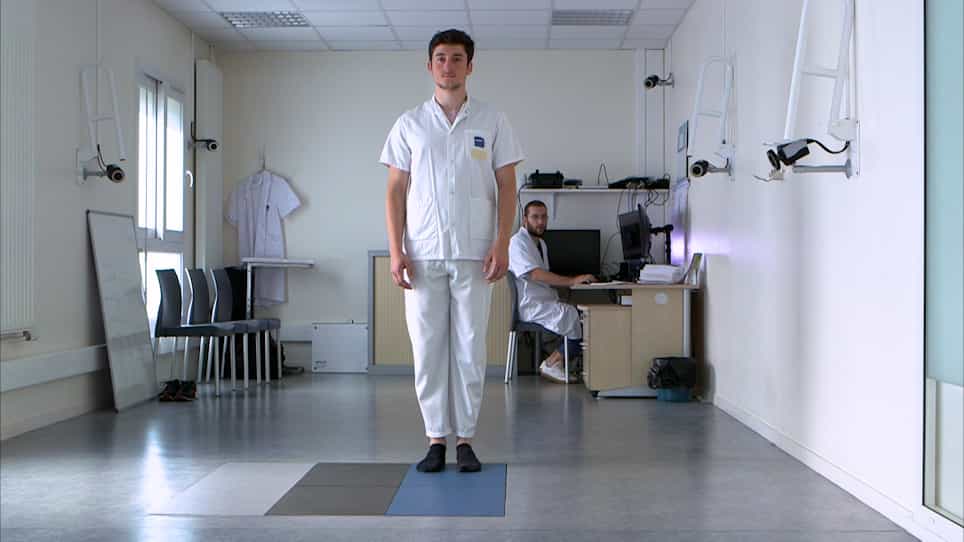
The aim of this study was to investigate the effect of errors in the location of the center of pressure (5 and 10 mm) on lower limb joint moment uncertainties at different gait velocities (1.0, 1.5, and 2.0 m/s). Our hypotheses were that the absolute joint moment uncertainties would be gradually reduced from distal to proximal joints and from higher to lower velocities. Joint moments of five healthy young adults were calculated by inverse dynamics using the bottom-up approach, depending on which estimate the uncertainty propagated. Results indicated that there is a linear relationship between errors in center of pressure and joint moment uncertainties. The absolute moment peak uncertainties expressed on the anatomic reference frames decreased from distal to proximal joints, confirming our first hypothesis, except for the abduction moments. There was an increase in moment uncertainty (up to 0.04 N m/kg for the 10 mm error in the center of pressure) from the lower to higher gait velocity, confirming our second hypothesis, although, once again, not for hip or knee abduction. Finally, depending on the plane of movement and the joint, relative uncertainties experienced variation (between 5 and 31%), and the knee joint moments were the most affected.

Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
Kinematic Equations: Problem Solving
 01:26
Kinematic Equations - I
 01:14
Equation of Motion: Center of Mass
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...