Related Experiment Video
Updated: May 14, 2026
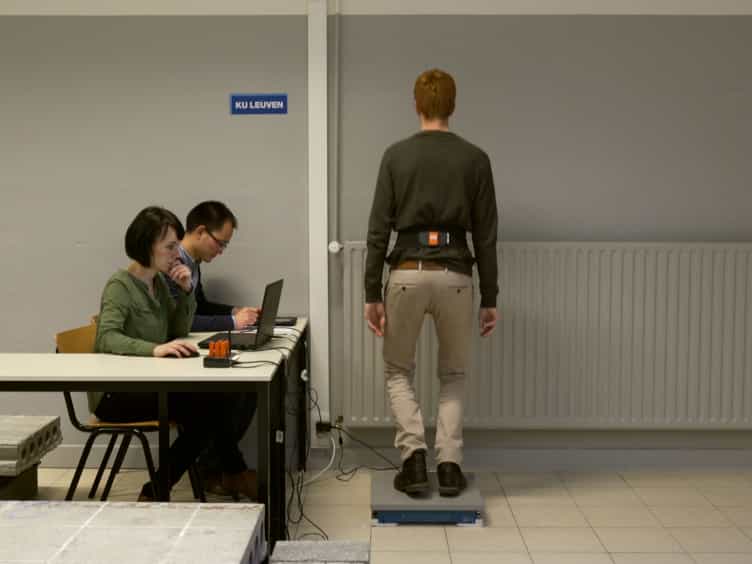
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Deciphering the crowd: modeling and identification of pedestrian group motion
Zeynep Yücel1, Francesco Zanlungo, Tetsushi Ikeda
1Intelligent Robotics and Communication Laboratories, Advanced Telecommunications Research Institute International, Kyoto 619-0288, Japan. zeynep@atr.jp

Abstract:
Associating attributes to pedestrians in a crowd is relevant for various areas like surveillance, customer profiling and service providing. The attributes of interest greatly depend on the application domain and might involve such social relations as friends or family as well as the hierarchy of the group including the leader or subordinates. Nevertheless, the complex social setting inherently complicates this task. We attack this problem by exploiting the small group structures in the crowd. The relations among individuals and their peers within a social group are reliable indicators of social attributes. To that end, this paper identifies social groups based on explicit motion models integrated through a hypothesis testing scheme. We develop two models relating positional and directional relations. A pair of pedestrians is identified as belonging to the same group or not by utilizing the two models in parallel, which defines a compound hypothesis testing scheme. By testing the proposed approach on three datasets with different environmental properties and group characteristics, it is demonstrated that we achieve an identification accuracy of 87% to 99%. The contribution of this study lies in its definition of positional and directional relation models, its description of compound evaluations, and the resolution of ambiguities with our proposed uncertainty measure based on the local and global indicators of group relation.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:15
Kinematic Equations: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...