Related Experiment Video
Updated: May 14, 2026


Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Separate contributions of kinematic and kinetic errors to trajectory and grip force adaptation when transporting
Frederic Danion1, Jonathan S Diamond, J Randall Flanagan
1Institut de Neurosciences de la Timone, UMR 7289, CNRS and Aix-Marseille University, 13 385 Marseille cedex 5, France.

Abstract:
Numerous studies of motor learning have examined the adaptation of hand trajectories and grip forces when moving grasped objects with novel dynamics. Such objects initially result in both kinematic and kinetic errors; i.e., mismatches between predicted and actual trajectories and between predicted and actual load forces. Here we investigated the contribution of these errors to both trajectory and grip force adaptation. Participants grasped an object with novel dynamics using a precision grip and moved it between two targets. Kinematic errors could be effectively removed using a force channel to constrain hand motion to a straight line. When moving in the channel, participants learned to modulate grip force in synchrony with load force and this learning generalized when movement speed in the channel was doubled. When the channel was removed, these participants continued to effectively modulate grip force but exhibited substantial kinematic errors, equivalent to those seen in participants who did not previously experience the object in the channel. We also found that the rate of grip force adaptation did not depend on whether the object was initially moved with or without a channel. These results indicate that kinematic errors are necessary for trajectory but not grip force adaptation, and that kinetic errors are sufficient for grip force but not trajectory adaptation. Thus, participants can learn a component of the object's dynamics, used to control grip force, based solely on kinetic errors. However, this knowledge is apparently not accessible or usable for controlling the movement trajectory when the channel is removed.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:10
Relative Motion Analysis - Acceleration
 01:05
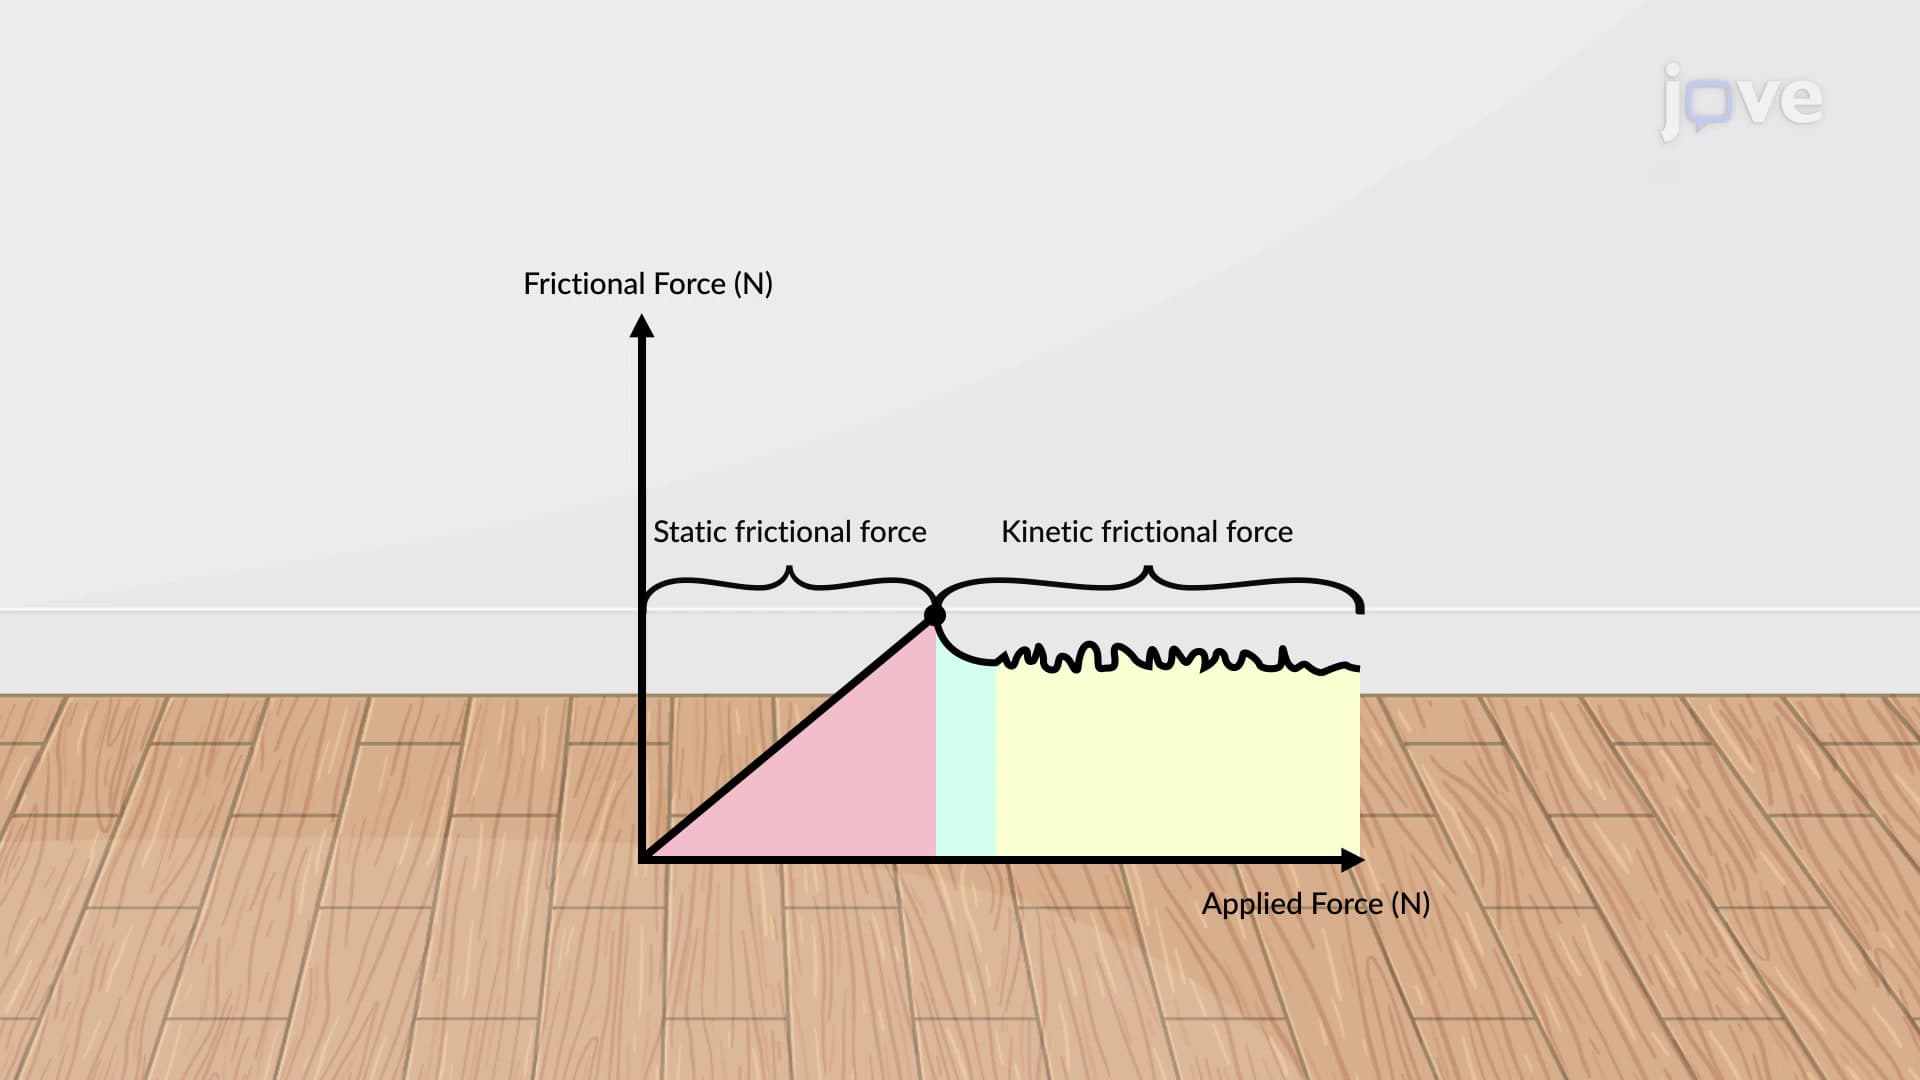
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Kinematic Equations - I