Related Experiment Video
Updated: May 14, 2026
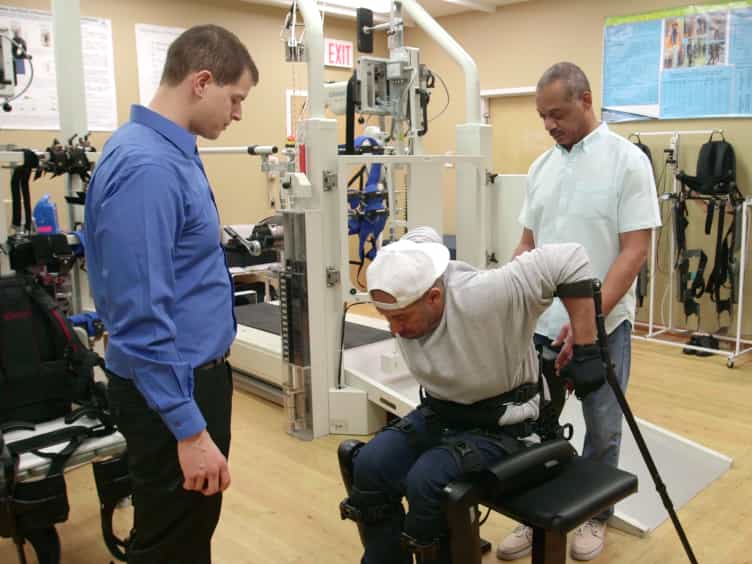

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Reducing muscle effort in walking through powered exoskeletons

Abstract:
This paper presents a novel assistive control for lower limb exoskeletons. The controller provides the user with a scaled version of the Winter's nominal torque profile, which is adapted online to the specific gait features of the user. The proposed assistive controller is implemented on the ALEX II exoskeleton and tested on two healthy subjects. Experimental results show that when assisted by the exoskeleton users can reduce the muscle effort compared to free walking.
More Related Videos
 06:00
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 07:30
The Muscle Cuff Regenerative Peripheral Nerve Interface for the Amplification of Intact Peripheral Nerve Signals
Published on: January 13, 2022