Related Experiment Video
Updated: May 14, 2026
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
A stability-based mechanism for hysteresis in the walk-trot transition in quadruped locomotion
Shinya Aoi1, Daiki Katayama, Soichiro Fujiki
1Department of Aeronautics and Astronautics, Graduate School of Engineering, Kyoto University, Yoshida-honmachi, Sakyo-ku, Kyoto 6068501, Japan. shinya_aoi@kuaero.kyoto-u.ac.jp

Abstract:
Quadrupeds vary their gaits in accordance with their locomotion speed. Such gait transitions exhibit hysteresis. However, the underlying mechanism for this hysteresis remains largely unclear. It has been suggested that gaits correspond to attractors in their dynamics and that gait transitions are non-equilibrium phase transitions that are accompanied by a loss in stability. In the present study, we used a robotic platform to investigate the dynamic stability of gaits and to clarify the hysteresis mechanism in the walk-trot transition of quadrupeds. Specifically, we used a quadruped robot as the body mechanical model and an oscillator network for the nervous system model to emulate dynamic locomotion of a quadruped. Experiments using this robot revealed that dynamic interactions among the robot mechanical system, the oscillator network, and the environment generate walk and trot gaits depending on the locomotion speed. In addition, a walk-trot transition that exhibited hysteresis was observed when the locomotion speed was changed. We evaluated the gait changes of the robot by measuring the locomotion of dogs. Furthermore, we investigated the stability structure during the gait transition of the robot by constructing a potential function from the return map of the relative phase of the legs and clarified the physical characteristics inherent to the gait transition in terms of the dynamics.
Related Concept Videos
 01:28
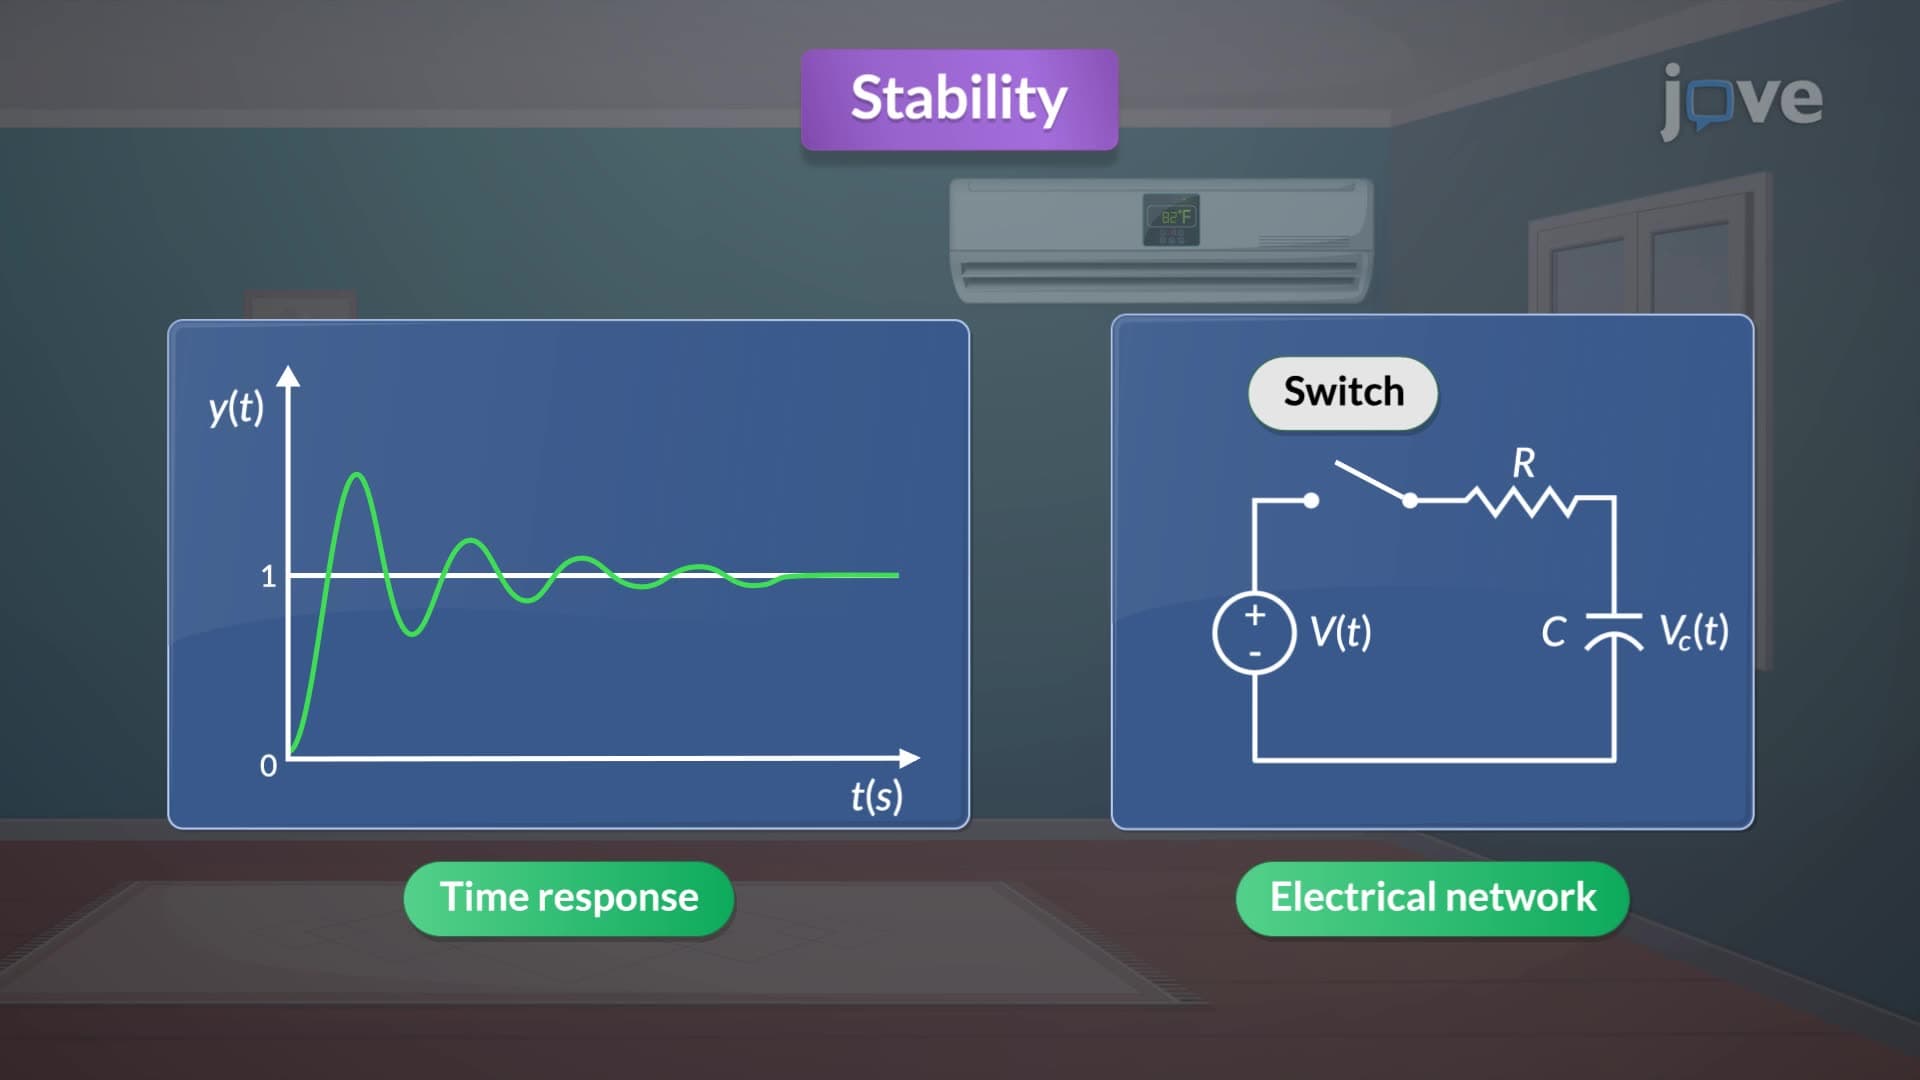
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:14
Stability of structures
 01:04
Oscillations about an Equilibrium Position
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...