Related Experiment Video
Updated: May 14, 2026

A Robotic Platform to Study the Foreflipper of the California Sea Lion
Published on: January 10, 2017
Crawling scallop: friction-based locomotion with one degree of freedom
1Department of Mechanical and Aerospace Engineering, University of California San Diego, 9500 Gilman Drive, La Jolla, CA 92093-0411, USA. glwagner@ucsd.edu

Abstract:
Fluid-based locomotion at low Reynolds number is subject to the constraints of the scallop theorem, which dictate that body kinematics identical under a time-reversal symmetry (in particular, those with a single degree of freedom) cannot display locomotion on average. The implications of the theorem naturally compel one to ask whether similar symmetry constraints exist for locomotion in different environments. In this work we consider locomotion along a surface where forces are described by isotropic Coulomb friction. To address whether motions with a single degree of freedom can lead to transport, we analyze a model system consisting of two bodies whose separation distance undergoes periodic time variations. The behavior of the two-body system is entirely determined by the kinematic specification of their separation, the friction forces, and the mass of each body. We show that the constraints of the scallop theorem can be escaped in frictional media if two asymmetry conditions are met at the same time: the frictional forces of each body against the surface must be distinct and the time-variation of the body-body separation must vary asymmetrically in time (so quick-slow or slow-quick in the extension-contraction phases). Our results are demonstrated numerically and interpreted using asymptotic expansions.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:09
Rolling Without Slipping
 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can affect...
 01:10
Relative Motion Analysis - Acceleration
 01:05
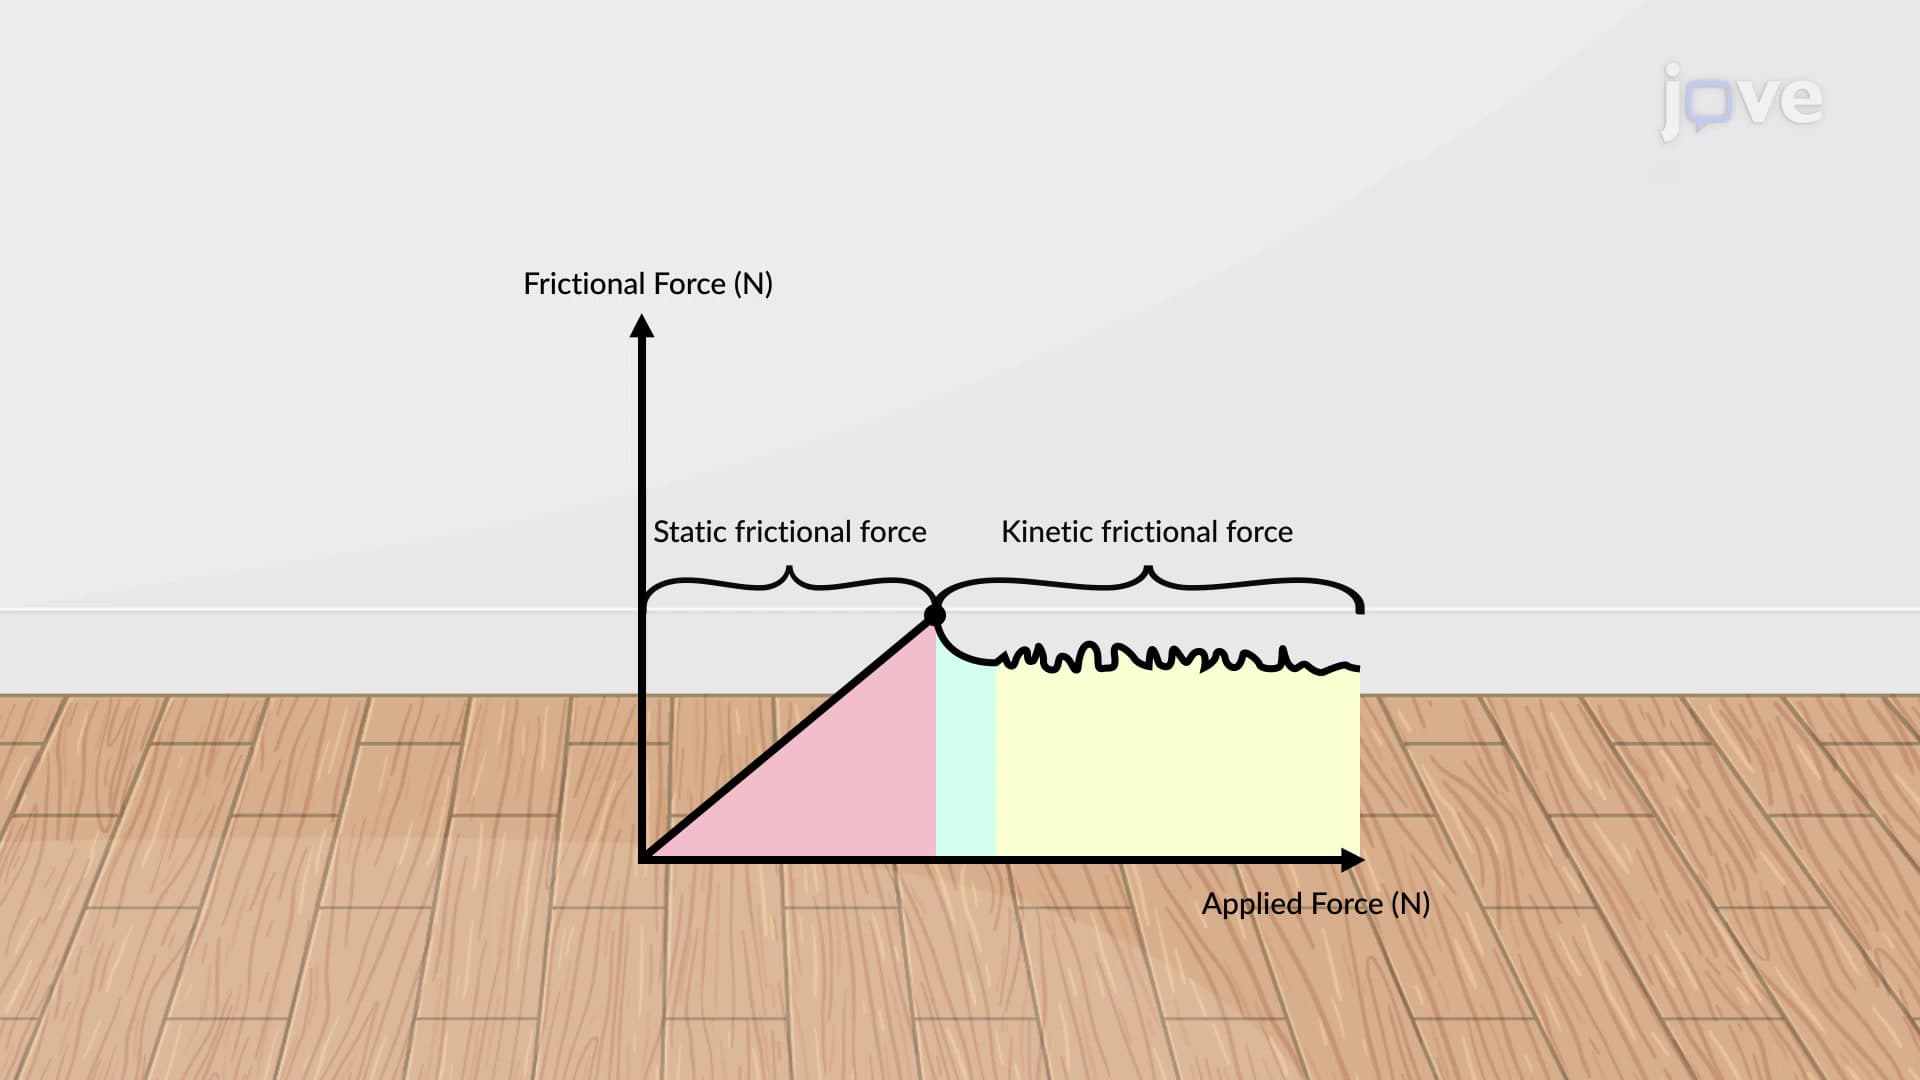
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Kinetic Friction