Kinematic evaluation of virtual walking trajectories
Related Experiment Video
Updated: May 14, 2026
Measuring the Kinematics of Daily Living Movements with Motion Capture Systems in Virtual Reality
Published on: April 5, 2018
Gabriel Cirio1, Anne-Hélène Olivier, Maud Marchal
1INRIA Rennes, France. gabriel.cirio@inria.fr

Abstract:
Virtual walking, a fundamental task in Virtual Reality (VR), is greatly influenced by the locomotion interface being used, by the specificities of input and output devices, and by the way the virtual environment is represented. No matter how virtual walking is controlled, the generation of realistic virtual trajectories is absolutely required for some applications, especially those dedicated to the study of walking behaviors in VR, navigation through virtual places for architecture, rehabilitation and training. Previous studies focused on evaluating the realism of locomotion trajectories have mostly considered the result of the locomotion task (efficiency, accuracy) and its subjective perception (presence, cybersickness). Few focused on the locomotion trajectory itself, but in situation of geometrically constrained task. In this paper, we study the realism of unconstrained trajectories produced during virtual walking by addressing the following question: did the user reach his destination by virtually walking along a trajectory he would have followed in similar real conditions? To this end, we propose a comprehensive evaluation framework consisting on a set of trajectographical criteria and a locomotion model to generate reference trajectories. We consider a simple locomotion task where users walk between two oriented points in space. The travel path is analyzed both geometrically and temporally in comparison to simulated reference trajectories. In addition, we demonstrate the framework over a user study which considered an initial set of common and frequent virtual walking conditions, namely different input devices, output display devices, control laws, and visualization modalities. The study provides insight into the relative contributions of each condition to the overall realism of the resulting virtual trajectories.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:15
Kinematic Equations: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:18
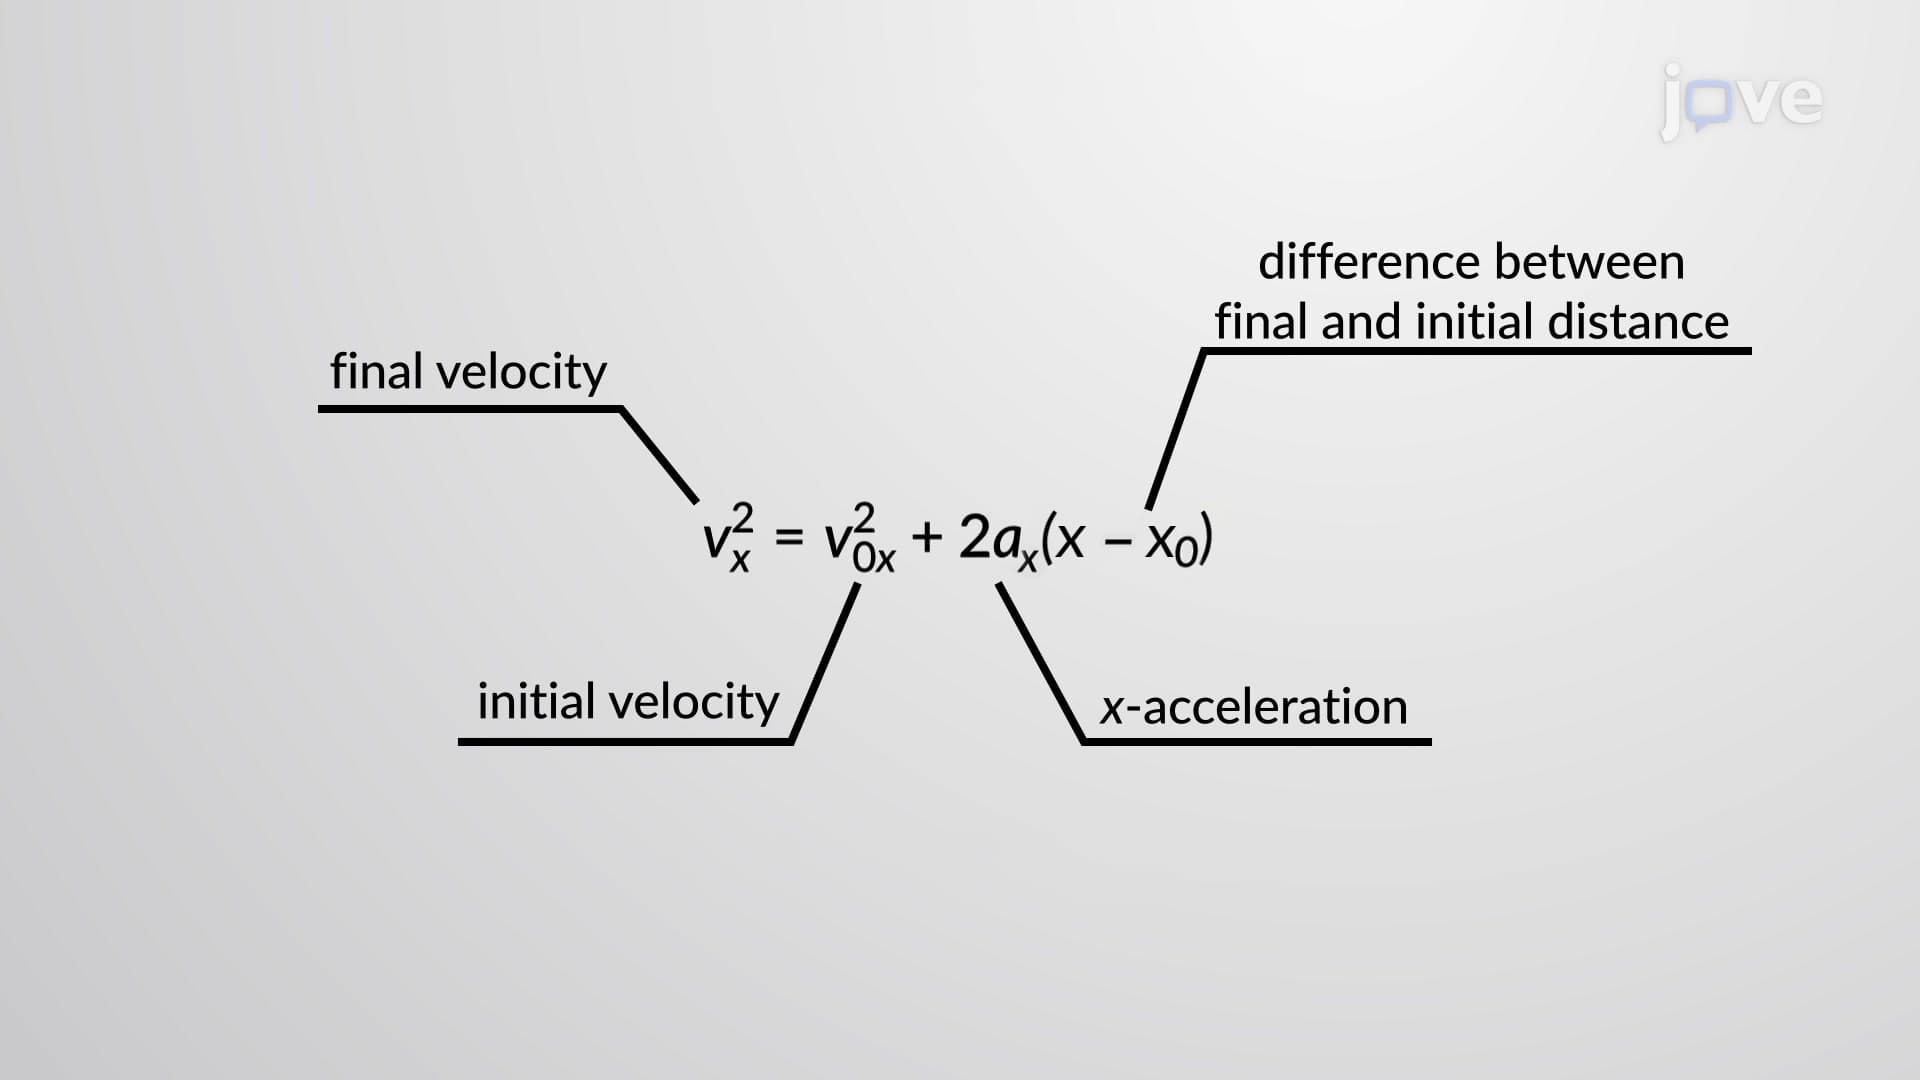
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...