Related Experiment Video
Updated: May 14, 2026

Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 4, 2013
Detection of 3D curved trajectories: the role of binocular disparity
Russell S Pierce1, Zhang Bian, Myron L Braunstein
1Visual Cognition and Human Performance Laboratory, Department of Psychology, University of California Riverside, CA, USA.

Abstract:
We examined the ability of observers to detect the 3D curvature of motion paths when binocular disparity and motion information were present. On each trial, two displays were observed through shutter-glasses. In one display, a sphere moved along a linear path in the horizontal and depth dimensions. In the other display, the sphere moved from the same starting position to the same ending position as in the linear path, but moved along an arc in depth. Observers were asked to indicate whether the first or second display simulated a curved trajectory. Adaptive staircases were used to derive the observers' thresholds of curvature detection. In the first experiment, two independent variables were manipulated: viewing condition (binocular vs. monocular) and type of curvature (concave vs. convex). In the second experiment, three independent variables were manipulated: viewing condition, type of curvature, and whether the motion direction was approaching or receding. In both experiments, detection thresholds were lower for binocular viewing conditions as compared to monocular viewing conditions. In addition, concave trajectories were easier to detect than convex trajectories. In the second experiment, the direction of motion did not significantly affect curvature detection. These results indicate the detection of curved motion paths from monocular information was improved when binocular information was present. The results also indicate the importance of the type of curvature, suggesting that the rate of change of disparity may be important in detecting curved trajectories.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:29
Sight Distance in a Vertical Curve
 01:27
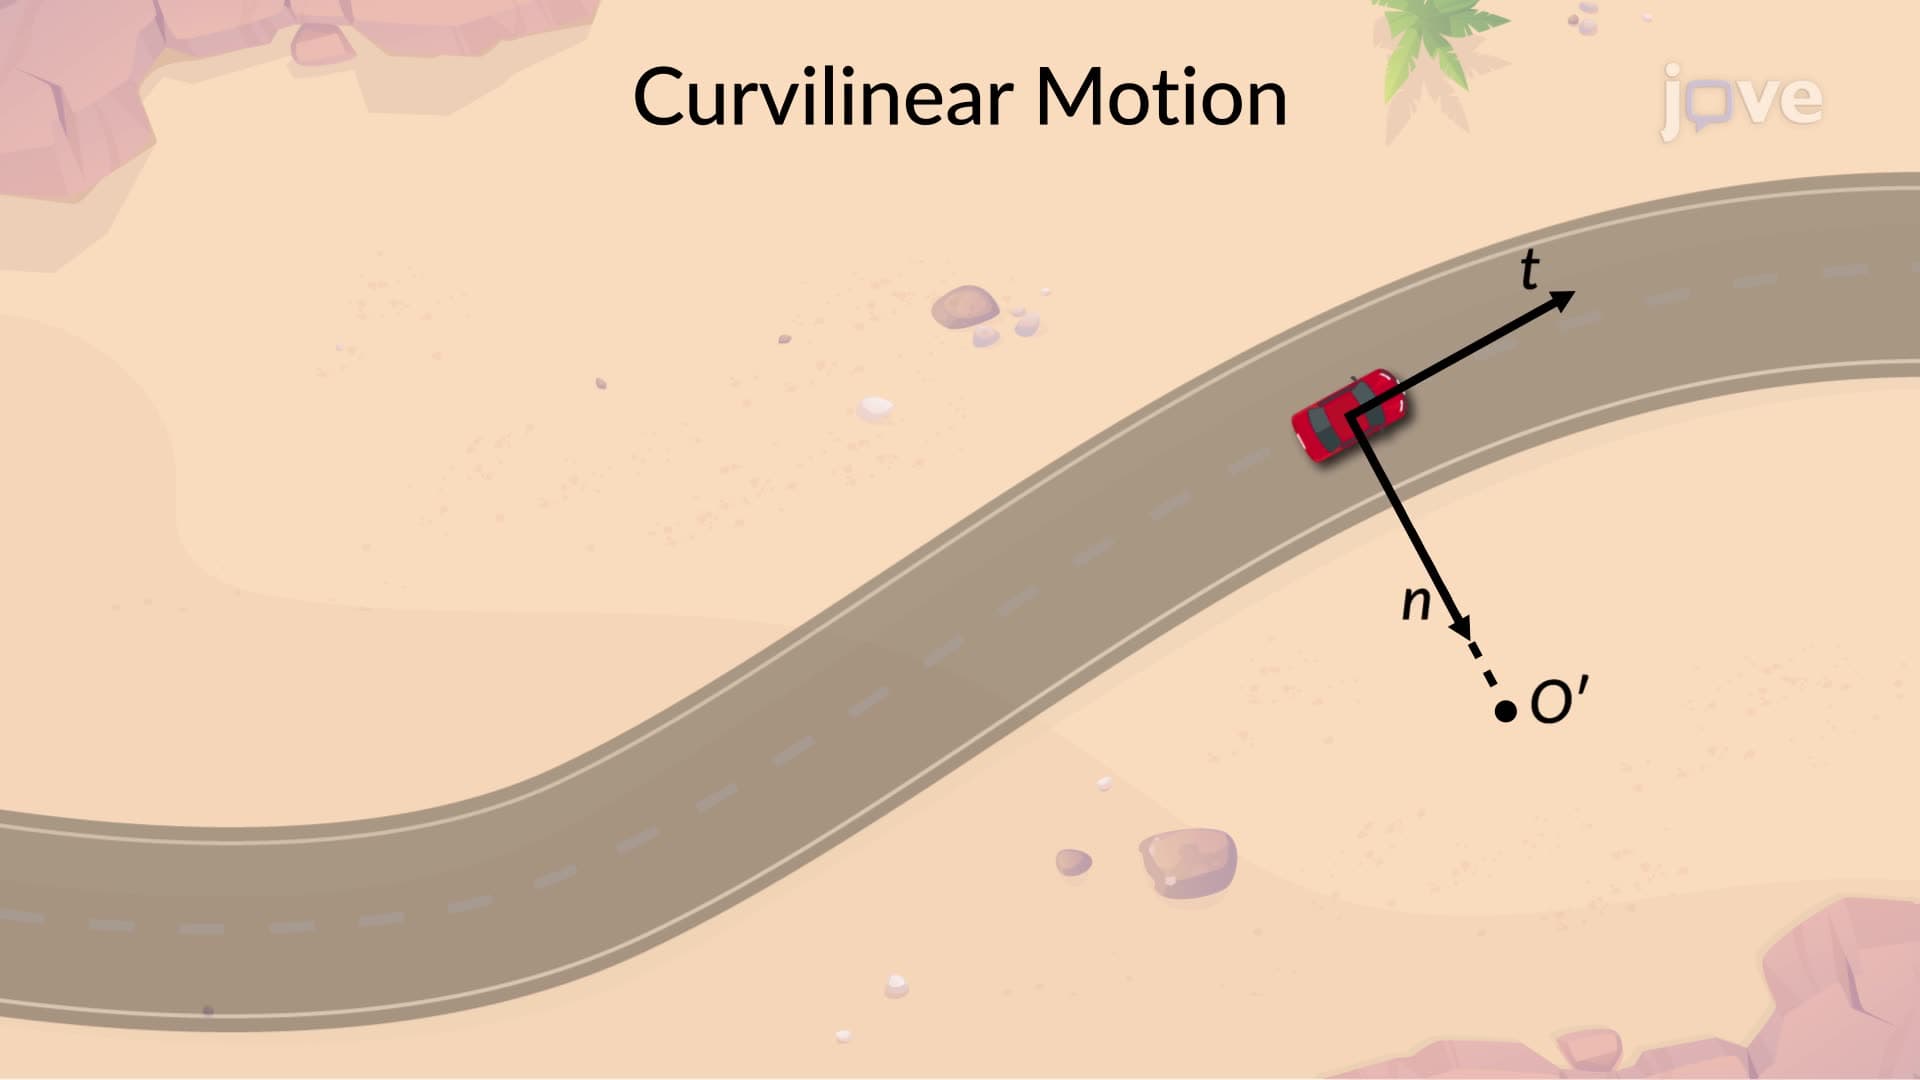
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
Curvilinear Motion: Polar Coordinates
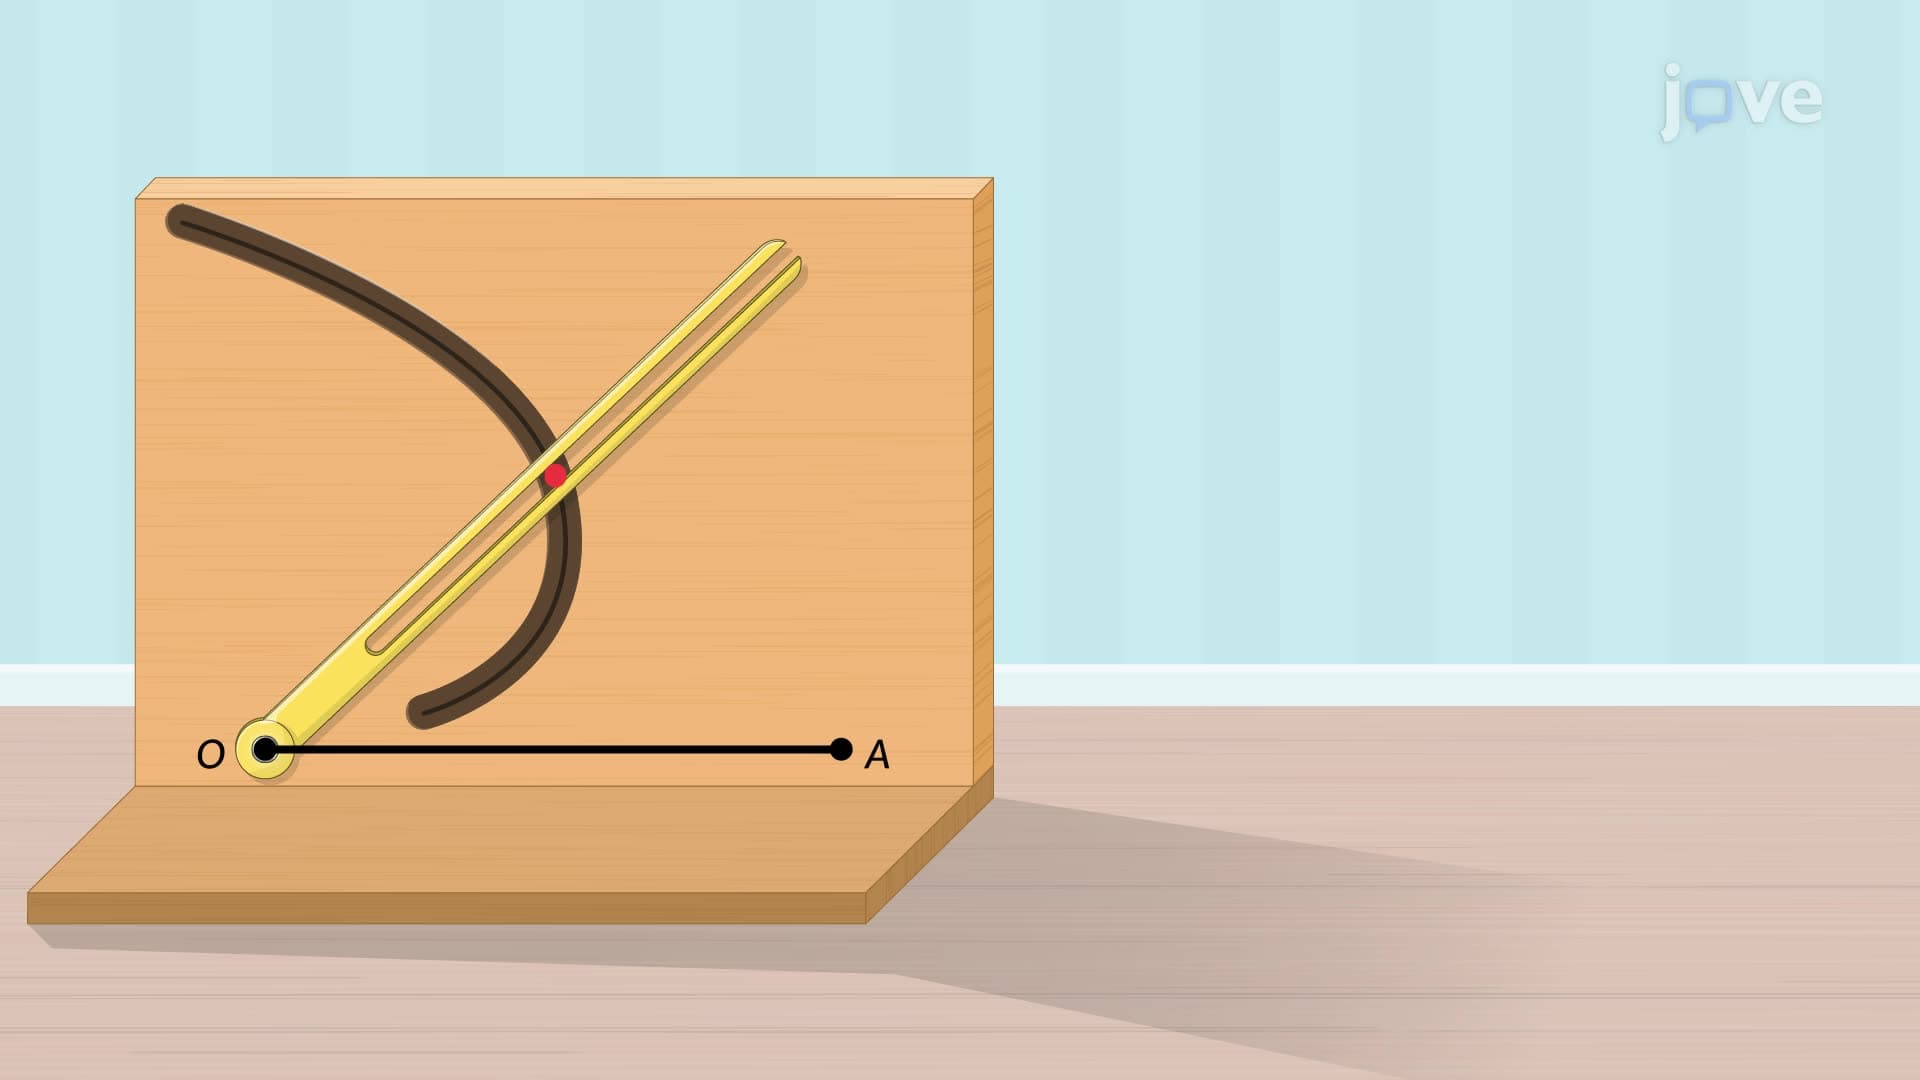
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...