Related Experiment Video
Updated: Aug 19, 2026
Improving Strength, Power, Muscle Aerobic Capacity, and Glucose Tolerance through Short-term Progressive Strength Training Among Elderly People
Published on: July 5, 2017
Torque-velocity relationships for the knee extensors in women in their 3rd and 7th decades
1Department of Physiology and Pharmacology, Queen's Medical Centre, University of Nottingham, UK.

Abstract:
Maximal isokinetic knee extensor strength was measured as torque in 17 young (mean age +/- SD, 21 +/- 3 years) and 16 elderly (68 +/- 5 years) women at 30 degrees (0.52 rad) before full extension, at angular velocities from 0 to 5.24 rad s-1, in 7 increments of 0.87 rad s-1. The elderly women were significantly weaker than the young women at all angular velocities. The rate of loss of absolute torque with increasing velocity was similar for both age groups, but when torque was standardised as a percentage of the individual's maximum, the elderly group showed a significantly greater rate of loss than the younger group. Quick-release from an isometric effort did not increase the recorded torques at 4.36 rad s-1 compared with the free-running method in either age group. The age differences are compatible with lower ratio of type II to type I fibre are in the older group.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:10
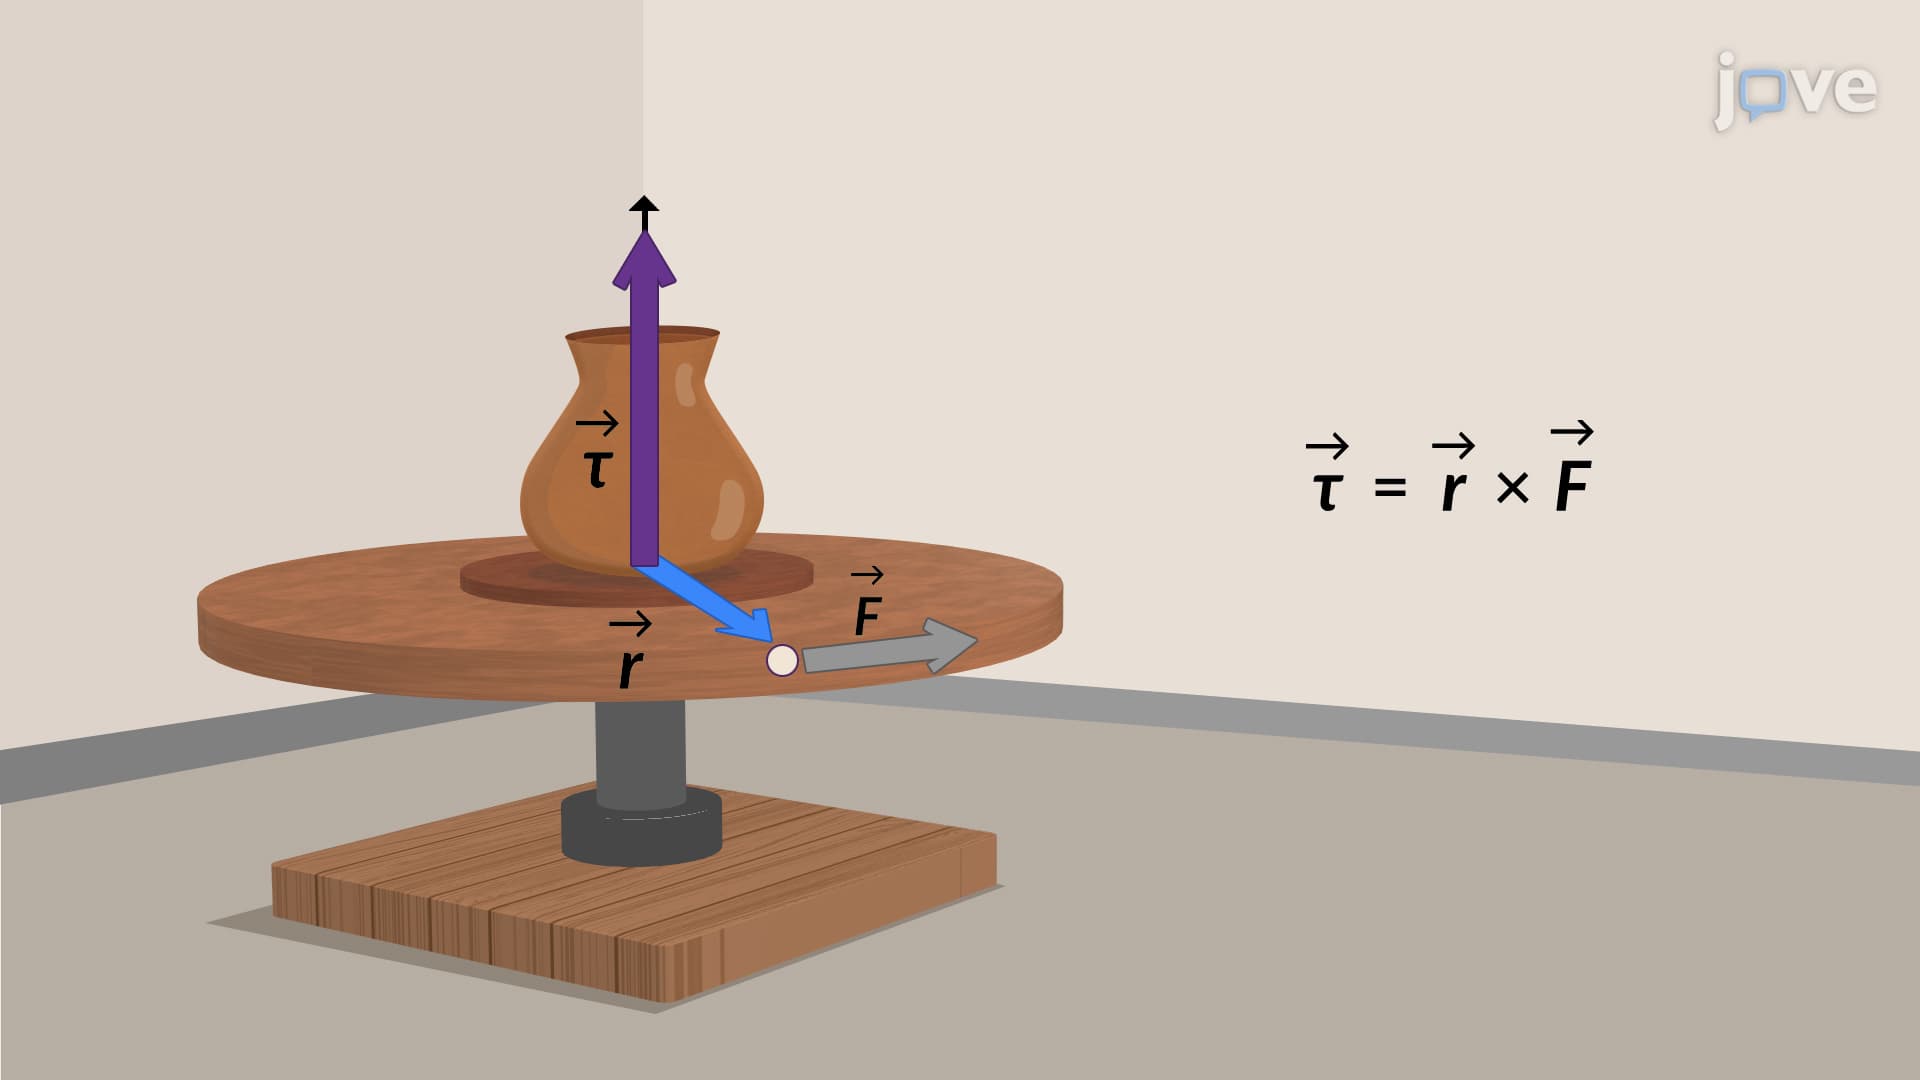
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:19
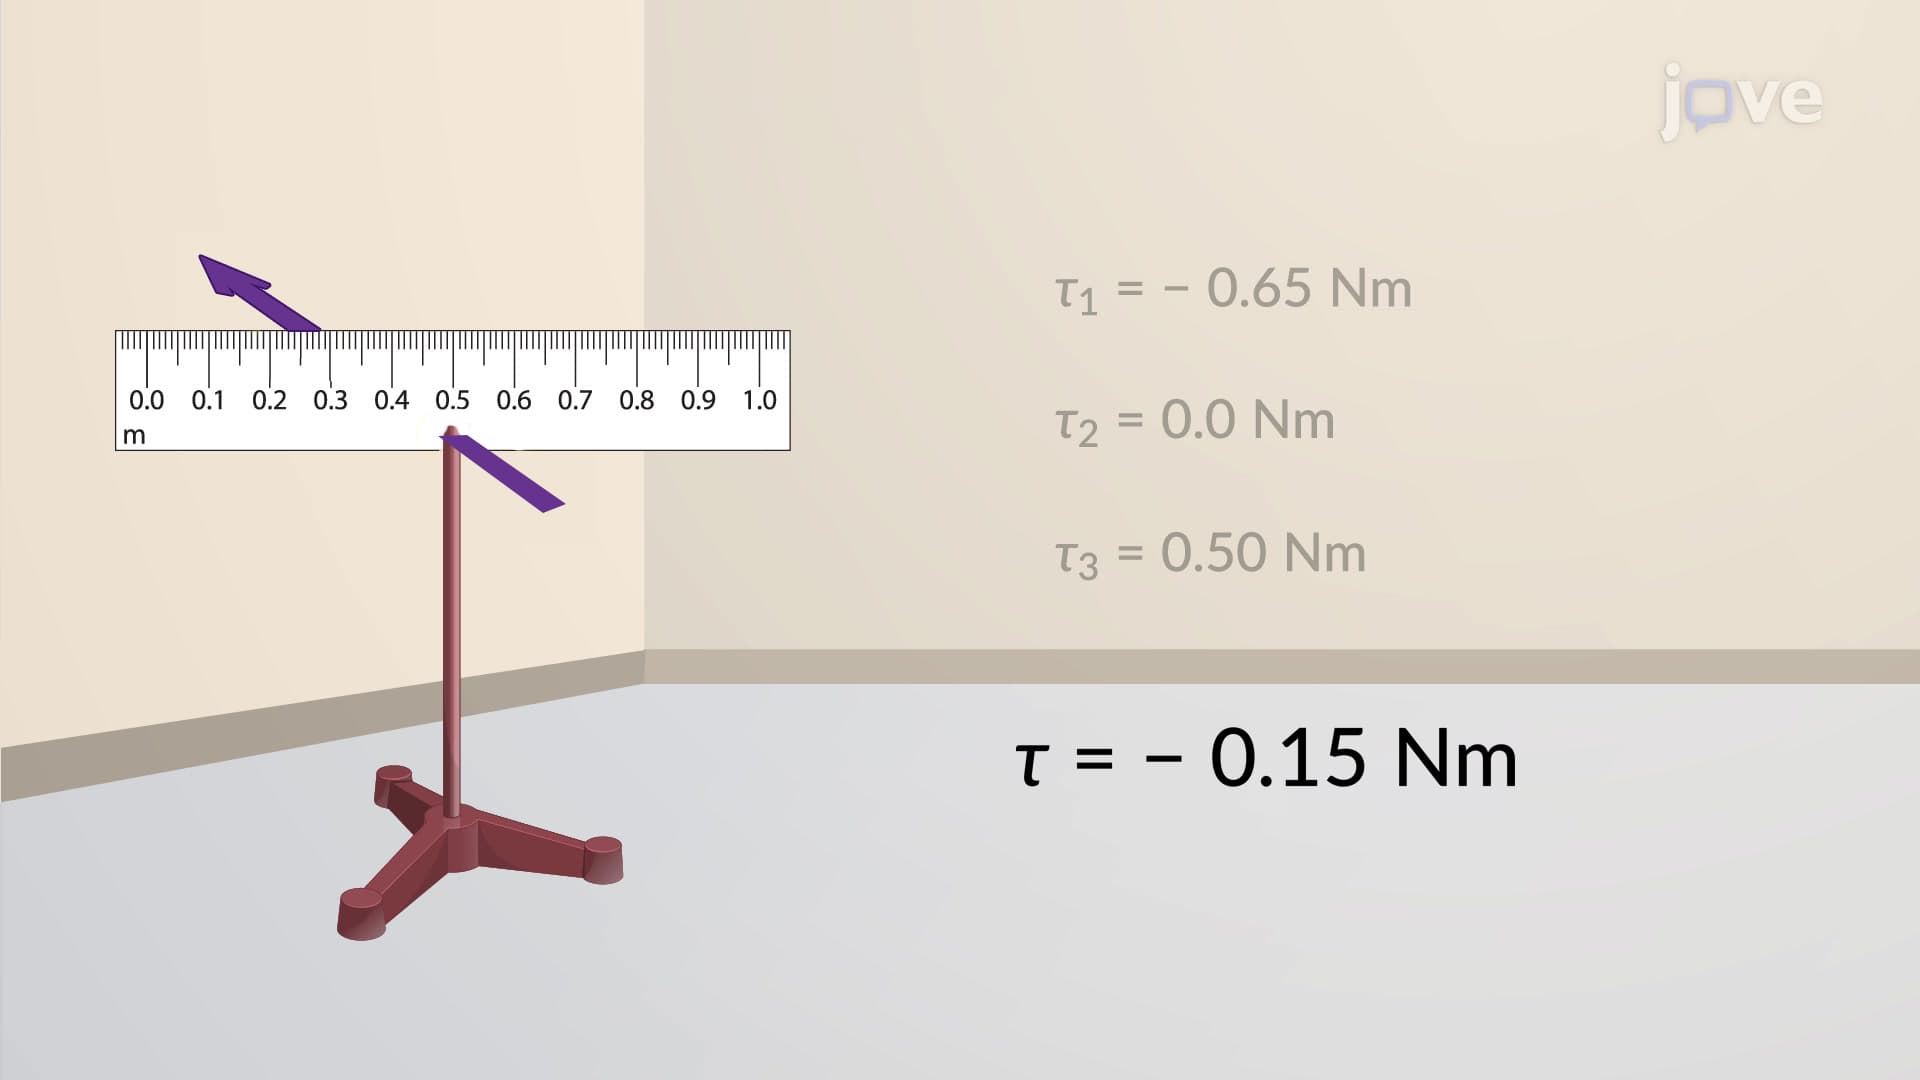
Net Torque Calculations
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris group...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...