Related Experiment Video
Updated: May 12, 2026

Using Virtual Reality to Transfer Motor Skill Knowledge from One Hand to Another
Published on: September 18, 2017
Dual adaptation to opposing visuomotor rotations with similar hand movement trajectories
Ravindra Baldeo1, Denise Henriques
1School of Kinesiology and Health Science, York University, 4700 Keele Street, Toronto, ON, M3J 1P3, Canada. rbaldeo@yorku.ca

Abstract:
This research explored specific contextual cues that might facilitate human motor learning. Using a dual adaptation task, humans performed manual reaches to visual targets while experiencing a 30° clockwise or counterclockwise rotation, which randomly alternated between trials, of a seen cursor representing their unseen hand. Groups had different cues to distinguish between rotations: 'Cue' (colours and shapes), 'Workspace' (target locations) and 'Workspace with Cue' (combination of cues). Importantly, the workspace groups required similar hand movement trajectories to accurately acquire pairs of targets. Our data show that only the 'Workspace' and 'Workspace with Cue' groups, but not 'Cue' group, adapted to both rotations concurrently (dual adaption). These findings suggest that colour and shape cues, even when integrated with the end-effector and targets, do not facilitate dual adaptation. However, target separation is sufficient to facilitate dual adaptation, even when hand movement trajectories are similar. Interestingly, adaptation was less complete when required hand trajectories were completely overlapping for pairs of targets (versus being similar), suggesting an important role for the motor system as well. Nonetheless, the location of targets and consequent differences in motor planning may play a larger role in facilitating adaptation than previously thought.

Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
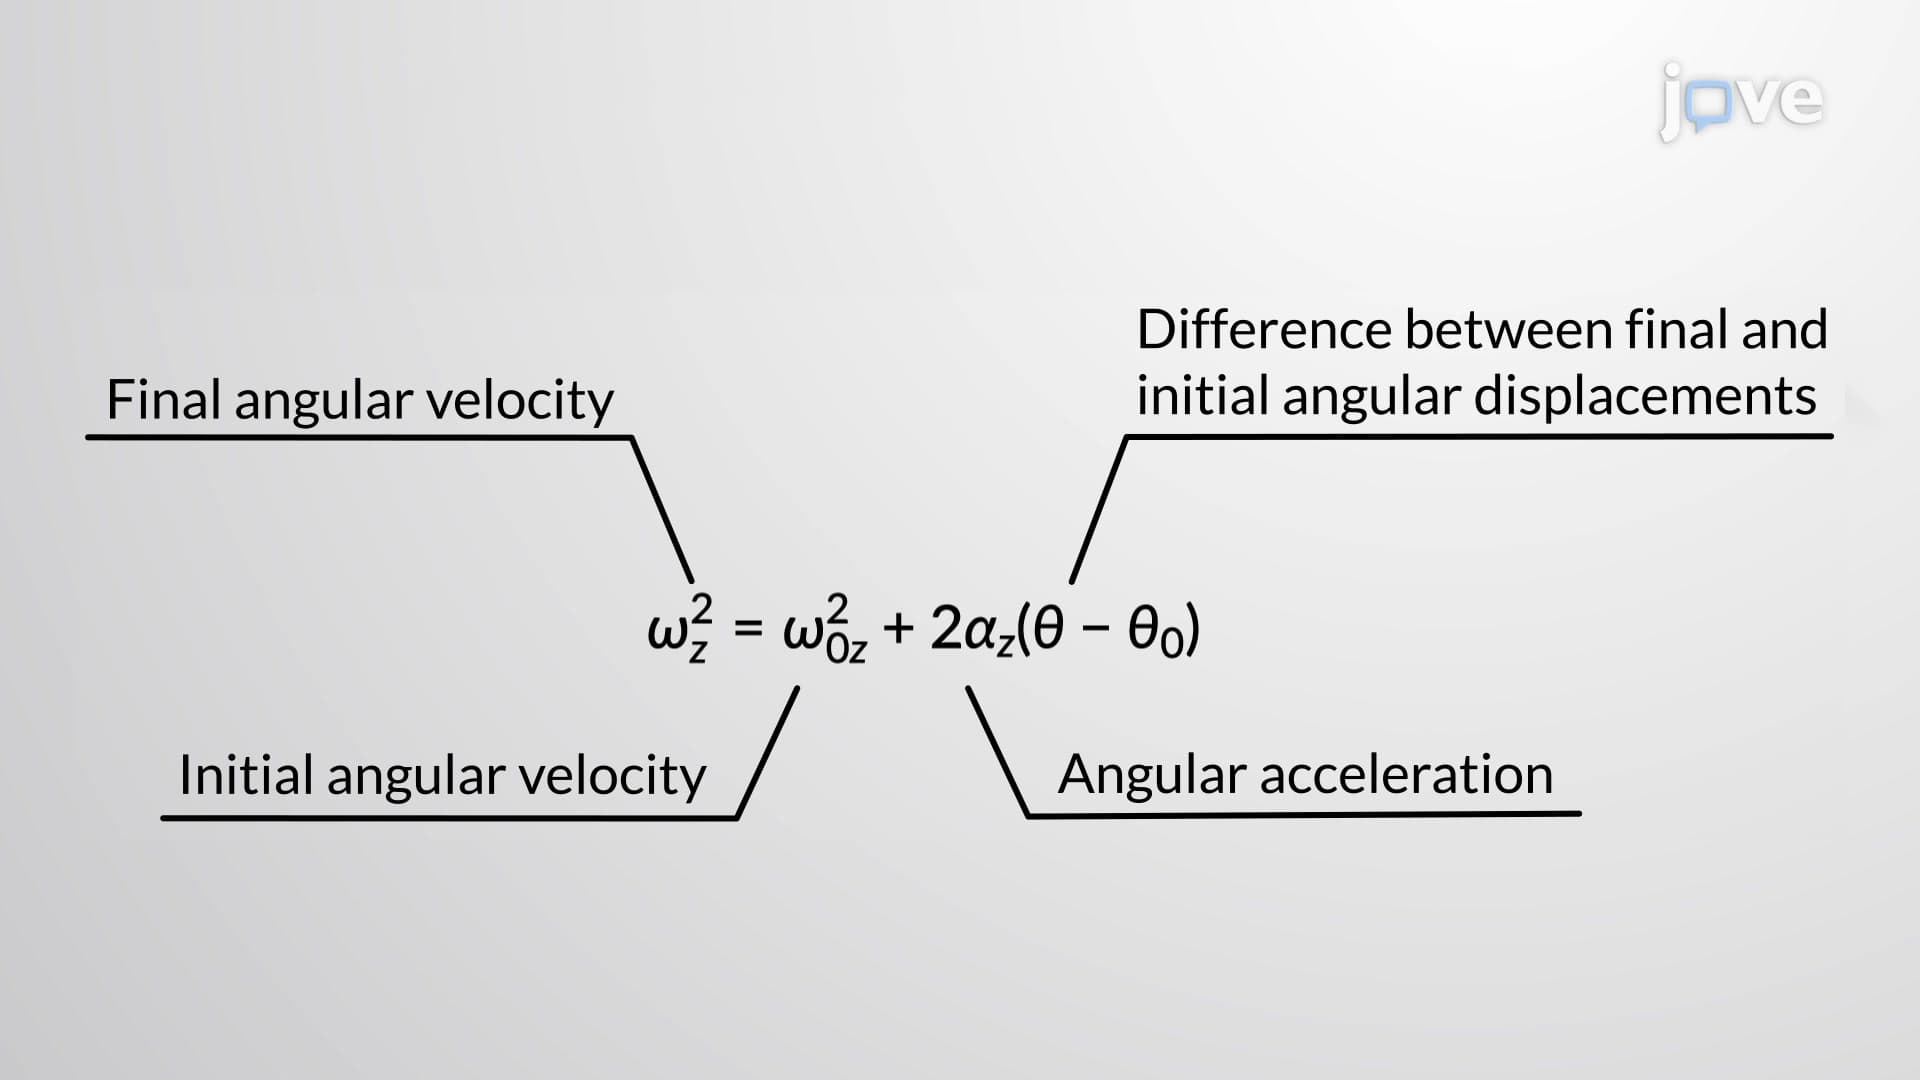
Rotation with Constant Angular Acceleration - II
The first...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:10
Relative Motion Analysis - Acceleration