Multi-sensor image registration based on algebraic projective invariants
Related Experiment Video
Updated: May 12, 2026
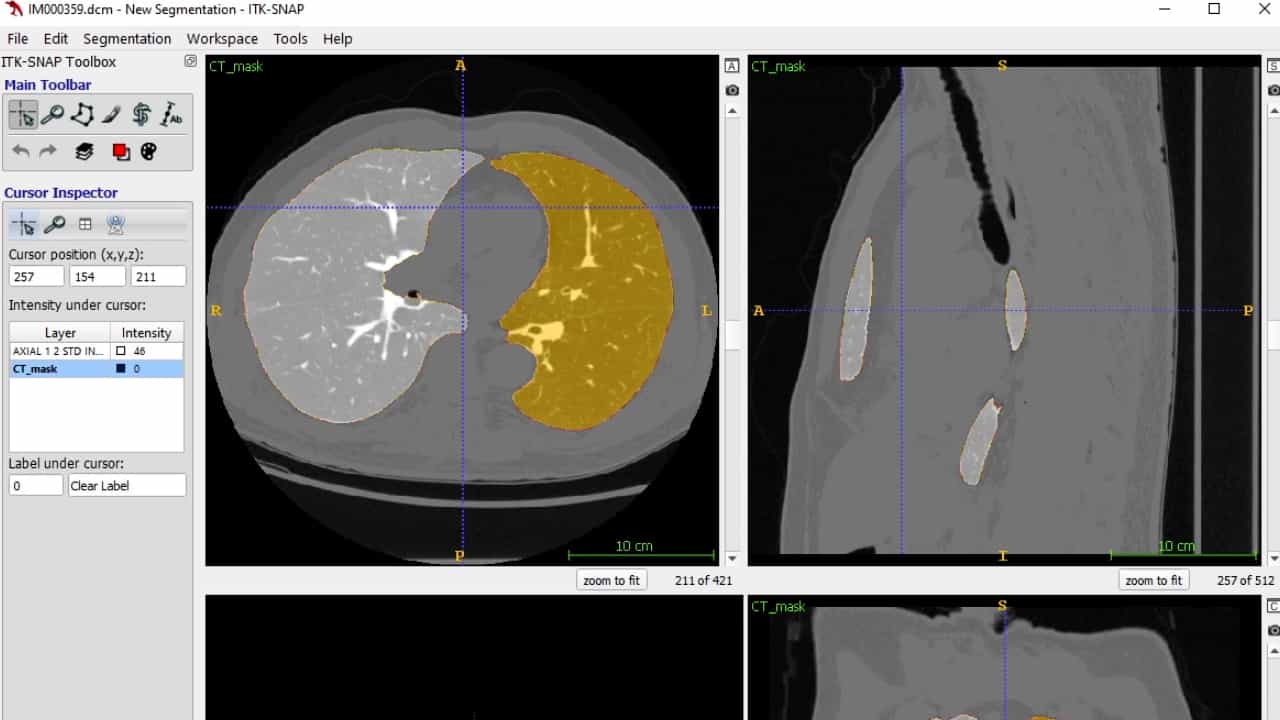
Multi-modal Pulmonary Imaging: Using Complementary Information from CT and Hyperpolarized 129Xe MRI to Evaluate Lung Structure-Function
Published on: April 12, 2024
1Department of Automation, Tsinghua University, Beijing, 100084, China. libin09@mails.tsinghua.edu.cn

Abstract:
A new automatic feature-based registration algorithm is presented for multi-sensor images with projective deformation. Contours are firstly extracted from both reference and sensed images as basic features in the proposed method. Since it is difficult to design a projective-invariant descriptor from the contour information directly, a new feature named Five Sequential Corners (FSC) is constructed based on the corners detected from the extracted contours. By introducing algebraic projective invariants, we design a descriptor for each FSC that is ensured to be robust against projective deformation. Further, no gray scale related information is required in calculating the descriptor, thus it is also robust against the gray scale discrepancy between the multi-sensor image pairs. Experimental results utilizing real image pairs are presented to show the merits of the proposed registration method.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:24
Area Computation by the Alternative Coordinate Method
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...