Related Experiment Video
Updated: May 11, 2026
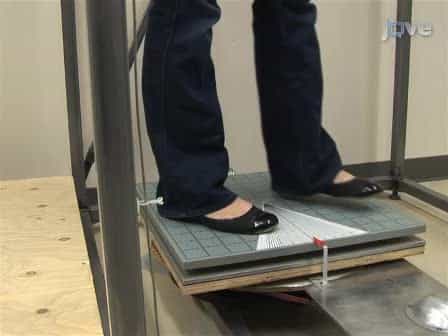

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Rider trunk and bicycle pose estimation with fusion of force/inertial sensors
Yizhai Zhang1, Kuo Chen, Jingang Yi
1Department of Mechanical and Aerospace Engineering, Rutgers University, Piscataway, NJ 08854, USA. yzzhang@eden.rutgers.edu

Abstract:
Estimation of human pose in physical human-machine interactions such as bicycling is challenging because of highly-dimensional human motion and lack of inexpensive, effective motion sensors. In this paper, we present a computational scheme to estimate both the rider trunk pose and the bicycle roll angle using only inertial and force sensors. The estimation scheme is built on a rider-bicycle dynamic model and the fusion of the wearable inertial sensors and the bicycle force sensors. We take advantages of the attractive properties of the robust force measurements and the motion-sensitive inertial measurements. The rider-bicycle dynamic model provides the underlying relationship between the force and the inertial measurements. The extended Kalman filter-based sensor fusion design fully incorporates the dynamic effects of the force measurements. The performance of the estimation scheme is demonstrated through extensive indoor and outdoor riding experiments.
Related Concept Videos
 01:30
Three-Dimensional Force System
 01:23
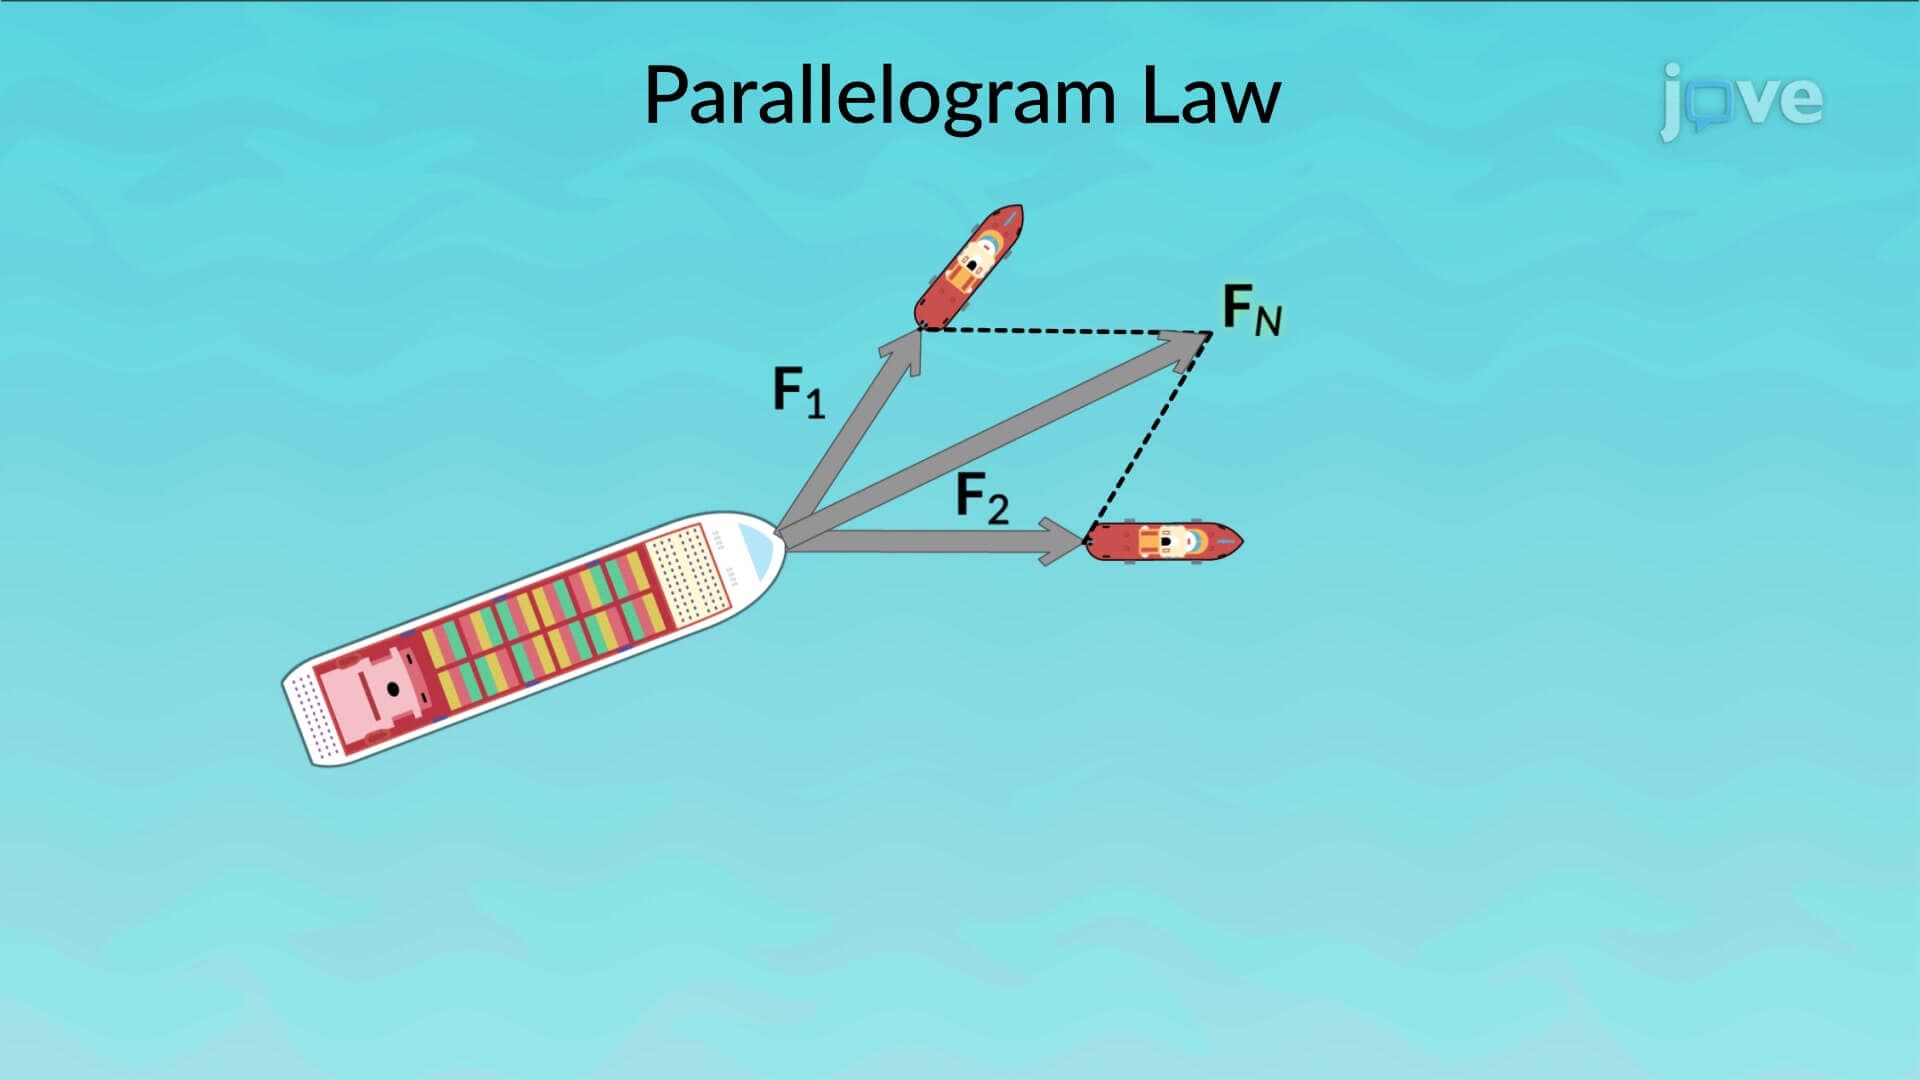
Vector Addition of Forces
To understand the concept of vector addition, consider the scenario of a ship being pulled by two small tugboats. The two forces, F1 and F2, act concurrently on the ship in different directions. The parallelogram law can be used to calculate the net force...
 01:20
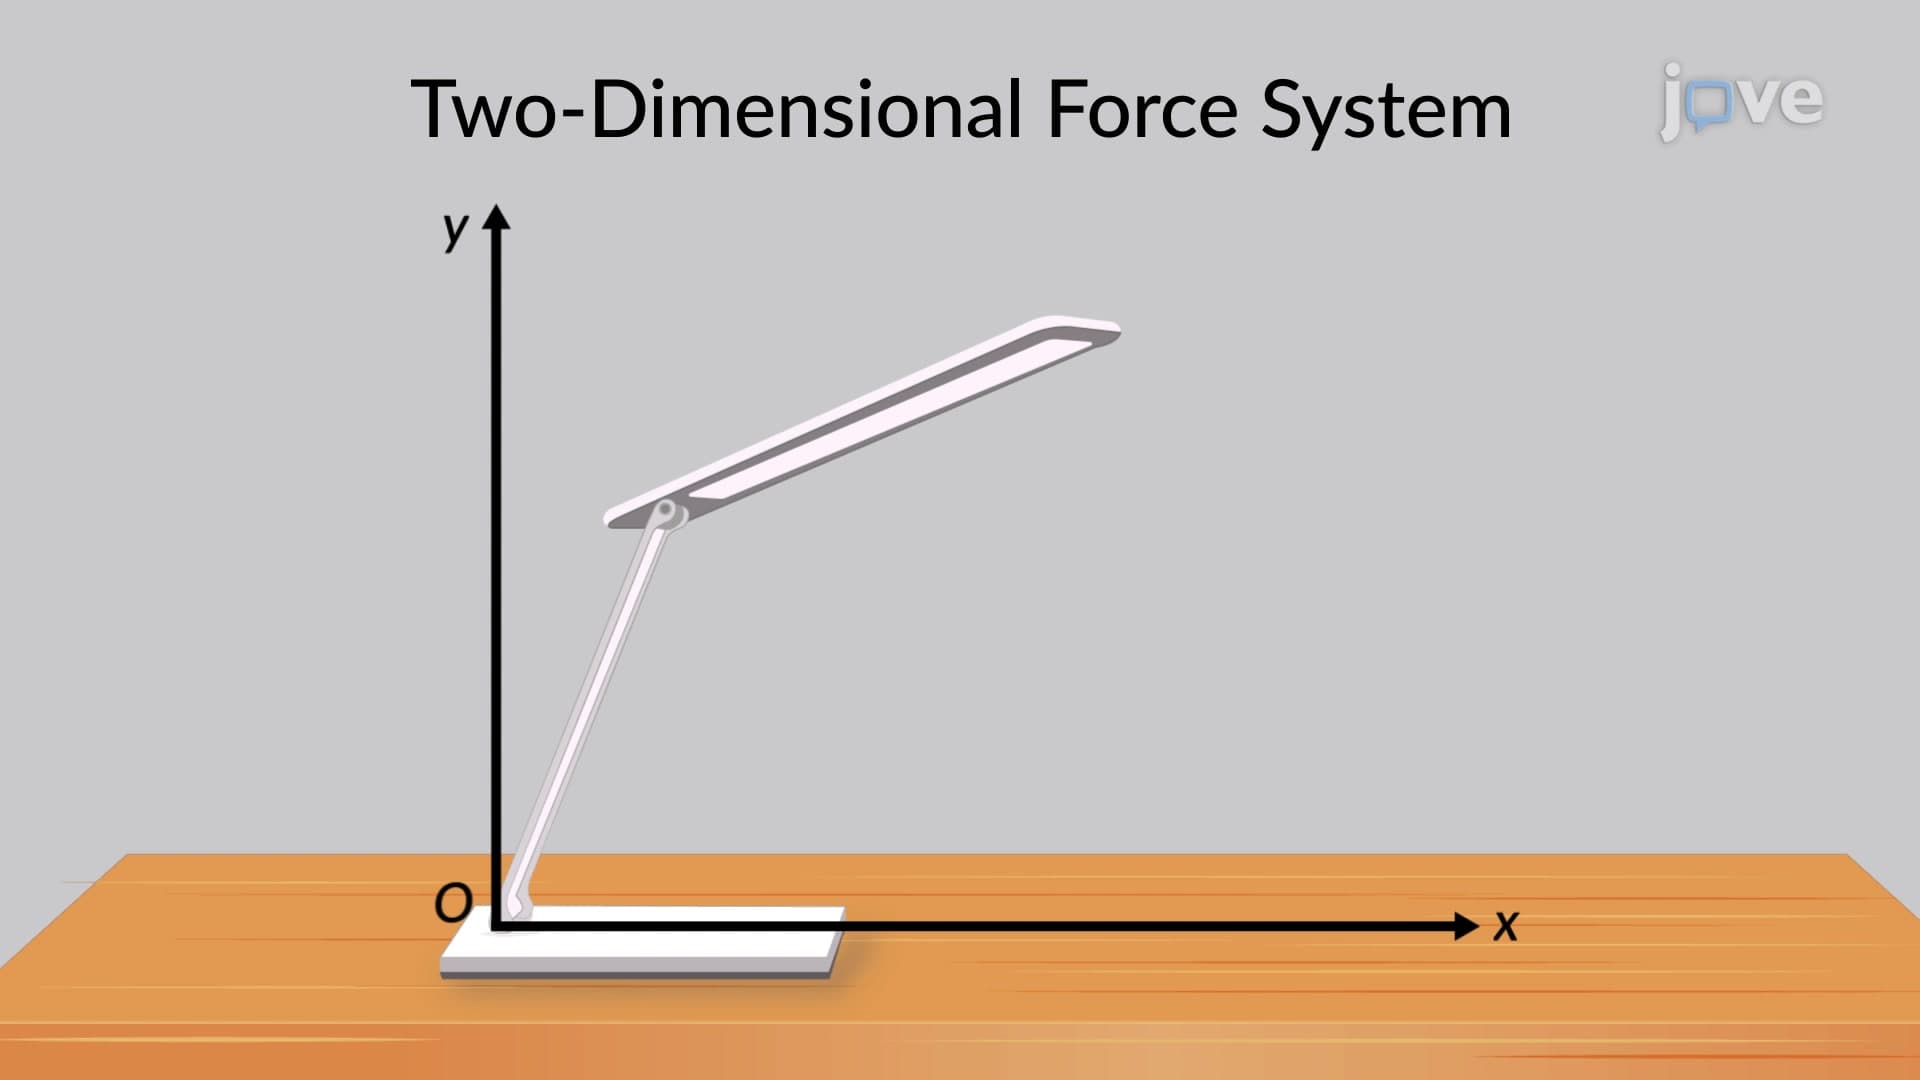
Two-Dimensional Force System
 01:03
Inertial Frames of Reference
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...