Error analysis in parallel two-step phase-shifting method

Anh-Hoang Phan1, Mei-lan Piao, Jae-Hyeung Park

  • 1School of Information and Communication Engineering, Chungbuk National University, Jeonju 361-763, South Korea.

Applied Optics
|May 15, 2013
PubMed

Related Concept Videos

Time and frequency -Domain Interpretation of Phase-lead Control01:24

Time and frequency -Domain Interpretation of Phase-lead Control

Phase-lead controllers are commonly used in various control systems to enhance response speed and stability. Adjusting the brightness on a television screen offers a practical example of phase-lead control. When contrast is enhanced, a phase-lead controller is employed. Mathematically, phase-lead control is identified when the first parameter is smaller than the second.
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
The Y-to-Y Circuit01:19

The Y-to-Y Circuit

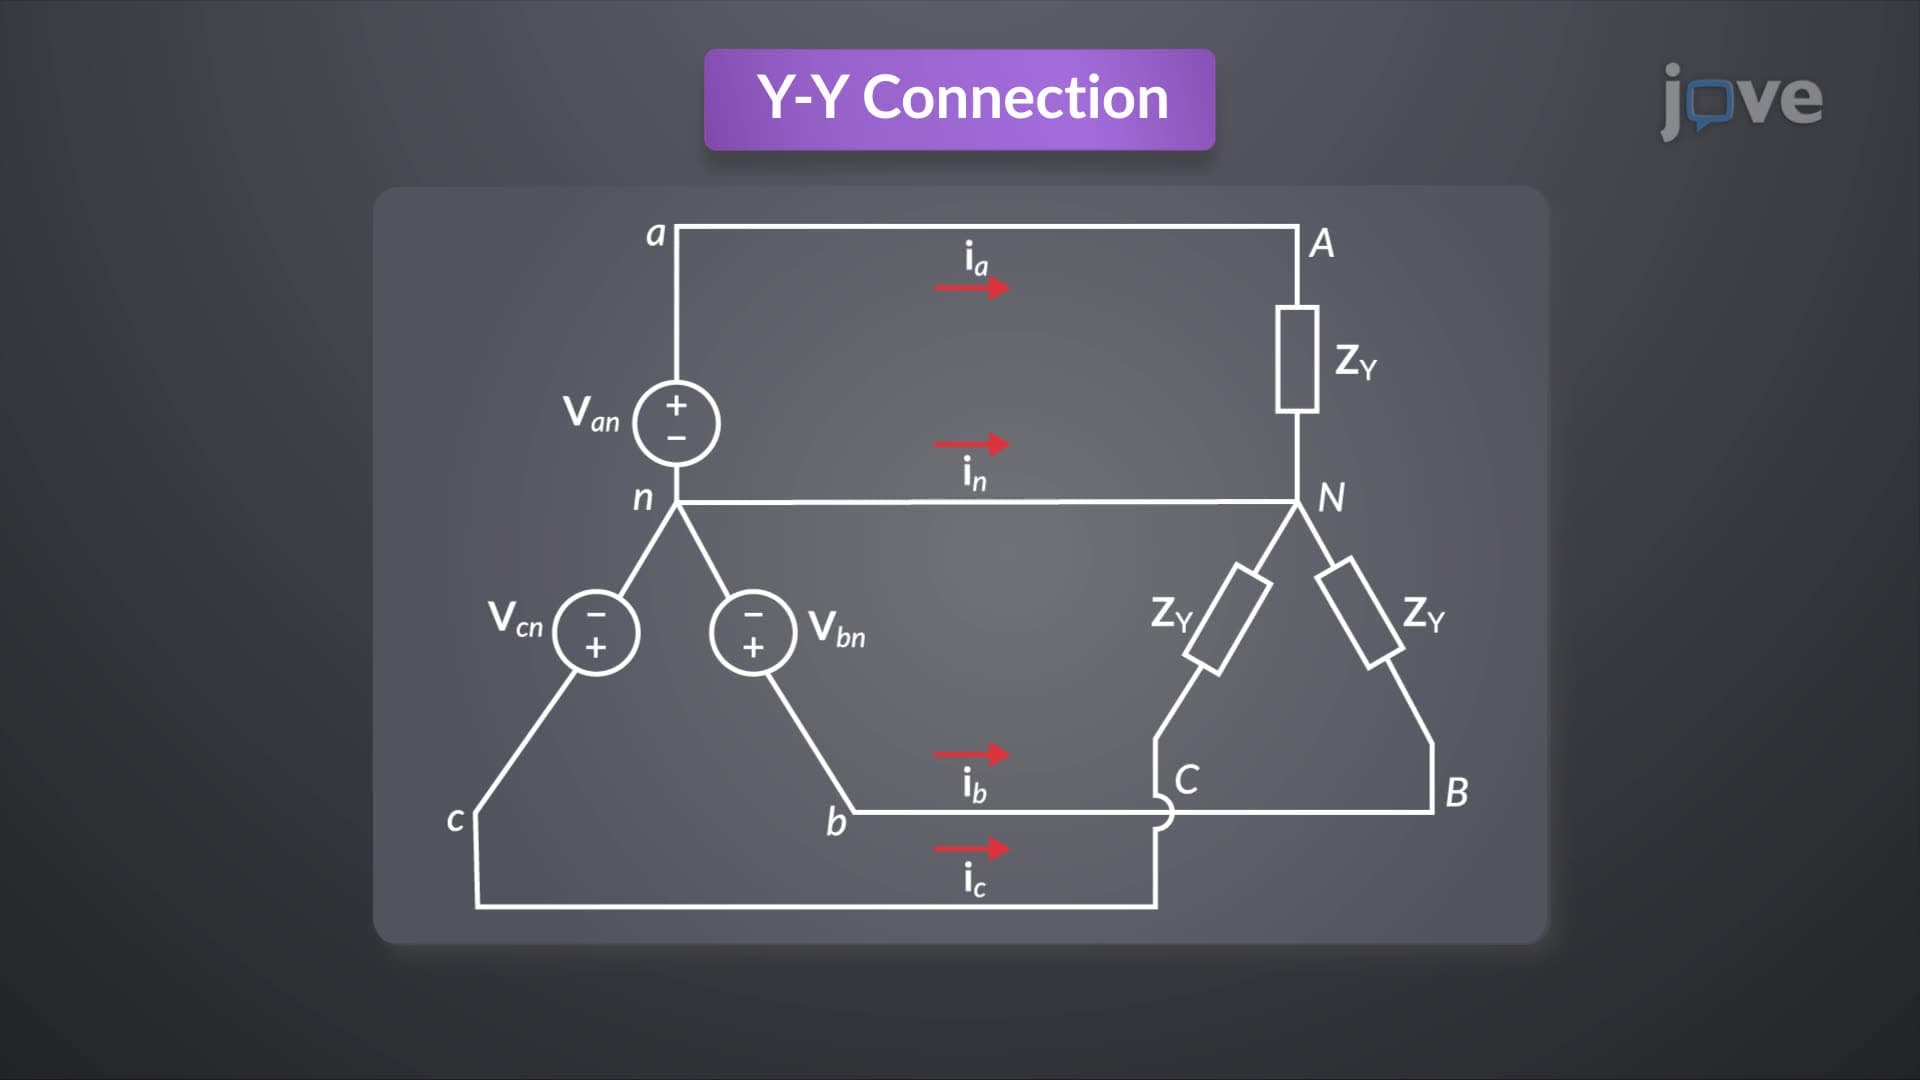
In a balanced four-wire wye-to-wye system, the arrangement involves wye-connected sinusoidal voltage sources and loads, connected through a neutral wire that links the neutral nodes of the source and load. The load impedance is connected across each phase of the load. The wye-connected source can be connected to the wye-connected load in four-wire and three-wire arrangements. A three-phase system is considered balanced when the load on each phase is equal, leading to uniform current flow and...
Fault Types01:18

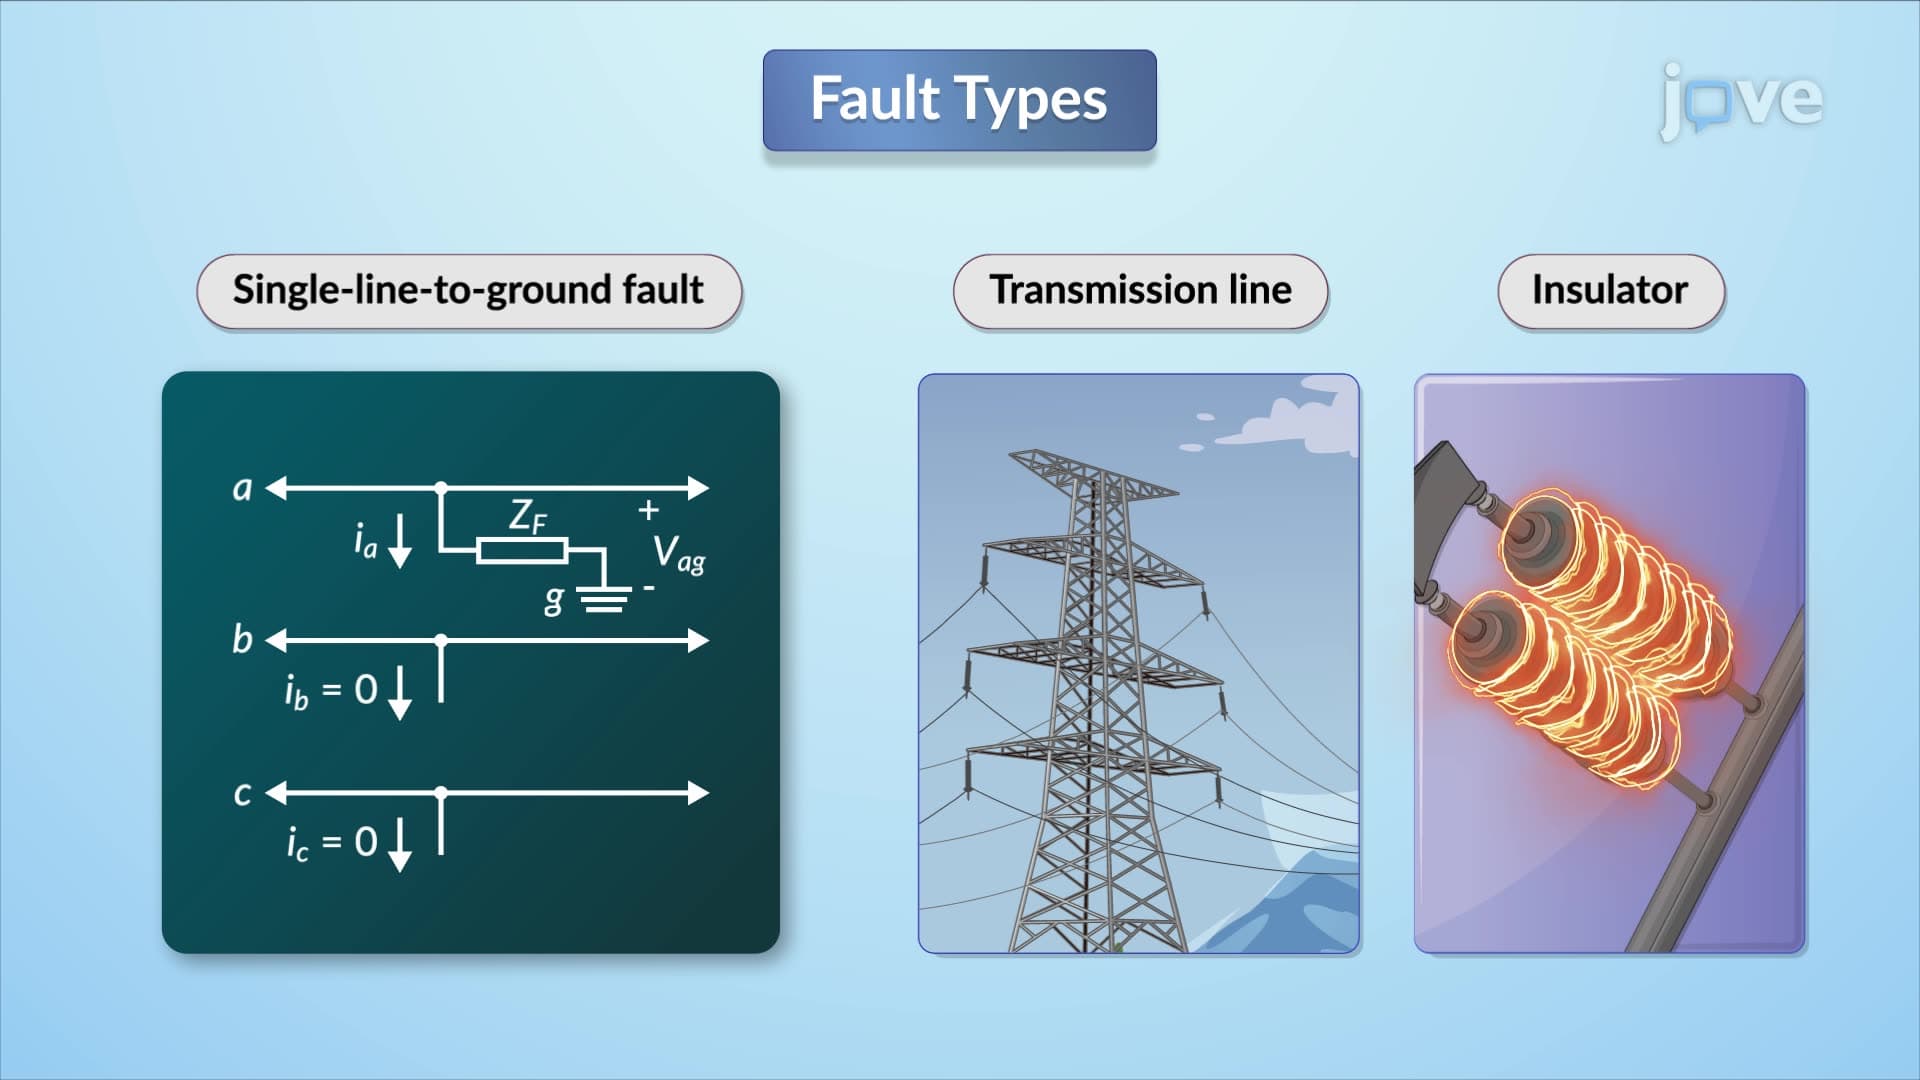
Fault Types

When analyzing a single line-to-ground fault from phase A to ground at a three-phase bus, it is important to consider the fault impedance. This impedance is zero for a bolted fault, equal to the arc impedance for an arcing fault, and represents the total fault impedance for a transmission-line insulator flashover. To derive sequence and phase currents, fault conditions are translated from the phase domain to the sequence domain.
For line-to-line faults occurring between phases B and C, the...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Power System Three-Phase Short Circuits01:21

Power System Three-Phase Short Circuits

Determining the subtransient fault current in a power system involves representing transformers by their leakage reactances, transmission lines by their equivalent series reactances, and synchronous machines as constant voltage sources behind their subtransient reactances. In this analysis, certain elements are excluded, such as winding resistances, series resistances, shunt admittances, delta-Y phase shifts, armature resistance, saturation, saliency, non-rotating impedance loads, and small...
Time and frequency -Domain Interpretation of Phase-lag Control01:21

Time and frequency -Domain Interpretation of Phase-lag Control

Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...