Related Experiment Video
Updated: May 11, 2026
Utilizing vmTracking to Improve the Accuracy of Multi-Animal Pose Estimation in Rodent Social Behavior Studies
Published on: November 7, 2025
A general framework for tracking multiple people from a moving camera
Wongun Choi1, Caroline Pantofaru, Silvio Savarese
1Department of Electrical and Computer Engineering, University of Michigan, Room 4435, 1301 Beal Avenue, Ann Arbor, MI 48109-2122, USA. wgchoi@umich.edu

Abstract:
In this paper, we present a general framework for tracking multiple, possibly interacting, people from a mobile vision platform. To determine all of the trajectories robustly and in a 3D coordinate system, we estimate both the camera's ego-motion and the people's paths within a single coherent framework. The tracking problem is framed as finding the MAP solution of a posterior probability, and is solved using the reversible jump Markov chain Monte Carlo (RJ-MCMC) particle filtering method. We evaluate our system on challenging datasets taken from moving cameras, including an outdoor street scene video dataset, as well as an indoor RGB-D dataset collected in an office. Experimental evidence shows that the proposed method can robustly estimate a camera's motion from dynamic scenes and stably track people who are moving independently or interacting.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:03
Inertial Frames of Reference
 01:27
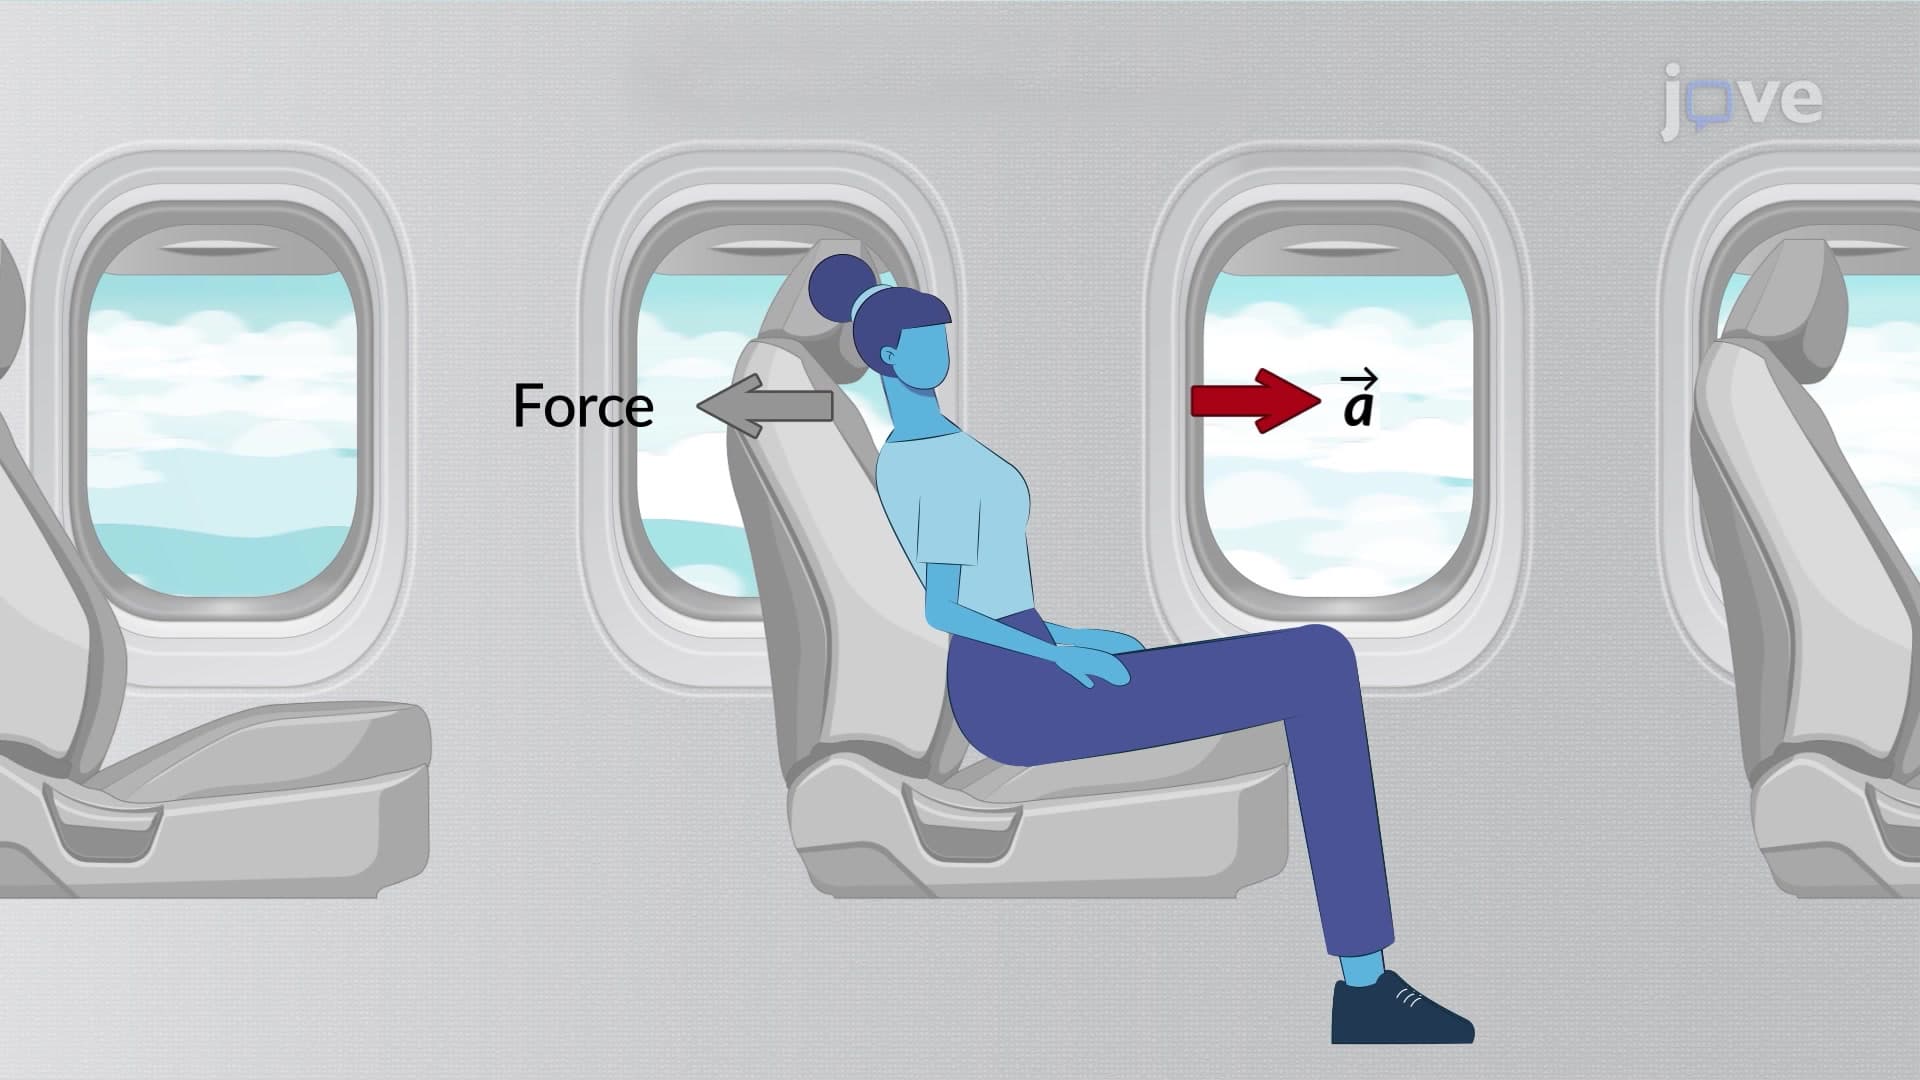
Non-inertial Frames of Reference
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Orthogonal Trajectories