Related Experiment Video
Updated: May 10, 2026

Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
Measurement of the robot motor capability of a robot motor system: a Fitts's-law-inspired approach
1Graduate Institute of Automation Technology, National Taipei University of Technology, Taipei 10608, Taiwan. sofin@ntut.edu.tw

Abstract:
Robot motor capability is a crucial factor for a robot, because it affects how accurately and rapidly a robot can perform a motion to accomplish a task constrained by spatial and temporal conditions. In this paper, we propose and derive a pseudo-index of motor performance (pIp) to characterize robot motor capability with robot kinematics, dynamics and control taken into consideration. The proposed pIp provides a quantitative measure for a robot with revolute joints, which is inspired from an index of performance in Fitts's law of human skills. Computer simulations and experiments on a PUMA 560 industrial robot were conducted to validate the proposed pIp for performing a motion accurately and rapidly.

Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:14
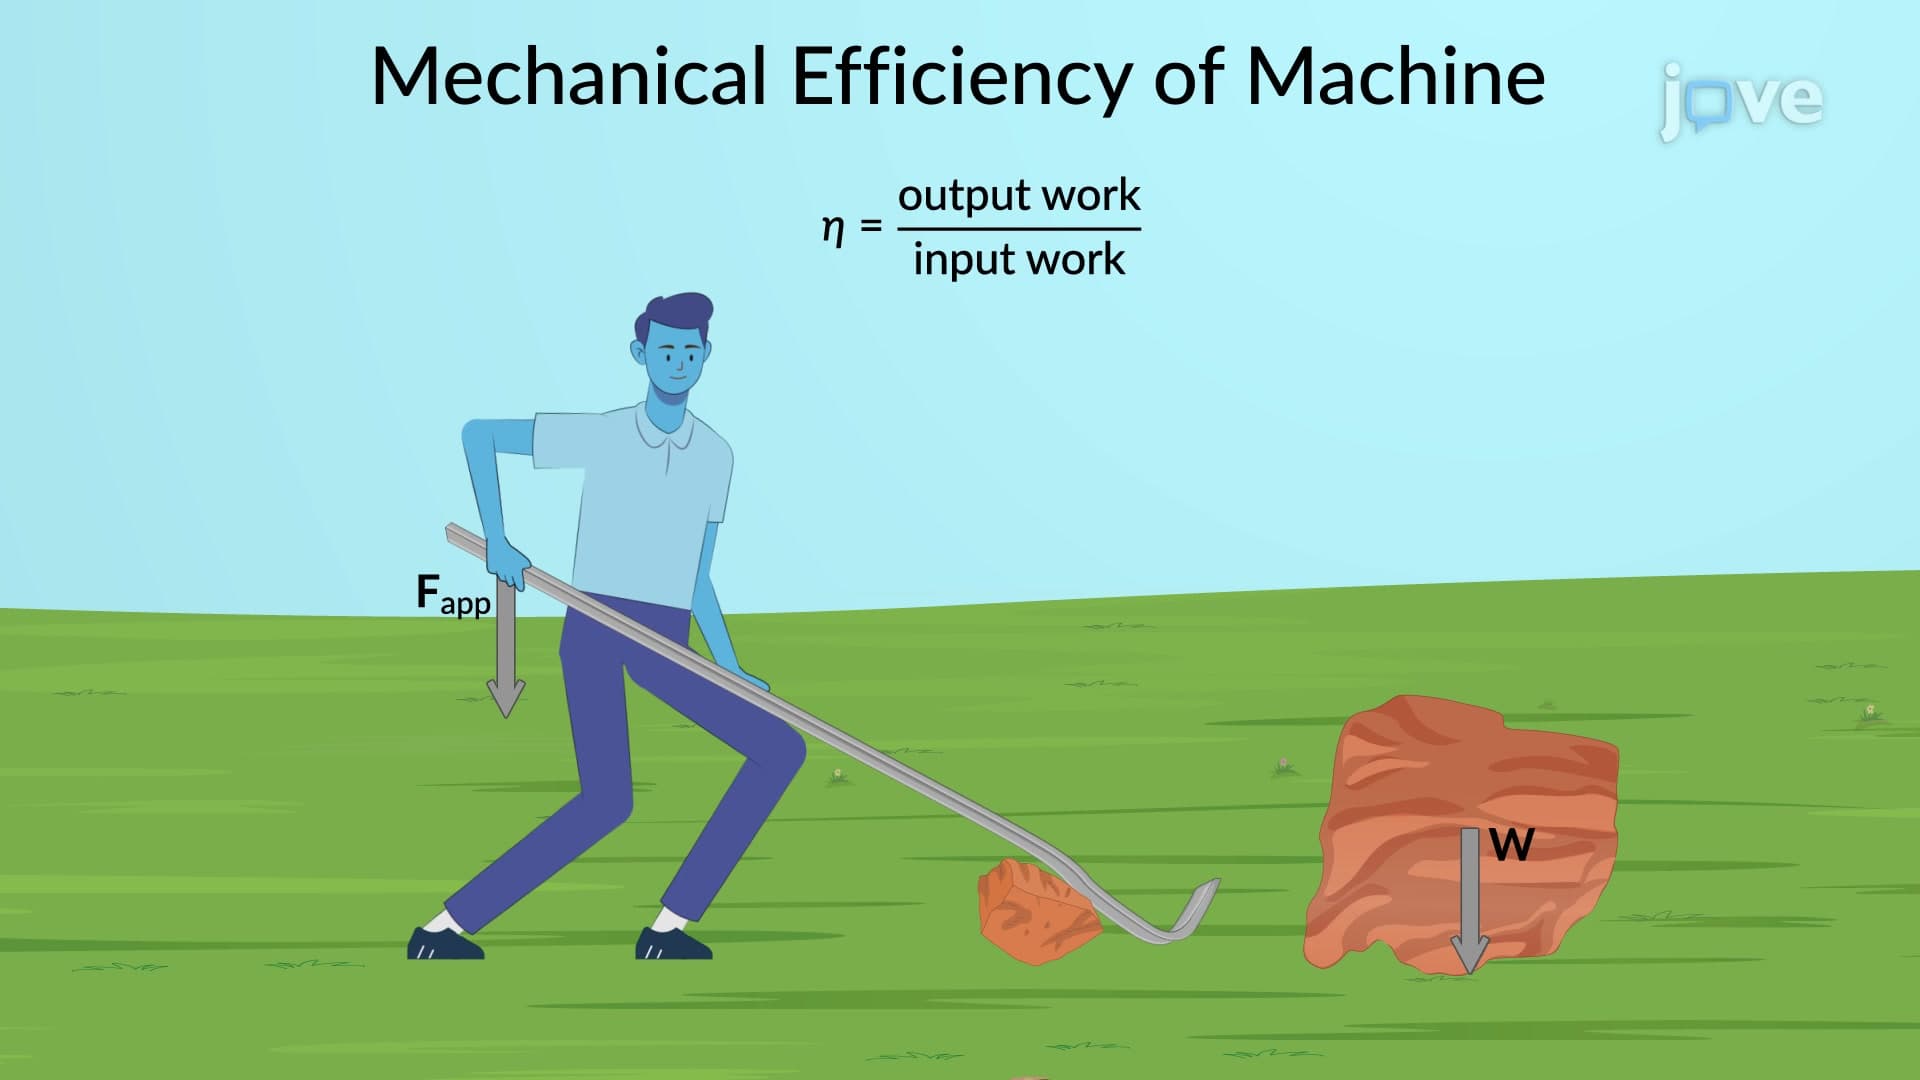
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:18
Hierarchy of Motor Control
 01:21
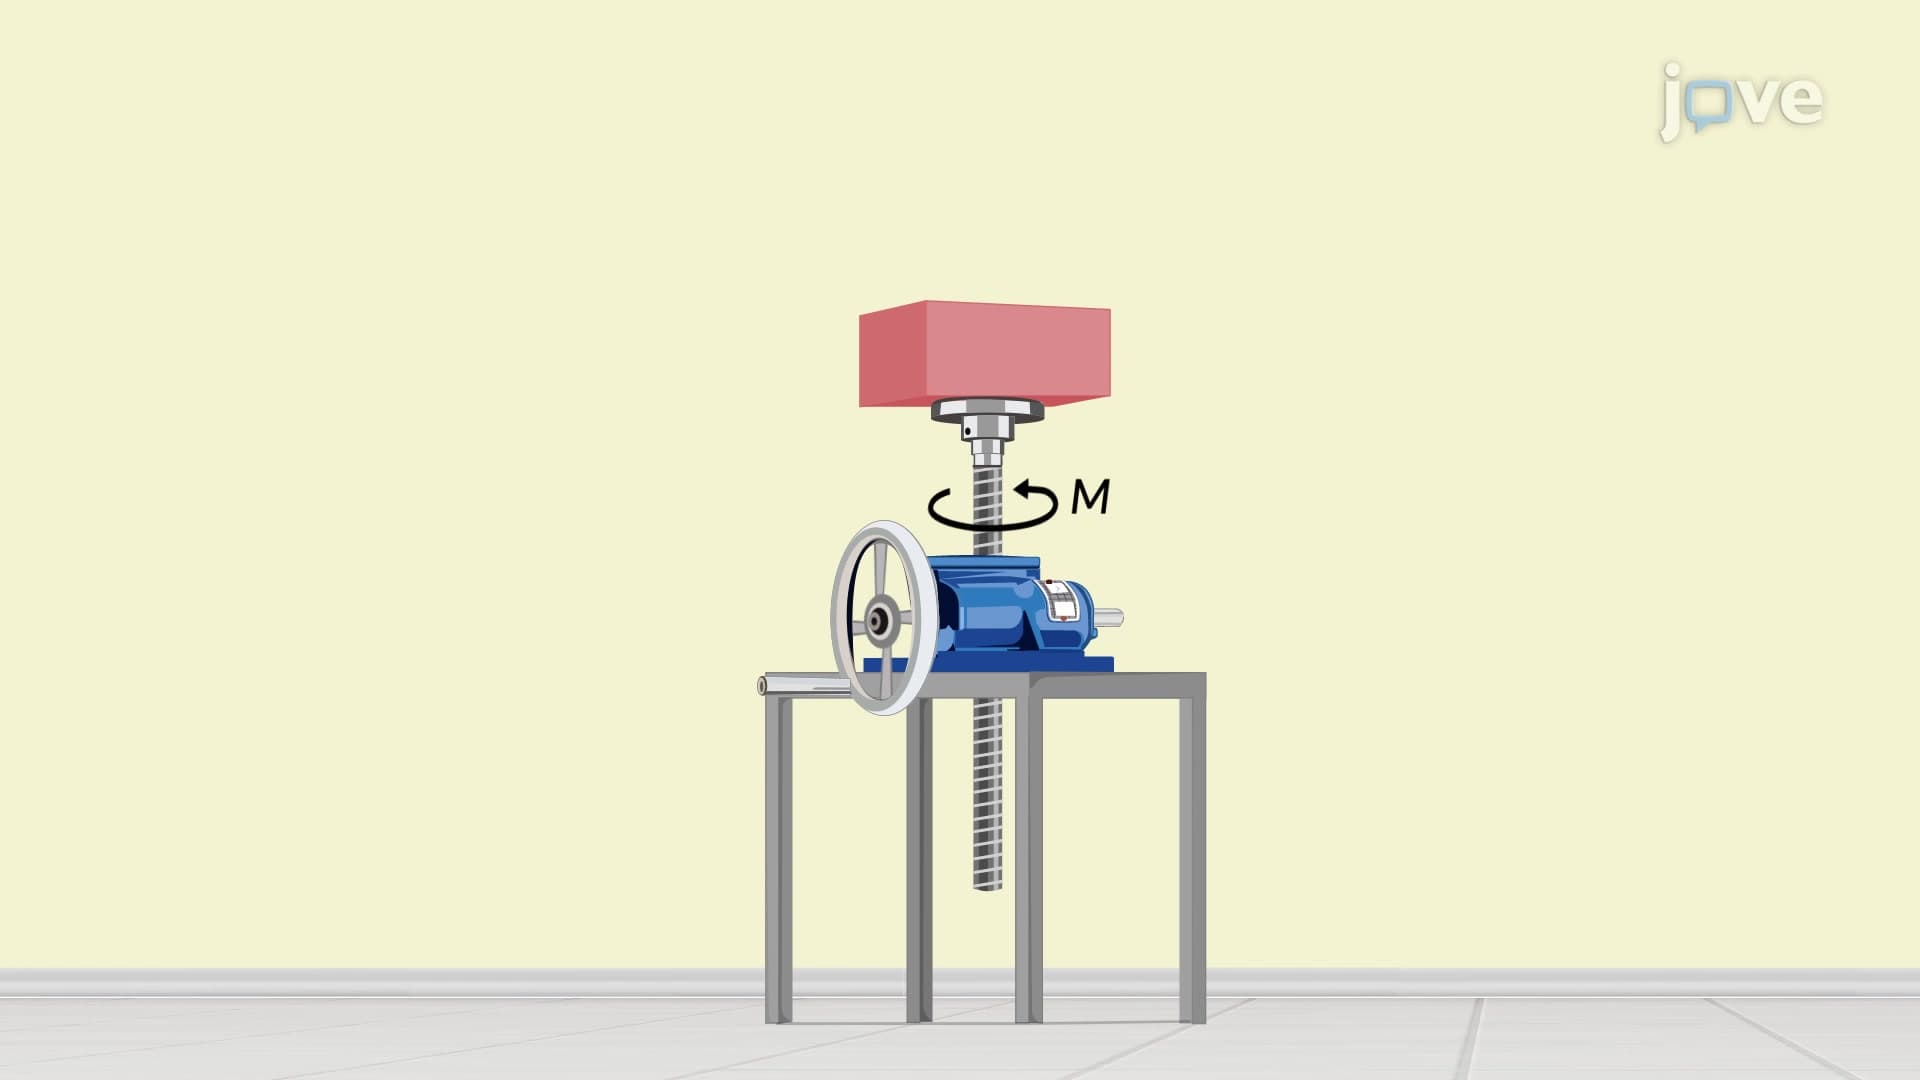
Upward Impending Motion
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:23
Journal Bearings
To better understand the concept of journal bearings, consider a rope winch with dry or...