Related Experiment Video
Updated: May 9, 2026


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
A soft body as a reservoir: case studies in a dynamic model of octopus-inspired soft robotic arm
Kohei Nakajima1, Helmut Hauser, Rongjie Kang
1Artificial Intelligence Laboratory, Department of Informatics, University of Zurich Zurich, Switzerland ; Bio-inspired Robotics Laboratory, Department of Mechanical and Process Engineering ETH Zurich, Zurich, Switzerland.

Abstract:
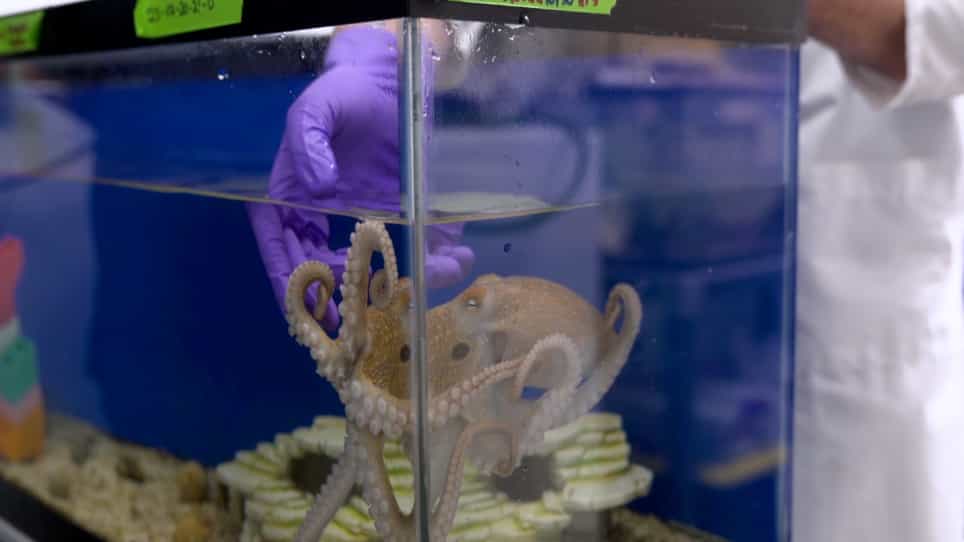
The behaviors of the animals or embodied agents are characterized by the dynamic coupling between the brain, the body, and the environment. This implies that control, which is conventionally thought to be handled by the brain or a controller, can partially be outsourced to the physical body and the interaction with the environment. This idea has been demonstrated in a number of recently constructed robots, in particular from the field of "soft robotics". Soft robots are made of a soft material introducing high-dimensionality, non-linearity, and elasticity, which often makes the robots difficult to control. Biological systems such as the octopus are mastering their complex bodies in highly sophisticated manners by capitalizing on their body dynamics. We will demonstrate that the structure of the octopus arm cannot only be exploited for generating behavior but also, in a sense, as a computational resource. By using a soft robotic arm inspired by the octopus we show in a number of experiments how control is partially incorporated into the physical arm's dynamics and how the arm's dynamics can be exploited to approximate non-linear dynamical systems and embed non-linear limit cycles. Future application scenarios as well as the implications of the results for the octopus biology are also discussed.

Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short circuit,...
 01:21
Mechanistic Models: Overview of Compartment Models