Related Experiment Video
Updated: May 9, 2026
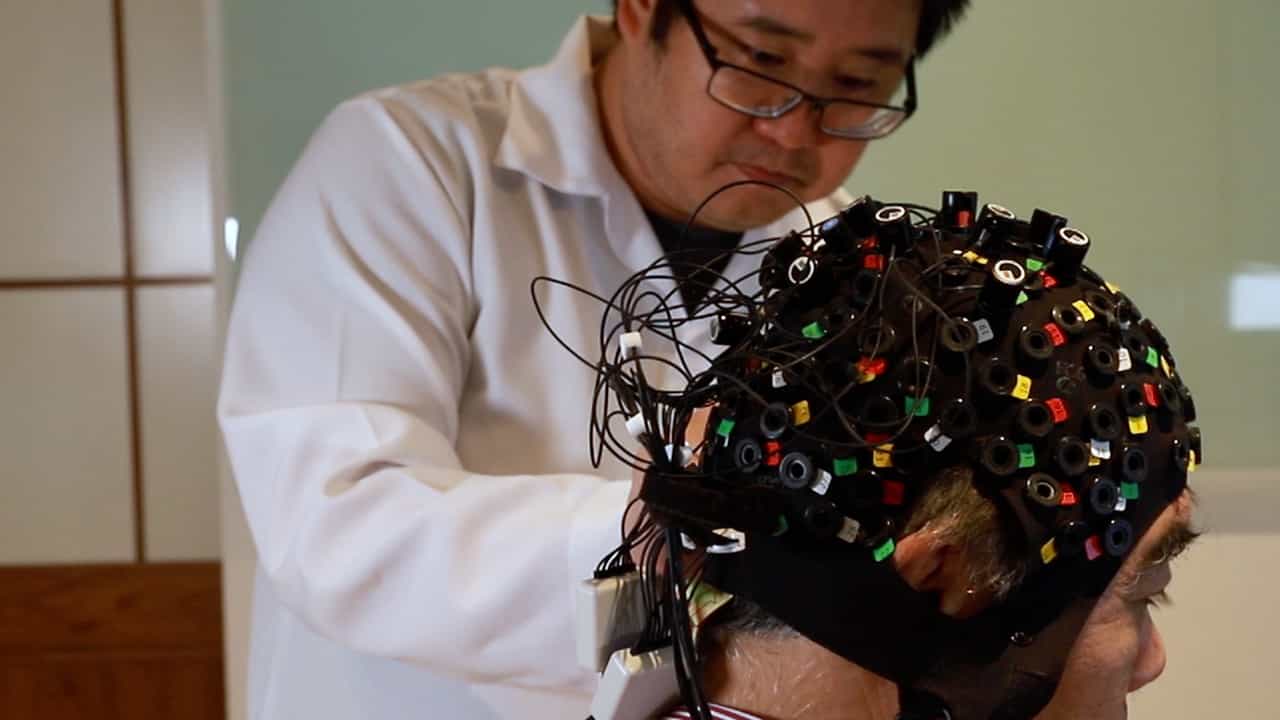

An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024
Immediate effect of Walkbot robotic gait training on neuromechanical knee stiffness in spastic hemiplegia: a case
Do Hyeon Kim1, Yong-Il Shin, Kyung-Lim Joa
1Movement Healing Laboratory, Department of Physical Therapy, Yonsei University, Wonju, Republic of Korea.

Purpose:
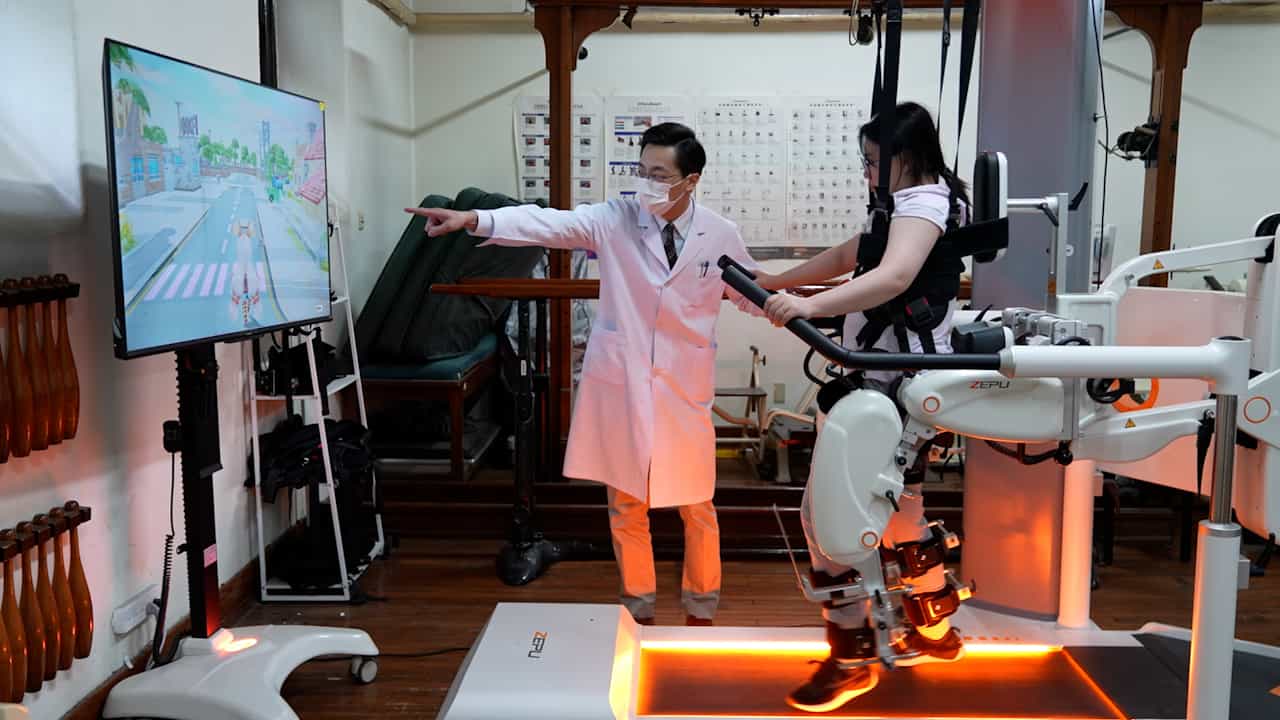
The purpose of this study was to investigate the immediate effect of Walkbot gait training on knee joint stiffness in an individual with spastic hemiplegia.
Method:
A woman with hemiparetic stroke underwent a 30-minute Walkbot robotic-assisted gait training session. Knee flexion stiffness associated with hamstring spasticity and knee extension torques during the terminal swing phase was determined before and after the intervention using the Walkbot-STIFF measurement system.
Design:
Descriptive case analysis.
Results:
Knee joint extension kinematic at the terminal swing phase increased from 2.44° to -0.28°. Knee joint torque increased from 0.26 Nm to 0.32 Nm. The knee flexion stiffness decreased from 0.0083 Nm/degree to 0.0022 Nm/degree following the training.
Conclusions:
The Walkbot robotic-assisted locomotor training was effective for reducing knee joint stiffness and improving extensor torque during functional gait. Moreover, the Walkbot-STIFF system was useful for assessing and monitoring spasticity during locomotor training.