Related Experiment Video
Updated: May 9, 2026
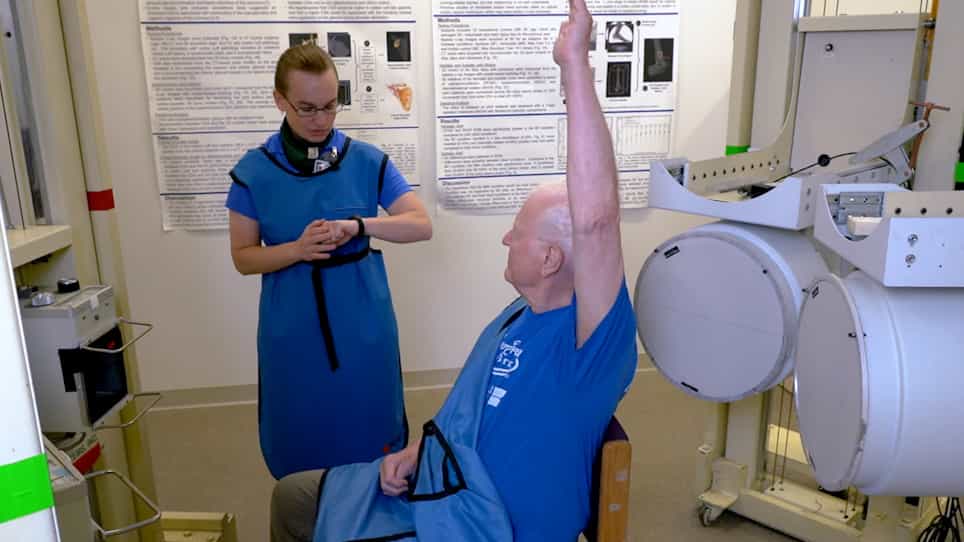
06:09

Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Global sensitivity analysis of the kinematics obtained with a multi-body optimisation using a parallel mechanism of
A El Habachi1, S Duprey, L Chèze
1Université de Lyon, F-69622 Lyon , France.
Computer Methods in Biomechanics and Biomedical Engineering
|August 9, 2013

Abstract
No abstract available in PubMed .

Related Concept Videos
 01:18
Kinematic Equations - III
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
 01:17
Kinematic Equations - II
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:23
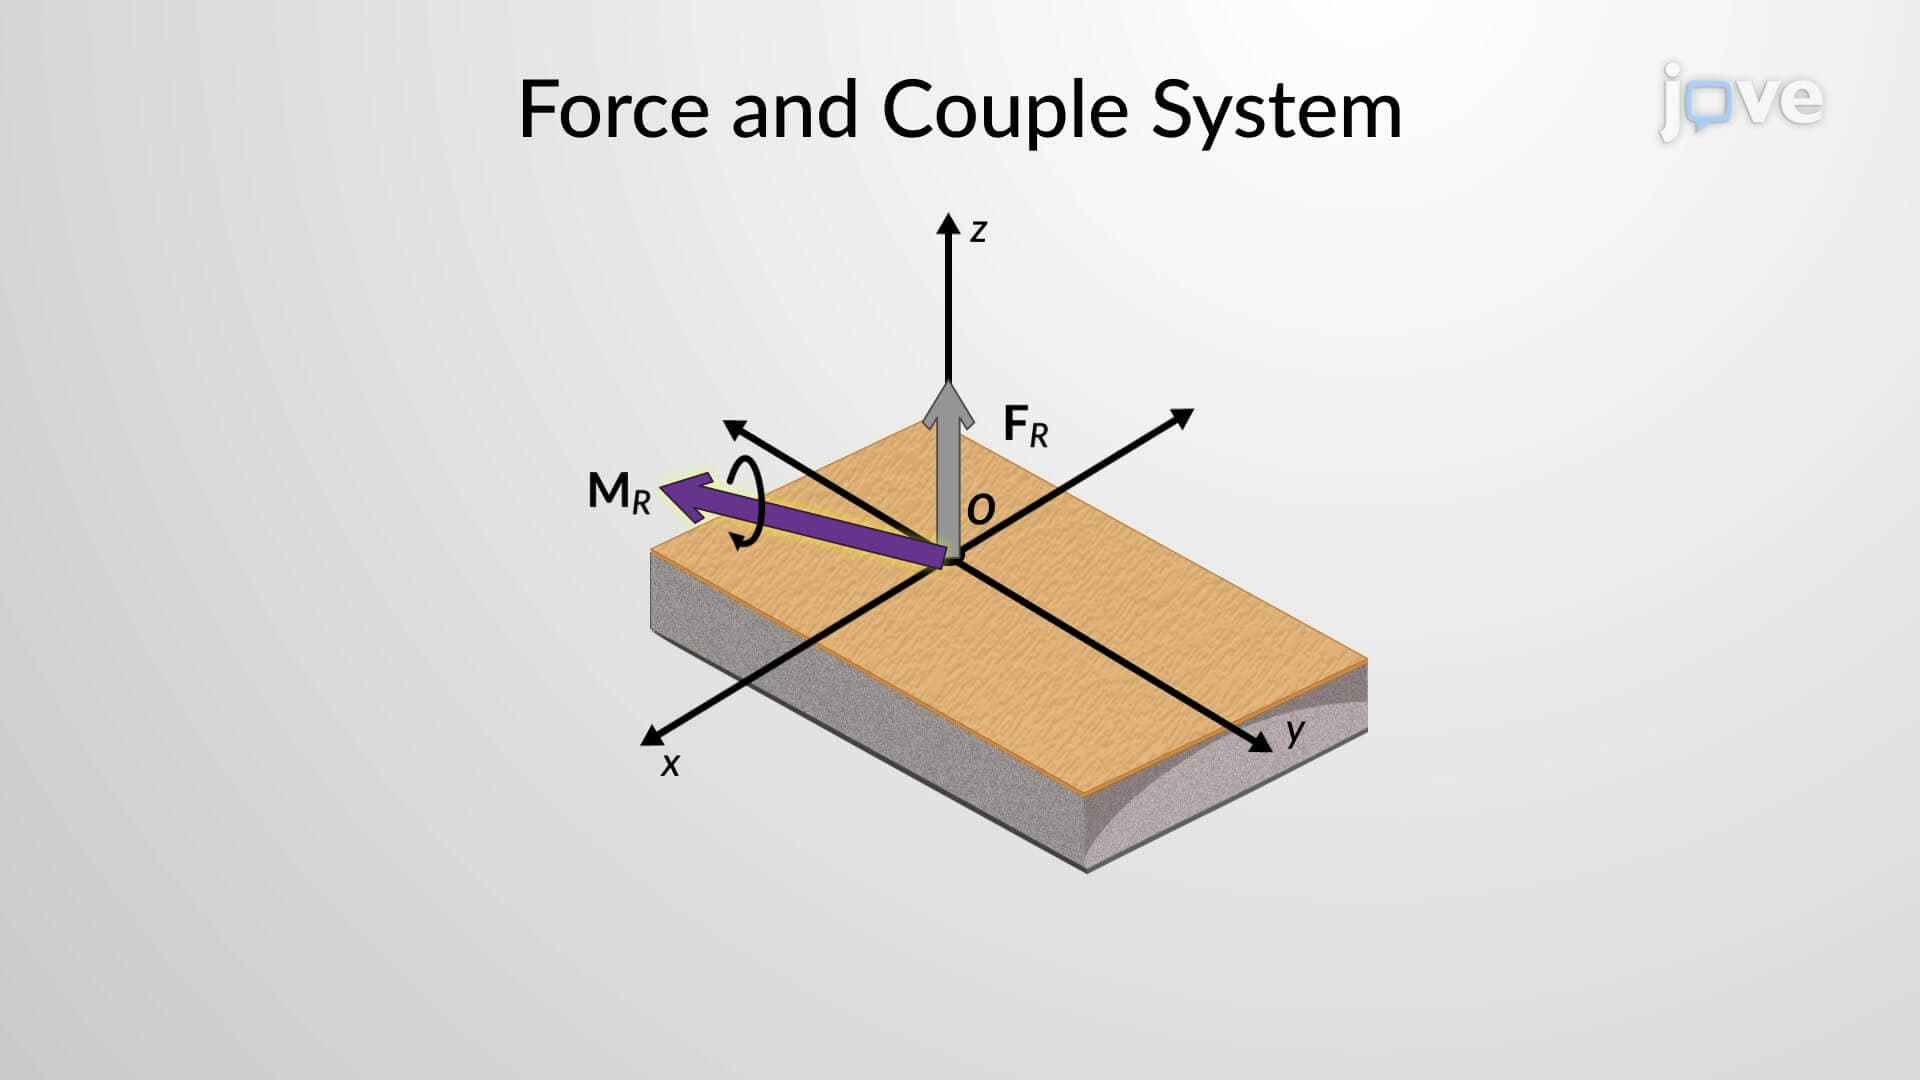
Simplification of a Force and Couple System: II
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
 01:30
Kinematic Equations for Rotation
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
 01:10
Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...