Related Experiment Video
Updated: May 9, 2026

Comprehensive Understanding of Inactivity-Induced Gait Alteration in Rodents
Published on: July 6, 2022
Kinematic parameters of signed verbs
Evie Malaia1, Ronnie B Wilbur, Marina Milkovic
1Correspondence to Evie Malaia: evie1706@gmail.com.

Purpose:
Sign language users recruit physical properties of visual motion to convey linguistic information. Research on American Sign Language (ASL) indicates that signers systematically use kinematic features (e.g., velocity, deceleration) of dominant hand motion for distinguishing specific semantic properties of verb classes in production ( Malaia & Wilbur, 2012a) and process these distinctions as part of the phonological structure of these verb classes in comprehension ( Malaia, Ranaweera, Wilbur, & Talavage, 2012). These studies are driven by the event visibility hypothesis by Wilbur (2003), who proposed that such use of kinematic features should be universal to sign language (SL) by the grammaticalization of physics and geometry for linguistic purposes. In a prior motion capture study, Malaia and Wilbur (2012a) lent support for the event visibility hypothesis in ASL, but there has not been quantitative data from other SLs to test the generalization to other languages.
Method:
The authors investigated the kinematic parameters of predicates in Croatian Sign Language ( Hrvatskom Znakovnom Jeziku [HZJ]).
Results:
Kinematic features of verb signs were affected both by event structure of the predicate (semantics) and phrase position within the sentence (prosody).
Conclusion:
The data demonstrate that kinematic features of motion in HZJ verb signs are recruited to convey morphological and prosodic information. This is the first crosslinguistic motion capture confirmation that specific kinematic properties of articulator motion are grammaticalized in other SLs to express linguistic features.

Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
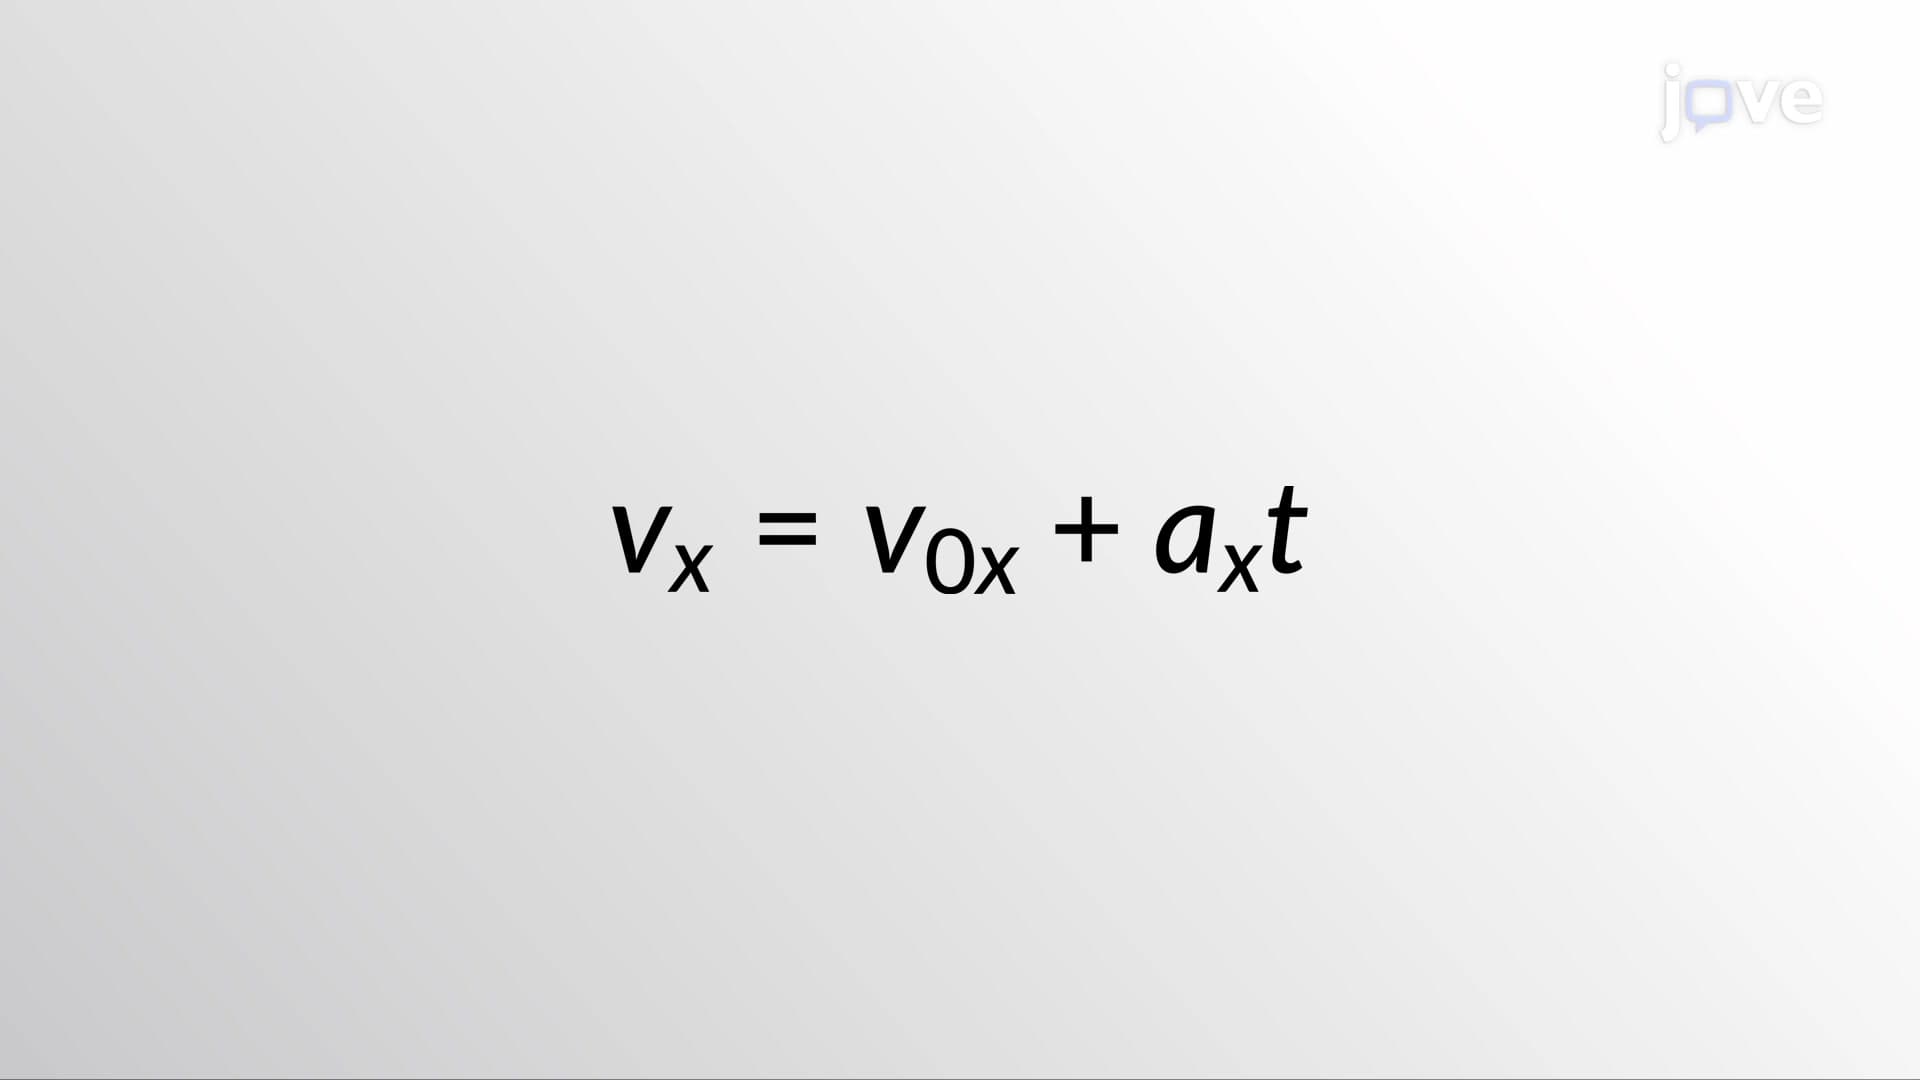 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:30
Sign Convention
The normal force acts perpendicular to the beam's cross-section and can cause...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...