Inertial sensor based method for identifying spherical joint center of rotation
Related Experiment Video
Updated: May 9, 2026
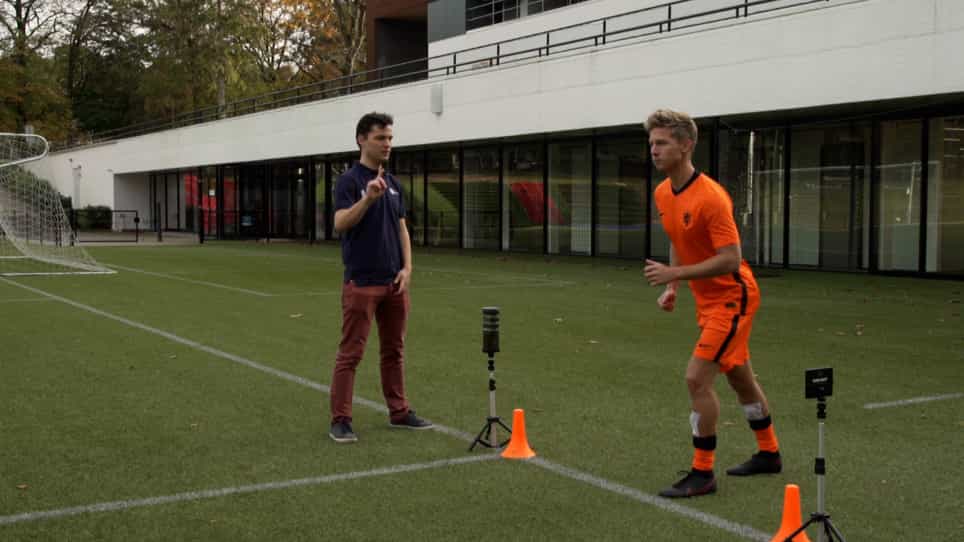
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Ryan S McGinnis1, Noel C Perkins
1Mechanical Engineering, University of Michigan, 2350 Hayward Street, Ann Arbor, MI 48109-2125, USA.

Abstract:
The miniaturized wireless inertial measurement unit (IMU) technology and algorithms presented herein promote rapid and accurate predictions of the center-of-rotation (CoR) for ball/spherical joints. The algorithm improves upon existing IMU-based methods by directly utilizing the measured acceleration and angular velocity provided by the IMU to deduce the CoR in lieu of relying on error-prone velocity and position estimates. Results demonstrate that this new method resolves the position of the CoR to within a 3mm sphere of the true CoR determined by a precision coordinate measuring machine. Such accuracy may render this method attractive for broad use in field, laboratory and clinical settings requiring non-invasive and rapid estimates of joint CoR.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:03
Inertial Frames of Reference
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...