Related Experiment Video
Updated: May 8, 2026
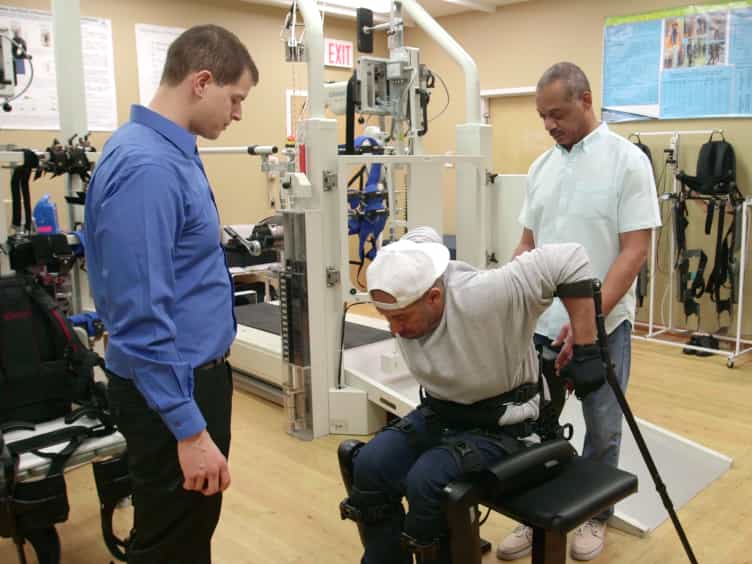
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Wearable Power-Assist Locomotor (WPAL) for supporting upright walking in persons with paraplegia
Shigeo Tanabe1, Satoshi Hirano, Eiichi Saitoh
1Faculty of Rehabilitation, School of Health Sciences, Fujita Health University, Aichi, Japan. tanabes@fujita-hu.ac.jp

Background:
Due to physical and psychosocial issues associated with long-term sitting in a wheelchair, devising new ways to facilitate upright mobility is a key issue in rehabilitation medicine. Wearable Power-Assist Locomotor (WPAL) is a motorized orthosis and is developed for providing independent and comfortable walking for paraplegic patients.
Methods:
The WPAL consists of a wearable robotic orthosis and custom walker. To facilitate alternate usage with a wheelchair, the wearable robotic orthosis is based on a medial system with motors located at the bilateral hip, knee and ankle joints to reduce the increase in heart rate during gait. The gait parameters include stride length, toe clearance height, swing time, double support time, etc. (gait speed: up to 1.3 km/h). Independent gait with the walker can be learned through a five-stage gait exercise sequence. The first two stages are stepping and gait exercises with parallel bars. The third stage is gait exercise on treadmill. The subsequent two stages are gait exercise with walker.
Results:
Seven motor-complete paraplegic patients (spinal cord functional levels: T6-T12) participated. Through a series of exercises, all users achieved independent gait on a level floor (Functional Ambulation Categories: 4). The mean duration and distance of consecutively walking were 14.1 ± 11.4 minutes and 165.6 ± 202.6 m, respectively. The most competent user was able to walk continuously for as long as 40 minutes and 640 m whereas only for 6 minutes and 107 m with a conventional orthosis.
Conclusions:
These results suggest that WPAL might be useful device for supporting upright walking in persons with paraplegia.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 06:00
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025