Related Experiment Video
Updated: May 8, 2026
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy (iPALM)
Published on: December 1, 2016
Exhaustive linearization for robust camera pose and focal length estimation
Adrian Penate-Sanchez1, Juan Andrade-Cetto, Francesc Moreno-Noguer
1Institut de Robòtica i Informàtica Industrial, CSIC-UPC, Barcelona. apenate@iri.upc.edu

Abstract:
We propose a novel approach for the estimation of the pose and focal length of a camera from a set of 3D-to-2D point correspondences. Our method compares favorably to competing approaches in that it is both more accurate than existing closed form solutions, as well as faster and also more accurate than iterative ones. Our approach is inspired on the EPnP algorithm, a recent O(n) solution for the calibrated case. Yet we show that considering the focal length as an additional unknown renders the linearization and relinearization techniques of the original approach no longer valid, especially with large amounts of noise. We present new methodologies to circumvent this limitation termed exhaustive linearization and exhaustive relinearization which perform a systematic exploration of the solution space in closed form. The method is evaluated on both real and synthetic data, and our results show that besides producing precise focal length estimation, the retrieved camera pose is almost as accurate as the one computed using the EPnP, which assumes a calibrated camera.
Related Concept Videos
 01:29
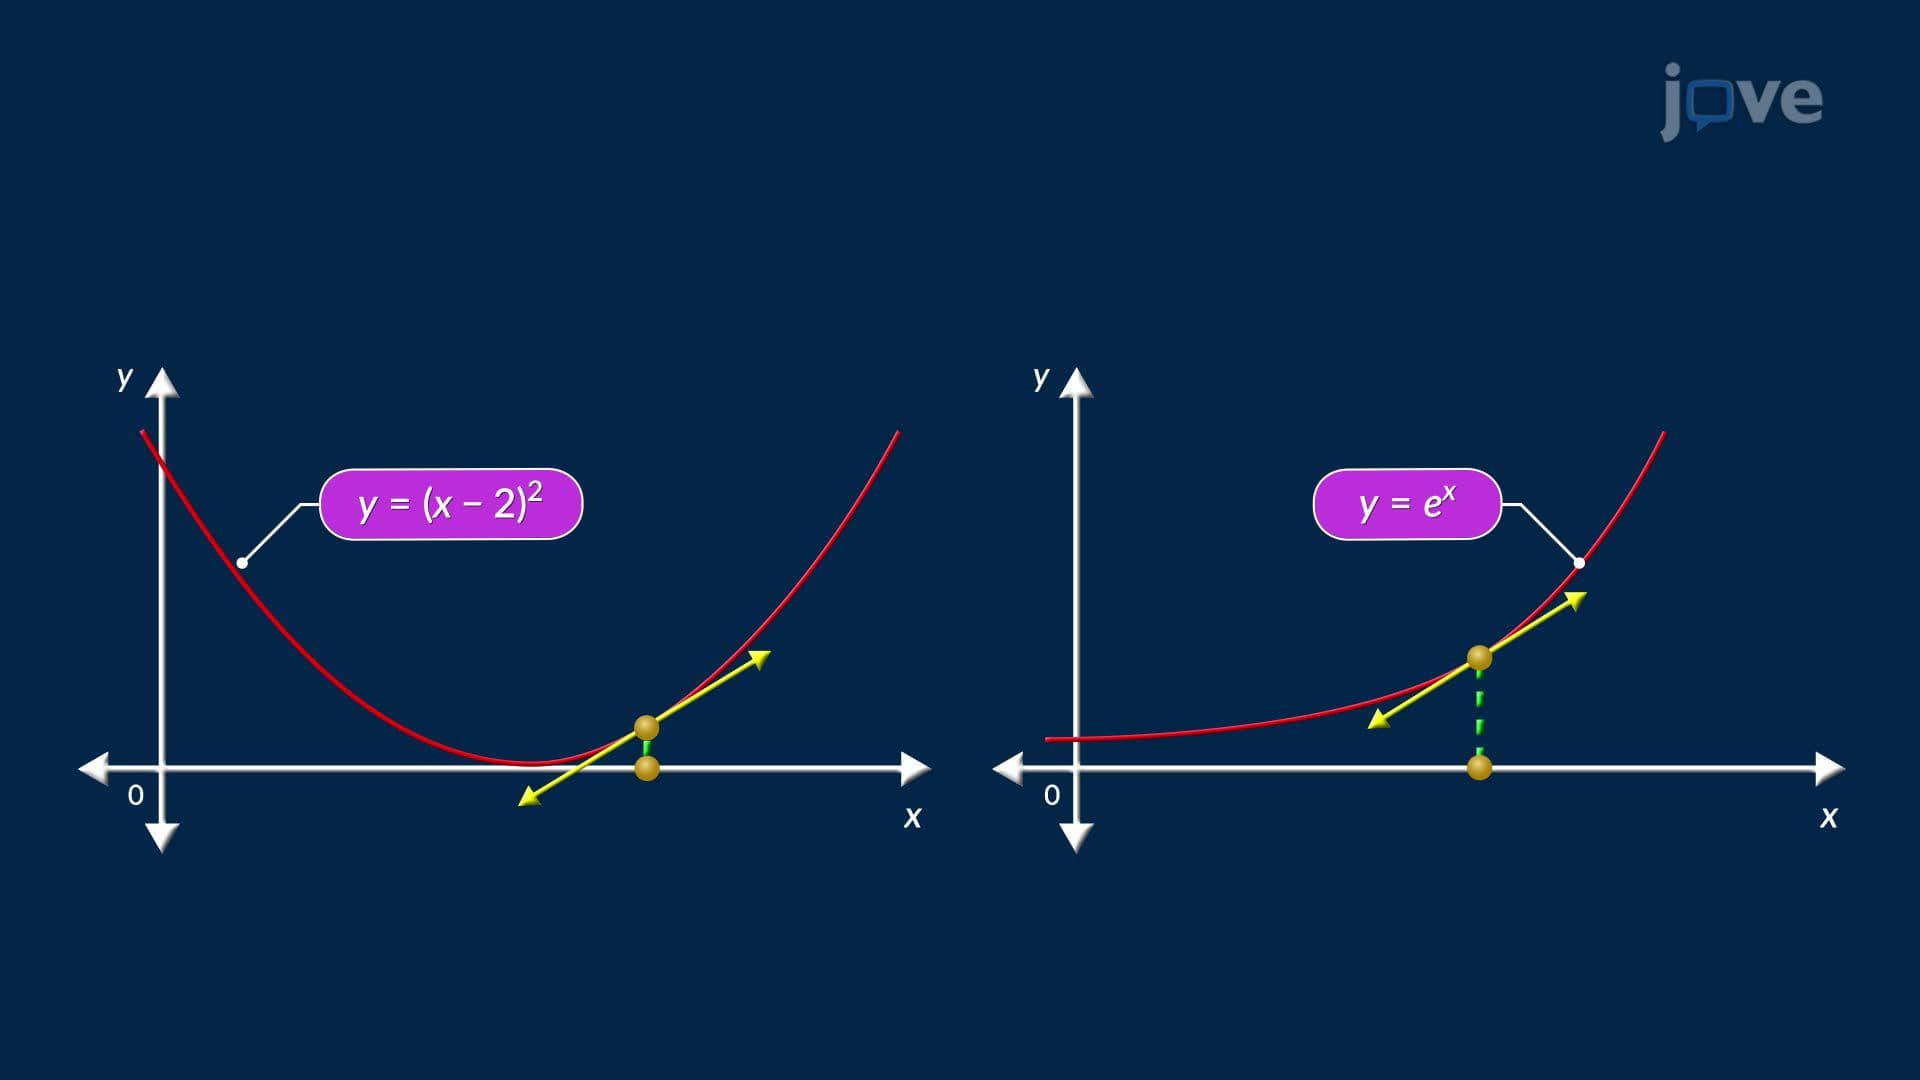
Application of Linearization and Approximation
 01:26
Linearization and Approximation
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:18
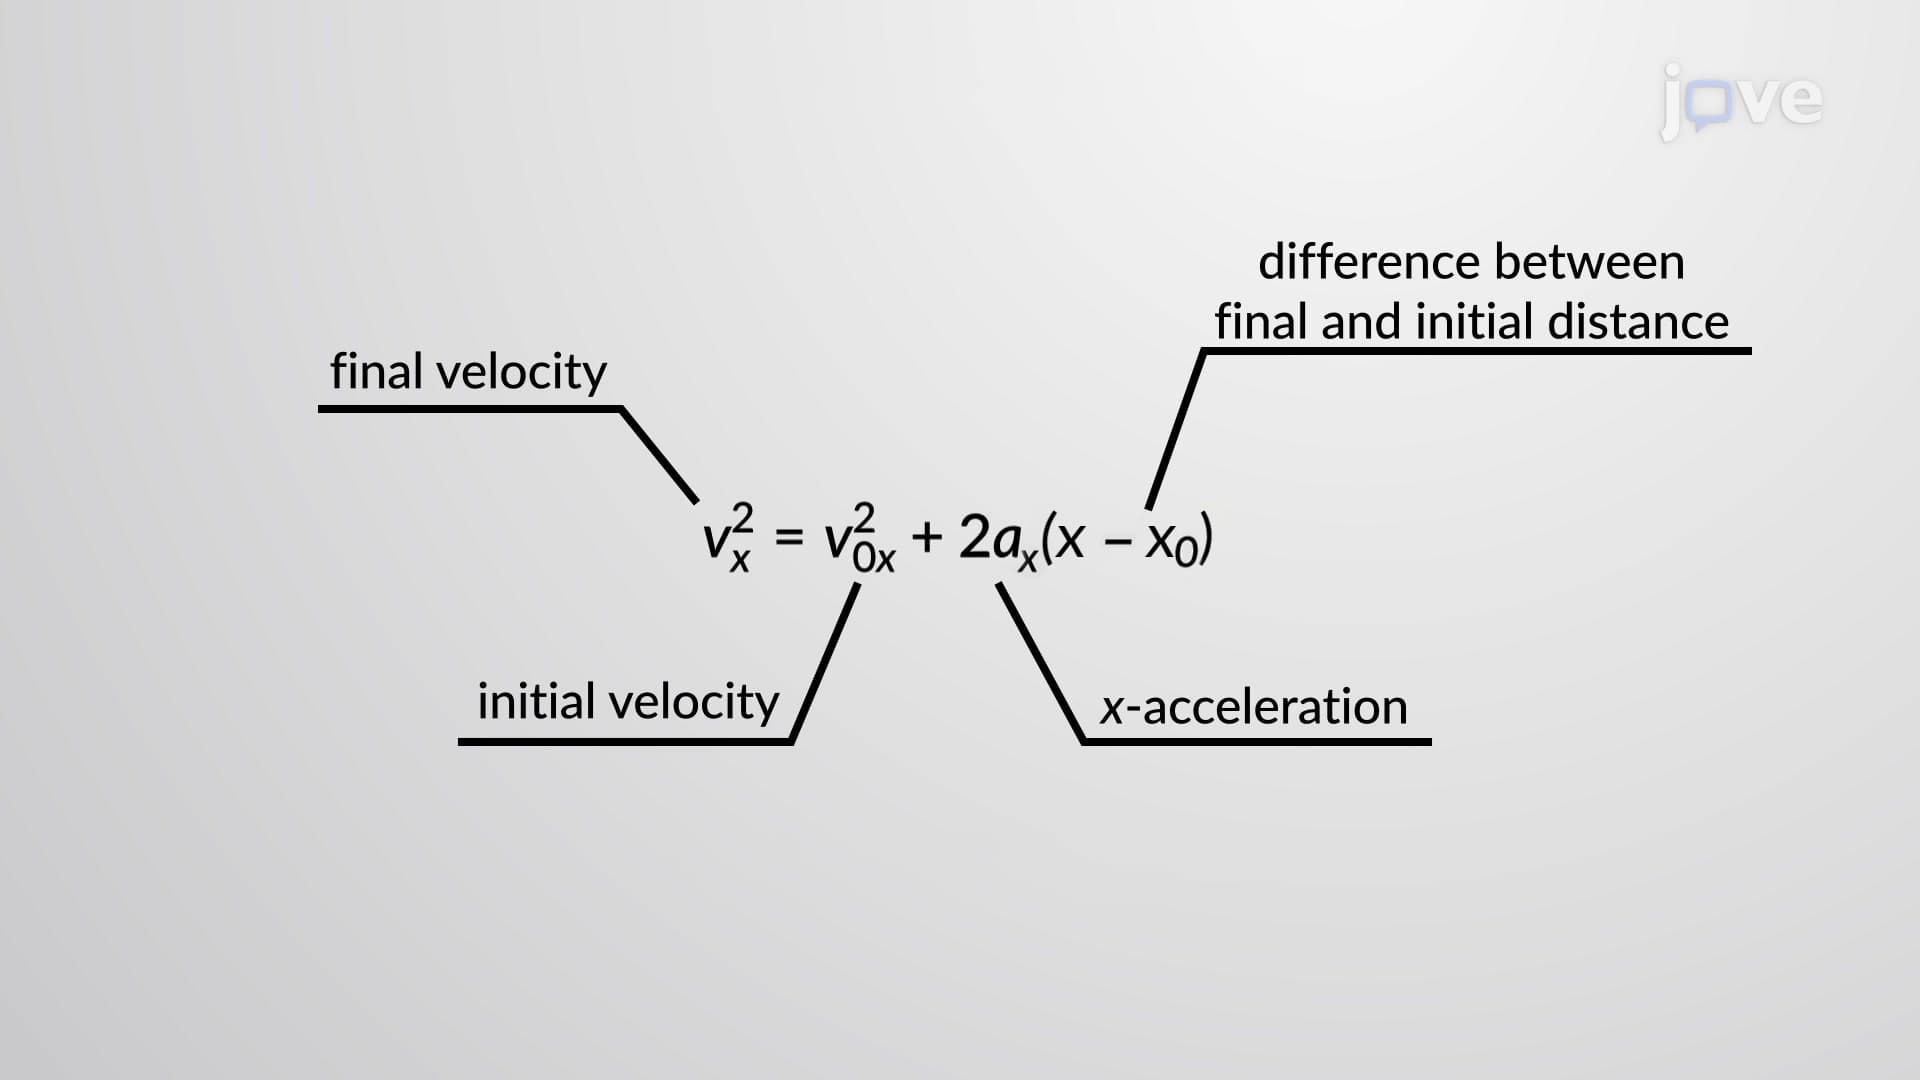
Kinematic Equations - III
Using the kinematic equations,...