Intrinsic frames of reference in haptic spatial learning
Related Experiment Video
Updated: May 2, 2026
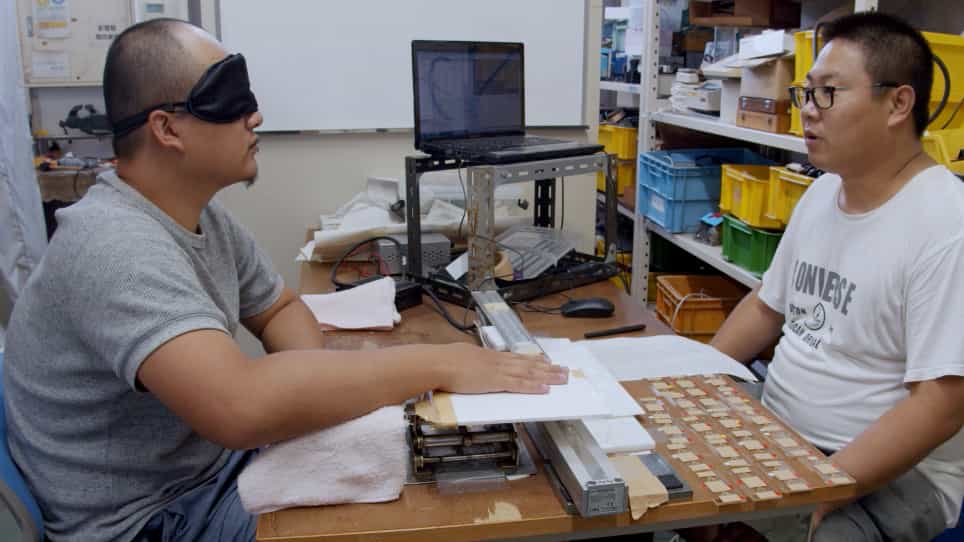
Tactile Semiautomatic Passive-Finger Angle Stimulator TSPAS
Published on: July 30, 2020
Naohide Yamamoto1, John W Philbeck
1Department of Psychology, Cleveland State University, 2121 Euclid Avenue, Cleveland, OH 44115, USA; Department of Psychology, George Washington University, 2125 G Street, NW, Washington, DC 20052, USA.

Abstract:
It has been proposed that spatial reference frames with which object locations are specified in memory are intrinsic to a to-be-remembered spatial layout (intrinsic reference theory). Although this theory has been supported by accumulating evidence, it has only been collected from paradigms in which the entire spatial layout was simultaneously visible to observers. The present study was designed to examine the generality of the theory by investigating whether the geometric structure of a spatial layout (bilateral symmetry) influences selection of spatial reference frames when object locations are sequentially learned through haptic exploration. In two experiments, participants learned the spatial layout solely by touch and performed judgments of relative direction among objects using their spatial memories. Results indicated that the geometric structure can provide a spatial cue for establishing reference frames as long as it is accentuated by explicit instructions (Experiment 1) or alignment with an egocentric orientation (Experiment 2). These results are entirely consistent with those from previous studies in which spatial information was encoded through simultaneous viewing of all object locations, suggesting that the intrinsic reference theory is not specific to a type of spatial memory acquired by the particular learning method but instead generalizes to spatial memories learned through a variety of encoding conditions. In particular, the present findings suggest that spatial memories that follow the intrinsic reference theory function equivalently regardless of the modality in which spatial information is encoded.

Related Concept Videos
 01:33
Somatosensation
 01:03
Inertial Frames of Reference
 01:27
Non-inertial Frames of Reference
 01:15
Depth Perception and Spatial Vision