Marker optimization for facial motion acquisition and deformation
Related Experiment Video
Updated: May 7, 2026
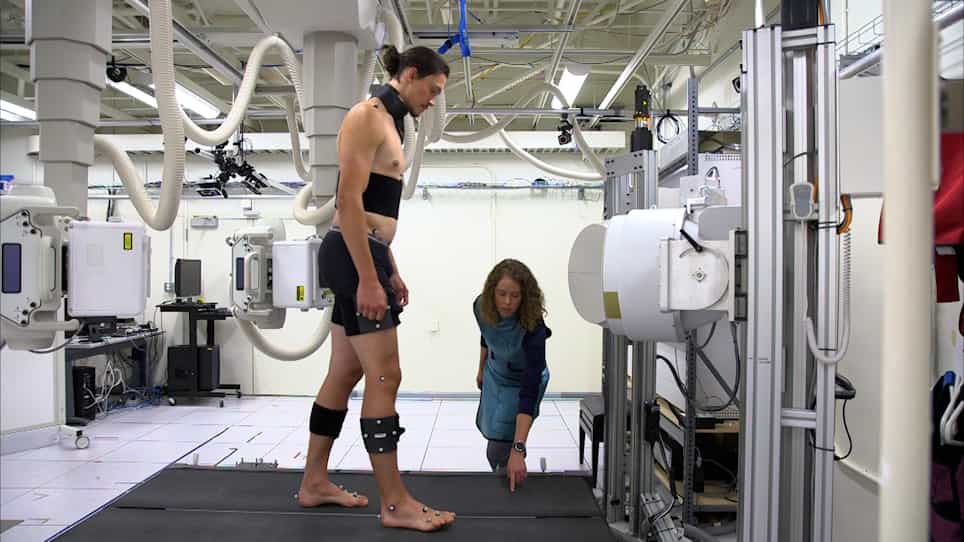
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
Binh H Le1, Mingyang Zhu, Zhigang Deng
1University of Houston, Houston.

Abstract:
A long-standing problem in marker-based facial motion capture is what are the optimal facial mocap marker layouts. Despite its wide range of potential applications, this problem has not yet been systematically explored to date. This paper describes an approach to compute optimized marker layouts for facial motion acquisition as optimization of characteristic control points from a set of high-resolution, ground-truth facial mesh sequences. Specifically, the thin-shell linear deformation model is imposed onto the example pose reconstruction process via optional hard constraints such as symmetry and multiresolution constraints. Through our experiments and comparisons, we validate the effectiveness, robustness, and accuracy of our approach. Besides guiding minimal yet effective placement of facial mocap markers, we also describe and demonstrate its two selected applications: marker-based facial mesh skinning and multiresolution facial performance capture.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:14
Muscles for Facial Expressions
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...