Related Experiment Video
Updated: May 7, 2026

Monitoring Spatial Segregation in Surface Colonizing Microbial Populations
Published on: October 29, 2016
Stability and pattern formation for competing populations with asymmetric nonlocal coupling
M C Tanzy1, V A Volpert, A Bayliss
1Department of Engineering Sciences and Applied Mathematics, Northwestern University, Evanston, IL 60208-3125, USA.

Abstract:
We consider a model of two competing species with asymmetric nonlocal coupling in a competition for resources. The nonlocal coupling is via convolution integrals and the asymmetry is via convolution kernel functions which are not even functions of their arguments. The nonlocality is due to species mobility, so that at any fixed point in space the competition for resources depends not just on the populations at that point but on a suitably weighted average of the populations. We introduce two parameters, δ, describing the extent of the coupling, with δ=0 corresponding to local coupling, and α, describing the extent of the asymmetry, with α=0 corresponding to symmetric nonlocal interactions. We consider the case where the model admits a stable coexistence equilibrium solution. We perform a linear stability analysis and show that this solution can be destabilized by sufficient nonlocality, i.e., when δ increases beyond a critical value. We consider two specific kernel functions, (i) an asymmetric Gaussian and (ii) an asymmetric stepfunction. We compute the stability boundary as a function of α, and for δ beyond the stability boundary we determine unstable wavenumber bands. We compute nonlinear patterns for δ significantly beyond the stability boundary. Patterns consist of arrays of islands, regions of nonzero population, separated by either near-deadzones where the populations are small, but nonzero, or by deadzones where populations are exponentially small and essentially extinct. We find solutions consisting of propagating traveling waves of islands, solutions exhibiting colony formation, where a colony is formed just ahead of an island and eventually grows as the parent island decays, and modulated traveling waves, where competition between the two species allows propagation and inhibits colony formation. We explain colony formation and the modulated traveling waves as due to a positive feedback mechanism associated with small variations in the amplitude of the parent island.
Related Concept Videos
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 00:57
Population Growth
 01:04
Oscillations about an Equilibrium Position
 01:13
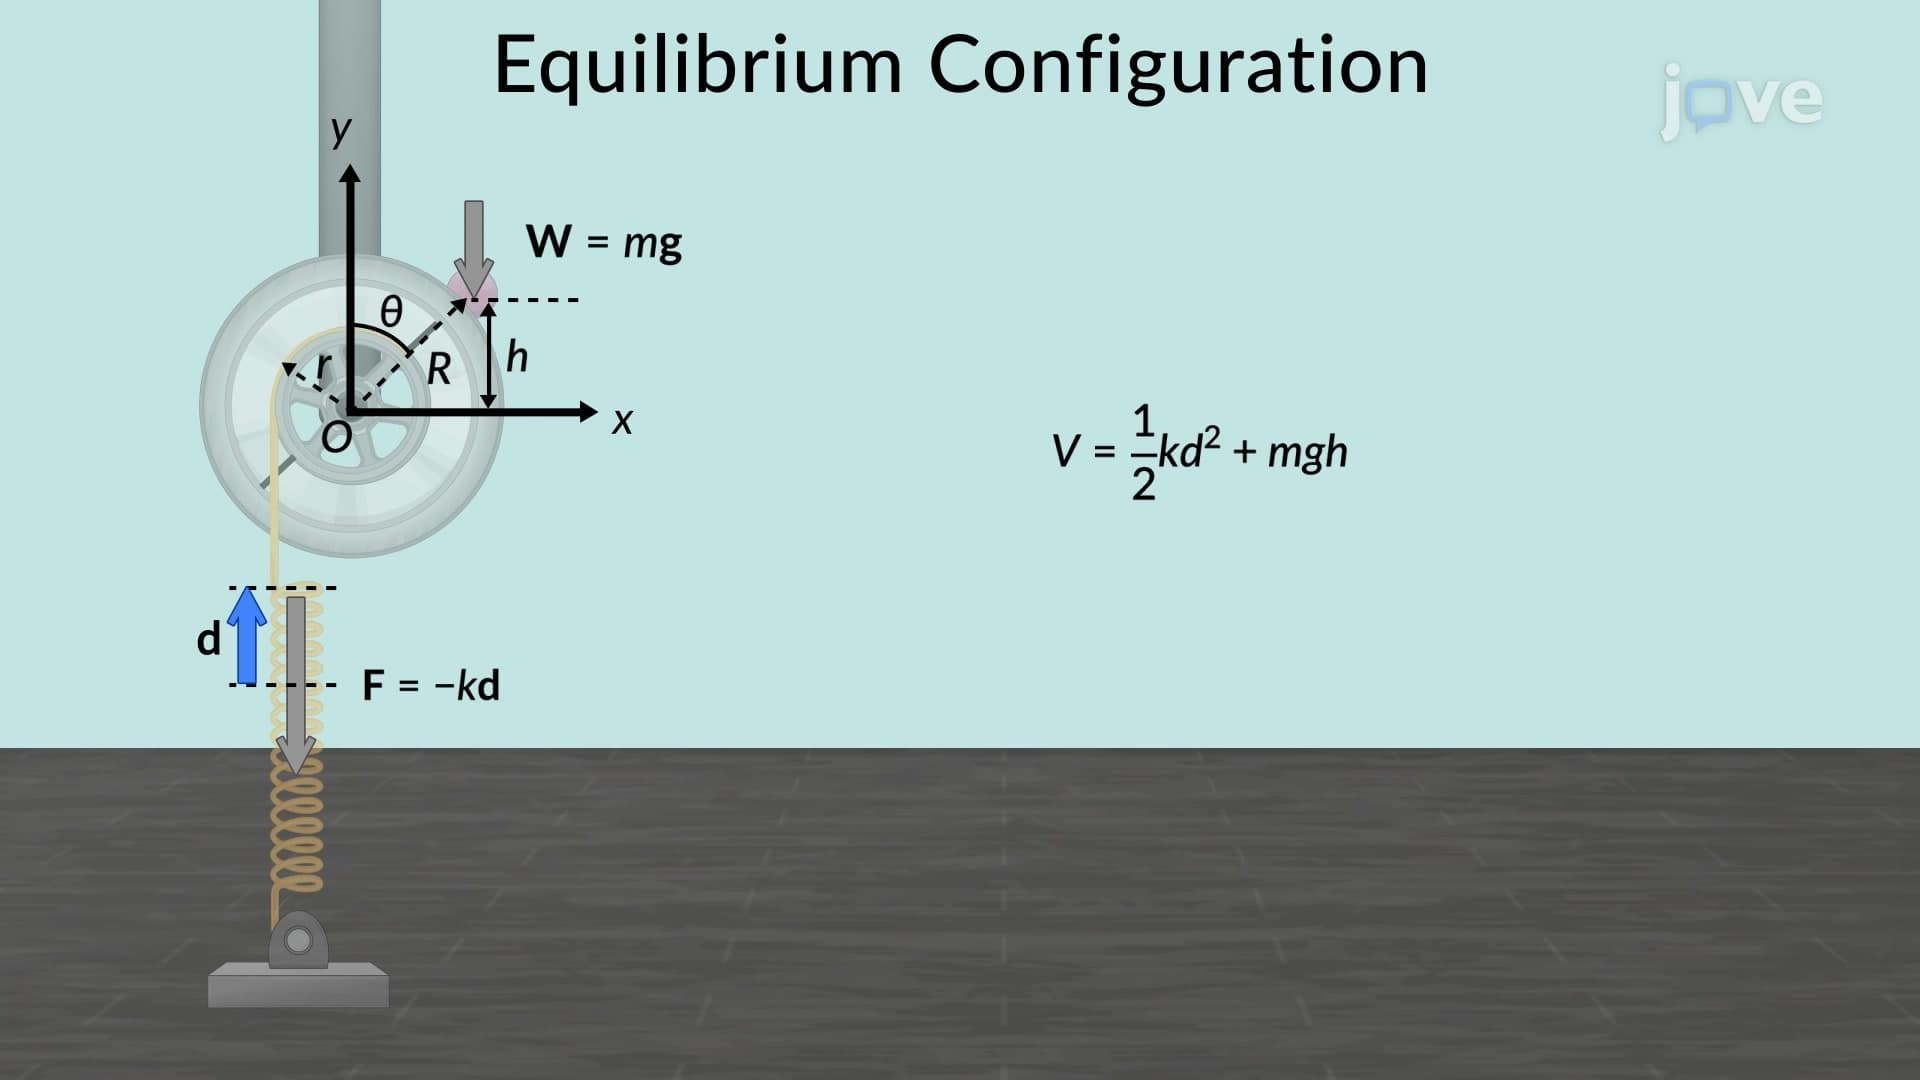
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:07
Speciation Rates
 02:34
Competition